
- Cameras
- 2 × 640×480, 30 Hz, grayscaleDataset
- Shutter
- Not statedNot published
- Field of view
- Calibrated 119° × 95°Measured
- Baseline
- 105.6 mmMeasured
- IMU
- About 1 kHzDataset
- Output
- EuRoC layout, in the datasetDataset
Values from the Monado SLAM Datasets · 1 recording shown · CC BY 4.0 data
Demo and values
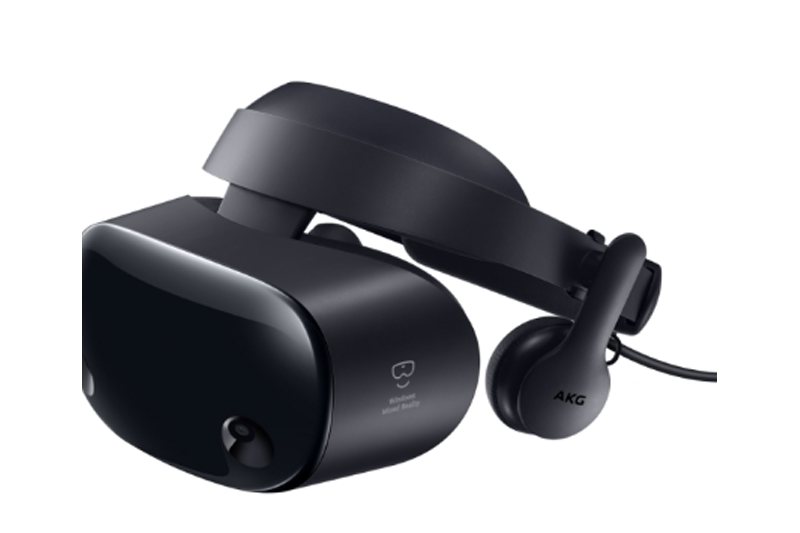
Section titled “Demo and values”VR headset from Samsung with two 640×480 grayscale tracking cameras and an IMU at about 1 kHz, solved from the Monado SLAM calibration data.
One recording shown, with no independent reference on this page. These values show what MVIS solved, not how close they are to the truth.
Calibration process
Section titled “Calibration process”The solved path of the rig around the board. Press Play or drag the bar to follow it, and use the buttons to change the view.
Solved rig
Section titled “Solved rig”The solved rig in 3D, to scale. Tap a sensor for its values. Full screen lets you rotate and zoom. Grid squares are 20 mm.
To scale, from above and the front
| Camera | Lever x, y, z (mm) | Distance (mm) | log(R) (rad) | td (ms) | Field of view |
|---|---|---|---|---|---|
| cam0 | −84.1, −2.3, +4.0 | 84.2 | [−0.366, −0.406, +0.069] | −0.65 | 119° × 95° |
| cam1 | +21.5, −2.4, +3.8 | 21.9 | [−0.374, +0.402, −0.082] | −0.66 | 119° × 94° |
Solved by MVIS. Lever arms are in the IMU frame. Rotation is log(R), camera in the IMU frame.
Specifications
Section titled “Specifications”| From the dataset | |
|---|---|
| Cameras | 2 × 640×480 grayscale at 30 Hz |
| IMU | About 1 kHz |
| Measured in these recordings | |
| Calibrated field of view | cam0 119° × 95° · cam1 119° × 94° |
| Not published | |
| Open | Sensor part numbers |
Dataset
Section titled “Dataset”| Recording | Monado MOC, imucalib, round 4 |
| Source | Monado SLAM Datasets, Collabora |
| Board | AprilGrid 6×6, tag 30 mm, spacing 0.3, t36h11 |
| Licence | CC BY 4.0 |
| Hosted copy | Calibench, converted/monado_moc/ (access by automatic approval) |
| Configs and results | Calibench community, samsung-odyssey-plus/ (access by automatic approval) |
| Data | Monado SLAM Datasets |
Detailed results
Section titled “Detailed results”Lens Calibrated field of view
Calibrated field of view, horizontal × vertical. cam0: 119° × 95°, corners reach 73° from the axis · cam1: 119° × 94°, corners reach 69° from the axis
cam0 cam1
Read from the calibrated lens fit at the image edges, through the principal point. ~ marks an axis past the range the corners reached, where the fit is extrapolated. Past the fit means an edge lies beyond where the fit holds, so no value is given.
IMU Gyro-to-accel offset +2.20 ms
Scale as deviation from 1. Model: calyx. Gyro-to-accel time offset t_ga: +2.20 ± 0.13 ms.
Timing cam0 td −0.65 ms
Offsets to scale, with t_imu = t_cam + td.
Full results Every solved parameter
Rotation is log(R) in rad, camera in the IMU frame.
| Parameter | MVIS |
|---|---|
| cam0 | |
| fx px | 269.41 |
| fy px | 269.32 |
| cx px | 322.90 |
| cy px | 246.13 |
| k1 | 0.07728 |
| k2 | −0.02023 |
| k3 | 0.19205 |
| k4 | −0.11194 |
| Lever x mm | −84.08 |
| Lever y mm | −2.28 |
| Lever z mm | +4.00 |
| log(R) rad | [−0.3664, −0.4062, +0.0686] |
| td ms | −0.646 |
| Reprojection px | 0.393 |
| cam1 | |
| fx px | 271.08 |
| fy px | 271.61 |
| cx px | 323.52 |
| cy px | 251.16 |
| k1 | 0.05617 |
| k2 | 0.00875 |
| k3 | 0.17443 |
| k4 | −0.10925 |
| Lever x mm | +21.48 |
| Lever y mm | −2.42 |
| Lever z mm | +3.75 |
| log(R) rad | [−0.3744, +0.4021, −0.0824] |
| td ms | −0.659 |
| Reprojection px | 0.448 |
| IMU | |
| t_ga ms | +2.20 ± 0.13 |
Limits
Section titled “Limits”- One recording shown, with no independent reference on this page. These values show what MVIS solved, not how close they are to the truth.
- In this batch, 2 of the 4 rounds on this headset didn't converge to a usable solve (rounds 1 and 3). Round 4 is shown. Treat these values with that in mind.
How it was run
Section titled “How it was run”- Camera + IMU with camera intrinsics free and t_ga on. Batch of 2026-11-02.