
LooperRobotics Insight 9
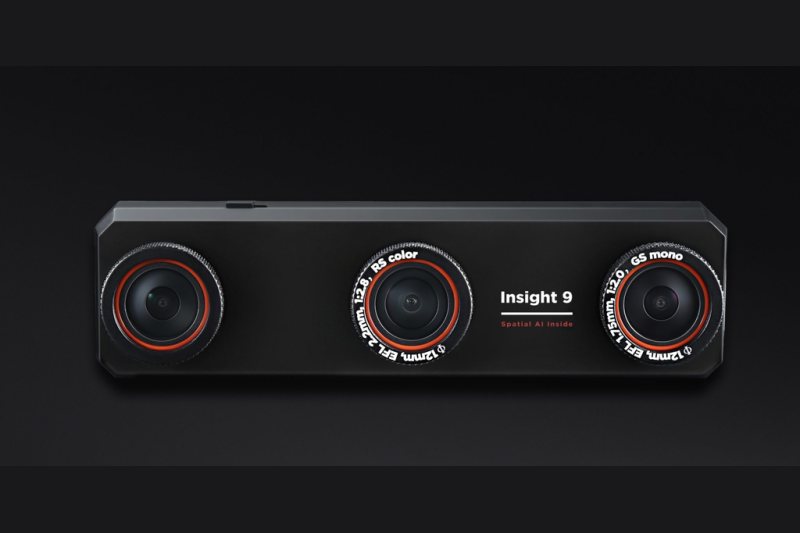
Spatial AI camera: stereo pair, rolling-shutter colour camera, 6-axis IMU, VIO
- Cameras
- 2 mono 544×640, 1 colour 1920×1080Maker ↗︎
- Shutter
- Mono global, colour rollingMaker ↗︎
- Field of view
- Calibrated mono 96° × 113°, colour ~149° × 82°Measured
Colour 188° × 86° × 157° (D × H × V)Maker ↗︎ - Baseline
- 100 mmMaker ↗︎
- IMU
- BMI088, 6-axis, 400 HzMaker ↗︎
- Output
- USB-C 3.1; ROS 2 or UVCMaker ↗︎
Maker values checked 2026-11-03 for the retail Insight 9 · 4 chessboard recordings of our own unit, 36 to 61 s, blurred except the board · 10 hand-held recordings of about 66 s, CC BY-NC 4.0 · 2 robot-arm recordings of about 58 s, CC BY-NC 4.0 · ~ marks a value read past where the board corners reached. Past the fit: the edge lies beyond where the lens fit holds, so we give no value.
Demo and values
Section titled “Demo and values”Sensor head from Looper Robotics with two global-shutter mono cameras, one rolling-shutter colour camera and a 400 Hz IMU. Our own unit on a chessboard, and the hand-held and robot-arm recordings, are shown separately.
Reprojection is how far, in pixels, the detected corners lie from where the solve puts them. td is the camera–IMU time offset, and the lever arm is the camera–IMU position offset.
No reference exists for these recordings, so the values can't be checked for accuracy.
Calibration process
Section titled “Calibration process”The path of the rig around the board, as MVIS solved it. To explore it:
- Press Play or drag the bar to follow the path.
- Use the view buttons to change the view.
- Pick a camera card to put that camera on the frustum, the pyramid that shows its view.
Each card draws the board from the solved pose, with the corners MVIS detected. We publish no camera images.
Solved rig
Section titled “Solved rig”The solved rig in 3D, to scale. Tap a sensor to see its values. In full screen you can rotate and zoom. Grid squares are 20 mm.
To scale, from above and the front
| Camera | Lever x, y, z (mm) | Distance (mm) | log(R) (rad) | td (ms) | Field of view |
|---|---|---|---|---|---|
| cam0 | −11.9, +39.8, +18.4 | 45.4 | [+0.006, +0.003, −1.574] | +1.81 | 96° × 113° |
| cam1 | −11.8, −59.8, +17.6 | 63.4 | [+0.004, +0.001, −1.580] | +1.79 | 96° × 113° |
| cam2 | −11.8, −9.9, +17.4 | 23.3 | [+0.002, +0.009, −3.140] | −5.45 | ~149° × 82° |
| Camera | Lever x, y, z (mm) | Distance (mm) | log(R) (rad) | td (ms) | Field of view |
|---|---|---|---|---|---|
| cam0 | −12.9, +41.9, +15.8 | 46.6 | [+0.009, +0.007, −1.564] | +1.43 | 94° × 112° |
| cam1 | −12.2, −57.3, +14.9 | 60.4 | [+0.005, +0.006, −1.562] | +1.46 | 94° × 112° |
| cam2 | −12.5, −7.8, +14.6 | 20.7 | [−0.001, +0.013, −3.134] | −3.79 | ~154° × 82° |
| Camera | Lever x, y, z (mm) | Distance (mm) | log(R) (rad) | td (ms) | Field of view |
|---|---|---|---|---|---|
| cam0 | −13.1, +41.8, +14.3 | 46.1 | [+0.009, +0.007, −1.563] | +1.20 | 94° × 112° |
| cam1 | −12.4, −57.4, +13.4 | 60.2 | [+0.005, +0.005, −1.561] | +1.24 | 94° × 112° |
| cam2 | −12.7, −7.9, +13.0 | 19.9 | [−0.000, +0.013, −3.133] | −4.04 | ~152° × 82° |
Solved by MVIS. Lever arms (camera–IMU position offsets) are in the IMU frame. Rotation is log(R), camera in the IMU frame.
Specifications
Section titled “Specifications”| Published by the maker | |
|---|---|
| Type | Spatial AI camera |
| From our catalog | |
| Global-shutter cameras | 2 × 544×640 mono at 20 Hz, hardware-synced stereo |
| Rolling-shutter camera | 1 × 1088×1920 colour at about 4.3 Hz |
| Lens | Wide field of view; pinhole-equidistant fit |
| IMU | 1 × 400 Hz, with stamps quantized to 2.5 ms |
| Measured in these recordings | |
| Calibrated field of view | cam0 96° × 113° · cam1 96° × 113° · cam2 ~149° × 82° |
| Not published | |
| Open | Sensor part numbers |
Dataset
Section titled “Dataset”| Chessboard | 4 recordings of 36 to 61 s, our own unit: takes 01 to 03 warm (41 to 43 °C), take 04 at 55 °C. This page shows take 04 |
| Chessboard data | Calibench community, looper-insight9/data/ (access by automatic approval), takes 01 to 04 (this page shows take 04). Everything except the board is blurred. CC BY-NC 4.0, for the data, clip and figures; commercial use by request |
| Hand-held | 10 of about 66 s, 15.0 GB in all |
| Hand-held data | Calibench, looper-insight9/ (access by automatic approval). CC BY-NC 4.0, for the hand-held data, clip and figures; commercial use by request |
| Robot arm | 2 of about 58 s, same program in both |
| Robot-arm data | Calibench community, looper-insight9/data/ (access by automatic approval). Normal frames. CC BY-NC 4.0, for the data, clip and figures; commercial use by request |
| Board | Chessboard: 10×7 squares (9×6 inner corners), 43.47 mm, shown on a monitor. Hand-held and robot arm: AprilGrid 6×6, tag 55 mm, spacing 0.3, t36h11 |
| Configs and results | Calibench community, looper-insight9/ (access by automatic approval) |
| Worked example | Looper SA16 |
Detailed results
Section titled “Detailed results”Lens Calibrated field of view
Calibrated field of view, horizontal × vertical. cam0: 96° × 113°, corners reach 58° from the axis · cam1: 96° × 113°, corners reach 57° from the axis · cam2: ~149° × 82°, corners reach 60° from the axis
Calibrated field of view, horizontal × vertical. cam0: 94° × 112°, corners reach 68° from the axis · cam1: 94° × 112°, corners reach 70° from the axis · cam2: ~154° × 82°, corners reach 68° from the axis
Calibrated field of view, horizontal × vertical. cam0: 94° × 112°, corners reach 68° from the axis · cam1: 94° × 112°, corners reach 70° from the axis · cam2: ~152° × 82°, corners reach 68° from the axis
cam0 cam1 cam2
We read these from the calibrated lens fit at the image edges, through the principal point (where the optical axis meets the image). ~ marks an axis past where the corners reached, so the fit is extrapolated there. Past the fit means an edge lies beyond where the fit holds, so we give no value.
IMU Gyro–accel time offset t_ga −5.43 ms
Each bar shows a scale as its deviation from 1. IMU model: calyx. t_ga, the time offset between the gyroscope and accelerometer channels: −5.43 ± 0.03 ms.
Each bar shows a scale as its deviation from 1. IMU model: calyx. t_ga, the time offset between the gyroscope and accelerometer channels: −5.54 ± 0.05 ms.
Each bar shows a scale as its deviation from 1. IMU model: calyx. t_ga, the time offset between the gyroscope and accelerometer channels: −5.15 ± 0.05 ms.
Timing cam0 td +1.81 ms
The time offsets, to scale. td is the camera–IMU time offset, with t_imu = t_cam + td.
Full results Every solved parameter
Rotation is log(R) in rad, camera in the IMU frame.
| Parameter | MVIS |
|---|---|
| cam0 | |
| fx px | 330.82 |
| fy px | 330.65 |
| cx px | 270.35 |
| cy px | 320.15 |
| k1 | −0.02366 |
| k2 | 0.01731 |
| k3 | −0.02395 |
| k4 | 0.00895 |
| Lever x mm | −11.86 |
| Lever y mm | +39.77 |
| Lever z mm | +18.38 |
| log(R) rad | [+0.0056, +0.0030, −1.5745] |
| td ms | +1.812 |
| Reprojection px | 0.156 |
| cam1 | |
| fx px | 330.52 |
| fy px | 330.42 |
| cx px | 269.76 |
| cy px | 321.15 |
| k1 | −0.02632 |
| k2 | 0.02520 |
| k3 | −0.03435 |
| k4 | 0.01329 |
| Lever x mm | −11.80 |
| Lever y mm | −59.75 |
| Lever z mm | +17.62 |
| log(R) rad | [+0.0042, +0.0010, −1.5799] |
| td ms | +1.792 |
| Reprojection px | 0.163 |
| cam2 | |
| fx px | 769.74 |
| fy px | 769.82 |
| cx px | 959.50 |
| cy px | 538.16 |
| k1 | −0.03519 |
| k2 | 0.01102 |
| k3 | −0.01813 |
| k4 | 0.00942 |
| Lever x mm | −11.82 |
| Lever y mm | −9.93 |
| Lever z mm | +17.41 |
| log(R) rad | [+0.0018, +0.0086, −3.1403] |
| td ms | −5.445 |
| Reprojection px | 1.782 |
| Readout ms | +31.63 |
| IMU | |
| t_ga ms | −5.43 ± 0.03 |
| Parameter | MVIS |
|---|---|
| cam0 | |
| fx px | 334.10 |
| fy px | 334.11 |
| cx px | 271.90 |
| cy px | 318.20 |
| k1 | −0.02032 |
| k2 | 0.01012 |
| k3 | −0.01053 |
| k4 | 0.00178 |
| Lever x mm | −12.86 |
| Lever y mm | +41.93 |
| Lever z mm | +15.79 |
| log(R) rad | [+0.0087, +0.0071, −1.5640] |
| td ms | +1.426 |
| Reprojection px | 0.201 |
| cam1 | |
| fx px | 334.13 |
| fy px | 334.15 |
| cx px | 269.26 |
| cy px | 318.11 |
| k1 | −0.01969 |
| k2 | 0.00471 |
| k3 | 0.00020 |
| k4 | −0.00498 |
| Lever x mm | −12.24 |
| Lever y mm | −57.28 |
| Lever z mm | +14.94 |
| log(R) rad | [+0.0050, +0.0060, −1.5625] |
| td ms | +1.464 |
| Reprojection px | 0.200 |
| cam2 | |
| fx px | 776.13 |
| fy px | 776.18 |
| cx px | 959.87 |
| cy px | 535.91 |
| k1 | −0.03295 |
| k2 | −0.00753 |
| k3 | 0.01289 |
| k4 | −0.00654 |
| Lever x mm | −12.54 |
| Lever y mm | −7.80 |
| Lever z mm | +14.55 |
| log(R) rad | [−0.0008, +0.0133, −3.1345] |
| td ms | −3.787 |
| Reprojection px | 0.916 |
| Readout ms | +31.88 |
| IMU | |
| t_ga ms | −5.54 ± 0.05 |
| Parameter | MVIS |
|---|---|
| cam0 | |
| fx px | 334.23 |
| fy px | 334.24 |
| cx px | 271.76 |
| cy px | 318.32 |
| k1 | −0.02014 |
| k2 | 0.00866 |
| k3 | −0.00794 |
| k4 | 0.00057 |
| Lever x mm | −13.11 |
| Lever y mm | +41.82 |
| Lever z mm | +14.28 |
| log(R) rad | [+0.0087, +0.0067, −1.5630] |
| td ms | +1.197 |
| Reprojection px | 0.200 |
| cam1 | |
| fx px | 334.29 |
| fy px | 334.32 |
| cx px | 269.19 |
| cy px | 318.18 |
| k1 | −0.02012 |
| k2 | 0.00498 |
| k3 | 0.00092 |
| k4 | −0.00553 |
| Lever x mm | −12.40 |
| Lever y mm | −57.41 |
| Lever z mm | +13.42 |
| log(R) rad | [+0.0052, +0.0054, −1.5614] |
| td ms | +1.244 |
| Reprojection px | 0.198 |
| cam2 | |
| fx px | 776.30 |
| fy px | 776.35 |
| cx px | 959.91 |
| cy px | 535.93 |
| k1 | −0.03448 |
| k2 | −0.00168 |
| k3 | 0.00527 |
| k4 | −0.00339 |
| Lever x mm | −12.72 |
| Lever y mm | −7.94 |
| Lever z mm | +13.03 |
| log(R) rad | [−0.0000, +0.0131, −3.1334] |
| td ms | −4.044 |
| Reprojection px | 0.921 |
| Readout ms | +31.50 |
| IMU | |
| t_ga ms | −5.15 ± 0.05 |
Limits
Section titled “Limits”- No reference exists for these recordings, so the values can't be checked for accuracy.
- Hand-held and robot-arm recordings are kept apart, not pooled. They were solved in different batches and may not come from the same unit.
- The arm program rotates mostly about one axis, which leaves lever arms less well determined, so treat the arm's values with more caution.
- The chessboard recordings come from our own unit, not the partner's, and are shown on their own. The values shown come from take 04 alone, so they show no repeatability; all 4 takes are in the hosted data.
How it was run
Section titled “How it was run”- Camera + IMU with camera intrinsics free, t_ga and the cam2 rolling-shutter readout both estimated. Chessboard recordings of 2026-11-07; hand-held batch of 2026-11-02; robot-arm batch of 2026-11-04.