
RoboBaton Neo
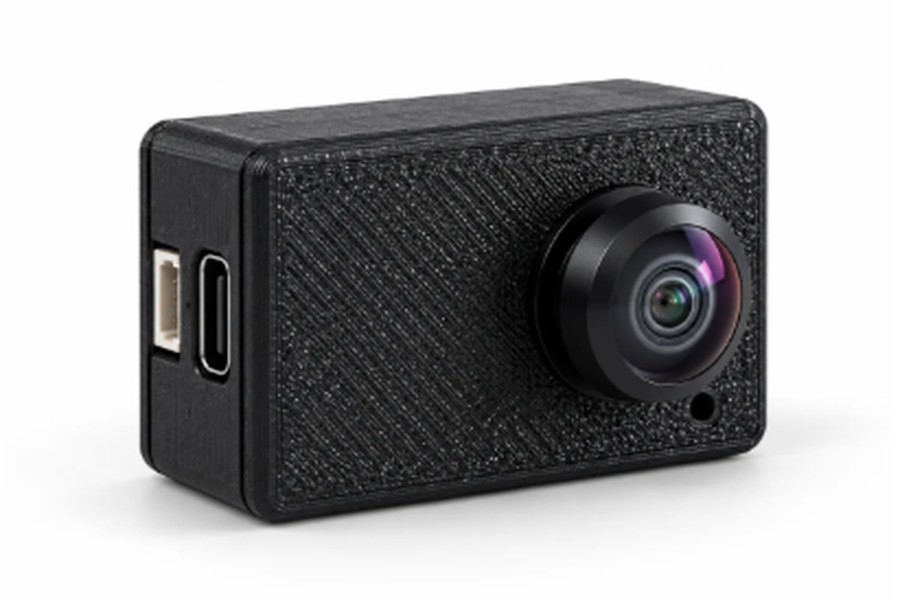
VIO module: global-shutter fisheye camera with a TDK ICM-42670-P IMU
SmartSens SC132GS MakerTDK InvenSense ICM-42670-P Maker ↗︎
- Cameras
- 544 × 640 here, 1080 × 1280 nativeMeasured
- Shutter
- GlobalMaker ↗︎
- Field of view
- Calibrated 126° × ~147°Measured
193.8° diagonalMaker ↗︎ - Baseline
- One camera in this runMeasured
- IMU
- 200 HzMeasured
TDK ICM-42670-PMaker ↗︎ - Output
- USB-C network stream, UART; EuRoC mav0 from the capture toolMaker ↗︎
Maker values from the Neo documentation site, read 2026-11-19 · 1 recording, 77 s · ~ marks a value read past where the board corners reached. Past the fit: the edge lies beyond where the lens fit holds, so we give no value.
Demo and values
Section titled “Demo and values”Small VIO module from RoboBaton, 8.7 g on a 40 × 20 mm board, with one global-shutter fisheye camera and a TDK ICM-42670-P IMU, hardware-triggered. One hand-held recording in front of an AprilGrid shown on a monitor, recorded by the module's own capture tool and solved as camera + IMU.
Reprojection is how far, in pixels, the detected corners lie from where the solve puts them. td is the camera–IMU time offset, and the lever arm is the camera–IMU position offset.
One recording, 5 frames per second. The maker's own calibration of the same recording agrees on the rotation (within 0.4°) and on the lever arm across the image (within 2 mm), but not along the optical axis (17 mm here against 9 mm) nor on the time offset (1.1 ms against 0.3 ms). A digital twin of the recording puts the noise on z at about 1 mm, so the gap is systematic; the image stamp convention and the tag size on the monitor are the open questions.
Calibration process
Section titled “Calibration process”The path of the rig around the board, as MVIS solved it. To explore it:
- Press Play or drag the bar to follow the path.
- Use the view buttons to change the view.
- Pick a camera card to put that camera on the frustum, the pyramid that shows its view.
Each card draws the board from the solved pose, with the corners MVIS detected. We publish no camera images.
Solved rig
Section titled “Solved rig”The solved rig in 3D, to scale. Tap a sensor to see its values. In full screen you can rotate and zoom. Grid squares are 20 mm.
To scale, from above and the front
| Camera | Lever x, y, z (mm) | Distance (mm) | log(R) (rad) | td (ms) | Field of view |
|---|---|---|---|---|---|
| cam0 | −24.6, +6.4, +17.3 | 30.8 | [−0.002, +0.006, −1.570] | +1.14 | 126° × ~147° |
Solved by MVIS. Lever arms (camera–IMU position offsets) are in the IMU frame. Rotation is log(R), camera in the IMU frame.
Specifications
Section titled “Specifications”| Published by the maker | |
|---|---|
| Maker | RoboBaton (documentation site; company name not given there) |
| Camera | SmartSens SC132GS, 1080 × 1280 native at 60 fps |
| Shutter | Global |
| Lens | Fisheye, 193.8° diagonal |
| IMU | TDK ICM-42670-P, gyro and accelerometer at 200 Hz with multi-sample averaging |
| Sync | Hardware-triggered camera and IMU on one clock |
| Link | USB-C (network adapter with an HTTP stream), 6-pin UART with trigger in and exposure out, microSD; 8.69 g bare, 13.86 g cased |
| Measured in these recordings | |
| Calibration stream | 544 × 640 at 5 Hz |
| Calibrated field of view | cam0 126° × ~147° |
Dataset
Section titled “Dataset”| Recording | 1 recording, 77 s, hand-held. 386 frames at 5 Hz, IMU at 200 Hz |
| Format | EuRoC mav0: PNG and IMU CSV, written by the module's capture tool |
| Board | AprilGrid, 6×6 tags of 25 mm, spacing 0.3, shown on a monitor |
| Data | Calibench-VI community, robobaton-neo/data/ (access by automatic approval). The recording as a ROS1 bag: every frame unchanged, the IMU rows of the camera window. Recorded by RoboBaton with the module's capture tool. CC BY-NC 4.0, for the data, clip and figures; commercial use by request |
| Configs and results | Calibench-VI community, robobaton-neo/ (access by automatic approval) |
Detailed results
Section titled “Detailed results”Lens Calibrated field of view
Calibrated field of view, horizontal × vertical. cam0: 126° × ~147°, corners reach 68° from the axis
cam0
We read these from the calibrated lens fit at the image edges, through the principal point (where the optical axis meets the image). ~ marks an axis past where the corners reached, so the fit is extrapolated there. Past the fit means an edge lies beyond where the fit holds, so we give no value.
IMU Gyro–accel time offset t_ga −0.27 ms
Each bar shows a scale as its deviation from 1. IMU model: calyx. t_ga, the time offset between the gyroscope and accelerometer channels: −0.27 ± 0.07 ms.
Timing cam0 td +1.14 ms
The time offsets, to scale. td is the camera–IMU time offset, with t_imu = t_cam + td.
Board shape peak to peak 1.1 mm
The calibration board isn't perfectly flat, so this solve estimated the height of every corner off the flat board along with the calibration. The board's mean plane and tilt belong to its pose, so a flat board shows only noise here.
Full results Every solved parameter
Rotation is log(R) in rad, camera in the IMU frame.
| Parameter | MVIS |
|---|---|
| cam0 | |
| fx px | 236.10 |
| fy px | 234.22 |
| cx px | 268.43 |
| cy px | 321.46 |
| k1 | 0.04271 |
| k2 | −0.00205 |
| k3 | −0.00126 |
| k4 | 0.00042 |
| Lever x mm | −24.64 |
| Lever y mm | +6.44 |
| Lever z mm | +17.34 |
| log(R) rad | [−0.0020, +0.0059, −1.5702] |
| td ms | +1.137 |
| Reprojection px | 0.501 |
| IMU | |
| t_ga ms | −0.27 ± 0.07 |
Limits
Section titled “Limits”- One recording, 5 frames per second. The maker's own calibration of the same recording agrees on the rotation (within 0.4°) and on the lever arm across the image (within 2 mm), but not along the optical axis (17 mm here against 9 mm) nor on the time offset (1.1 ms against 0.3 ms). A digital twin of the recording puts the noise on z at about 1 mm, so the gap is systematic; the image stamp convention and the tag size on the monitor are the open questions.
- The tag size, 25 mm, is the value in the capture tool's config, not a measurement on the monitor; it scales the lever arm.
- A double-sphere model fits as well as kb4, but its focal length and xi trade off along a flat valley, so only the projection is comparable between the two.
How it was run
Section titled “How it was run”- Camera with the IMU in one solve. Kannala-Brandt (kb4) fisheye intrinsics seeded from a single-camera solve of the same recording and left free; the camera time offset, IMU scale and misalignment and the gyro-to-accel offset t_ga estimated. The board shape is estimated per corner. IMU noise is the ICM-42670-P datasheet value times three. Solved 2026-11-19.