
VI-Rig — 5 IMUs + 4 cameras
Two RealSense T265 units and five IMUs on one frame, recorded in front of an AprilGrid. The two units are not synced to each other, so the only link between their clocks is the motion that every sensor sees. This makes it a test of time offsets across many sensors.
- Hub folder:
calibench-vi/datasets→virig-5imus-4cams - Licence: CC BY-NC 4.0, gated; commercial use on request. See Licence and access.
- Results: results page · worked example
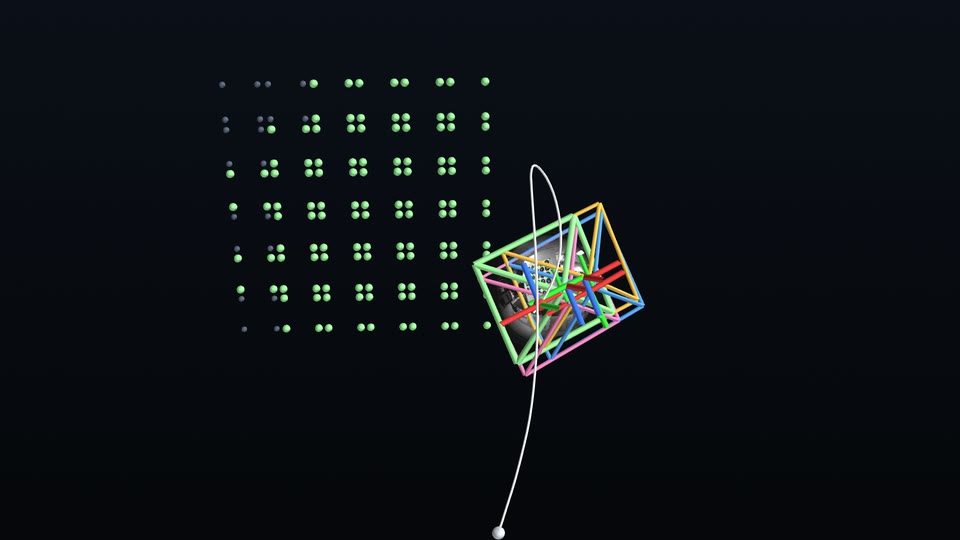
The rig
Section titled “The rig”Rates are measured from the bags. Every camera is a global-shutter fisheye.
| Sensor | Type | Rate | Image size | ROS topic |
|---|---|---|---|---|
| T265 unit A, left | camera, fisheye (about 163°) | 30 Hz | 848×800 | /t265_01/fisheye1/image_raw |
| T265 unit A, right | camera, fisheye (about 163°) | 30 Hz | 848×800 | /t265_01/fisheye2/image_raw |
| T265 unit B, left | camera, fisheye (about 163°) | 30 Hz | 848×800 | /t265_03/fisheye1/image_raw |
| T265 unit B, right | camera, fisheye (about 163°) | 30 Hz | 848×800 | /t265_03/fisheye2/image_raw |
| Xsens MTi | IMU | 400 Hz | – | /mti/sensor/imu_raw |
| MicroStrain 3DM-GX3-25 | IMU | 500 Hz | – | /gx3_25/data |
| MicroStrain 3DM-GX3-35 | IMU | 100 Hz | – | /gx3_35/imu/data |
| T265 unit A IMU (BMI055) | IMU | 200 Hz | – | /t265_01/imu |
| T265 unit B IMU (BMI055) | IMU | 200 Hz | – | /t265_03/imu |
- Sync: the two cameras inside one T265 are hardware-synced. The two units are not synced to each other.
- Board: the same AprilGrid as the other VI-Rig sets (6×6 tags of family t36h11, tag size 88 mm). The target
file
april.yamlis in the folder. - Board shape: the printed board is not flat. Our camera + IMU runs estimate its shape; see Why calibrate the board shape.
- More on the T265: device page.
Recordings
Section titled “Recordings”- Count: 7 ROS1 bags,
5imus_4cams_01.bagto5imus_4cams_07.bag. - Length: 41 to 64 s each, about 6 minutes in total.
- Size: 3.3 to 5.2 GB each, 28 GB in total.
Download
Section titled “Download”Accept the terms on the Hub page and set
HF_TOKEN to a read token from your Hugging Face settings (or run hf auth login once,
after pip install huggingface_hub). Then either:
# with MVIS: checks size and SHA-256, saves to $MVIS_DATASETS/vi_sensor_rigs_5imus/mvis datasets list --dataset vi_sensor_rigs_5imusmvis datasets download --select vi_sensor_rigs_5imus/bag_01 # one recording, 5.2 GBmvis datasets download --dataset vi_sensor_rigs_5imus # all 7, 28 GB# with the Hugging Face CLI: recordings, board file and our resultshf download calibench-vi/datasets --repo-type dataset \ --include "virig-5imus-4cams/*" --local-dir ./calibenchResults
Section titled “Results”This set has a separate study (2026-11-02), outside the leaderboard batch. We ran MVIS only; Kalibr and Basalt were not run on it, so nothing is compared.
| Run | Recordings solved |
|---|---|
| Camera only, one T265 pair per run | MVIS 7 of 7 (each pair) |
| Camera + IMU, 4 cameras + 5 IMUs in one run | MVIS 7 of 7 |
- How we ran it: each camera-only run holds one T265 pair, with no time offset, because the two units share no clock. The camera + IMU runs hold all four cameras and all five IMUs, with the Xsens as base IMU. Their camera intrinsics start from the median of the 7 camera-only runs.
- Results files on the Hub: the folder
results/2026-11-02/holds the run configs, the camera-only calibrations, the camera intrinsics prior and, per recording, the camera + IMU result (cam_imu.json, the calibration YAML, a Kalibr-style camchain and the estimated board shape). It has numbers only, no images.
A few MVIS values from the camera + IMU runs. Each is the median over the 7 recordings, ± the standard deviation between recordings. This shows how well MVIS repeats, not that it is right.
- Gyro-to-accelerometer delay of the T265 IMUs: −6.59 ± 0.08 ms (unit A), −6.65 ± 0.10 ms (unit B). The other three IMUs stay within 0.6 ms of zero. The T265 delay depends on how fast the rig moves, so read it as a compromise value; see Why calibrate t_ga.
- T265 unit A stereo baseline: 63.66 ± 0.12 mm
- Reprojection error, median: 0.21 to 0.23 px over the four cameras
Run it yourself
Section titled “Run it yourself”- Start here: the worked example has the camera + IMU config we ran.
- Steps: see Multi-IMU calibration and Camera–IMU calibration.
This set has no paper yet. Please cite Calibench; the BibTeX is on the overview page.