
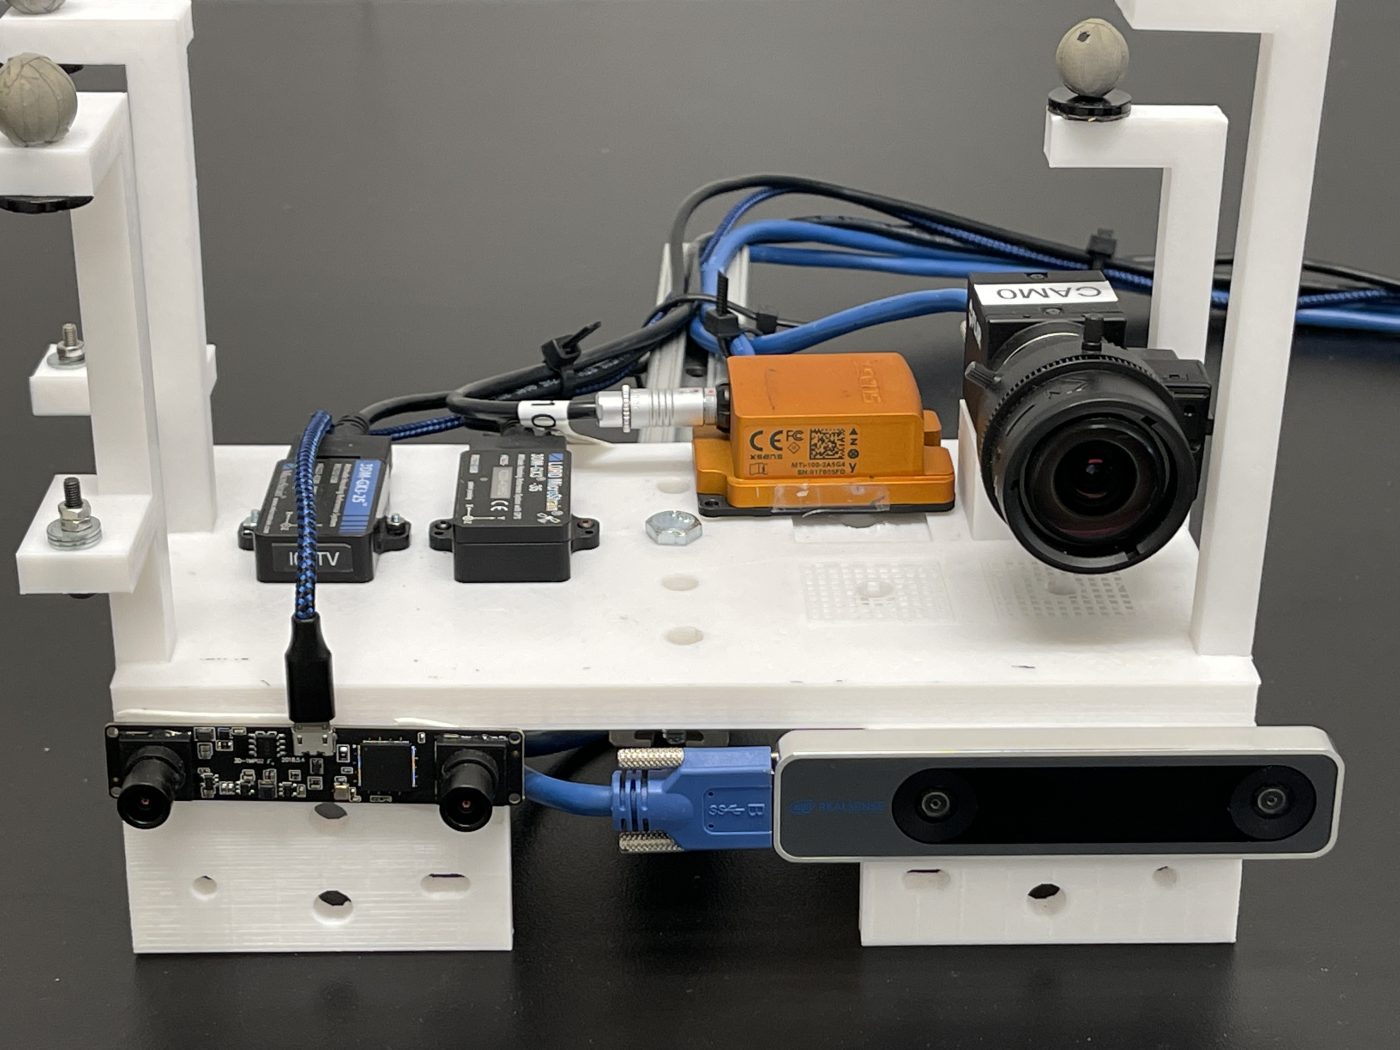
VI-Rig: 4 IMUs + 3 cameras
Repeatability, not accuracy. There is no ground truth: a small spread shows that a tool repeats, not that it is right, and a difference shows that two tools disagree, not which one is wrong. The MVIS authors made every run, including Kalibr and Basalt.
Repeatability
Section titled “Repeatability”| Family | Focal + pp px | Distortion | Distance mm | Time offset ms | Cam–IMU distance mm | Gyro | Accel |
|---|---|---|---|---|---|---|---|
| T6c · camera n = 10 matched 3 GS cameras — camera calibration | MVIS = Basalt> Kalibr ×4.6 ab | MVIS = Basalt> Kalibr ×9.9 cab | Kalibr only | — | — | — | — |
| T6 · cam+IMU n = 10 matched 3 GS cameras + 4 IMUs | input, not compared | input, not compared | input, not compared | Tie de | MVIS ×3.4 d | MVIS ×2.5K-IMU df | MVIS ×2.7K-IMU df |
T6c · camera · 3 GS cameras — camera calibration More repeatable or tie: Focal + pp MVIS = Basalt > Kalibr · Distortion MVIS = Basalt > Kalibr n = 10 matched · MVIS 10 of 10 · Kalibr 10 of 10 · Basalt 10 of 10
T6 · cam+IMU · 3 GS cameras + 4 IMUs More repeatable or tie: Time offset tie · Cam–IMU distance MVIS · Gyro MVIS K-IMU · Accel MVIS K-IMU n = 10 matched · MVIS 10 of 10 · Kalibr 10 of 10 · Basalt not run
- Time offsetTiede
- Cam–IMU distance MVIS×3.4d
- Gyro MVIS×2.5K-IMUdf
- Accel MVIS×2.7K-IMUdf
- Focal + pp · Distortion · Distance: input, not compared
MVIS Kalibr Basalt tool ×k more repeatable: the other tools' typical scatter is k times larger Tie gap within chance or under 20 % too few under 6 shared recordings input no comparison, reason in the cell K-IMU MVIS run with Kalibr's IMU model
k = the looser tool's typical scatter divided by the tighter tool's (median over the group's parameters, on the recordings every compared tool ran). Click a cell for its numbers.
- a Basalt's fisheye-2 frames are snapped onto fisheye-1 (1.8–5 ms apart).
- b The tool pairs here use different parameters, because one tool is not compared on every camera; the cell lists which.
- c Coefficients trade off against each other, so their scatter can overstate differences in the lens mapping.
- d Data settings still differ between the tools on this family.
- e MVIS also fits a gyro–accel delay (t_ga) that Kalibr and Basalt do not, so its td is not quite the same quantity.
- f MVIS here uses Kalibr's IMU model, so the gyro and accel terms mean the same thing in both tools.
Each cell is a separate comparison on the recordings every compared tool ran. Cells are not added up and nothing is ordered across datasets.
Not part of this comparison
- T6 reprojection error (3 rows): fit quality, not repeatability and not accuracy
- T6 IMU g-sensitivity Tg (36 rows): Kalibr absorbs it in its IMU model
- T6 gyro–accel delay t_ga (4 rows): MVIS only
- T6 Basalt: not run: one IMU per run; no run holds the whole rig
Focal length + principal point · T6c · 10 matched recordings (MVIS 10 of 10 · Kalibr 10 of 10 · Basalt 10 of 10) · 3 GS cameras — camera calibration, camera
The spreads of MVIS and Basalt differ by 1.00×, but a gap this size appears often by chance with 10 recordings (p = 0.99). Treated as a tie. Both scatter less than Kalibr: across the same 10 recordings Kalibr's estimates scatter about 4.6× more than MVIS's and 5.1× more than Basalt's. Holds with any one recording left out.
MVIS here: the camera values of the T6 camera+IMU solve.
| Pair | R | 95 % interval | p (Holm) | Decision | Leave one out |
|---|---|---|---|---|---|
| MVIS ÷ Kalibr · 12 param. | 0.22 | 0.13 – 0.39 | 0.0059 (raw 0.002) | MVIS tighter | holds with any one recording left out |
| MVIS ÷ Basalt · 8 param. | 1 | 0.83 – 1.74 | 0.99 | tie: gap within chance | |
| Kalibr ÷ Basalt · 8 param. | 5.07 | 2.89 – 14.33 | 0.0059 (raw 0.002) | Basalt tighter | holds with any one recording left out |
| Parameter | MVIS sd | Kalibr sd | Basalt sd |
|---|---|---|---|
| Blackfly · fx px | 0.983 | 2.17 | – |
| Blackfly · fy px | 1.12 | 2.5 | – |
| Blackfly · cx px | 0.551 | 3.28 | – |
| Blackfly · cy px | 0.661 | 1.44 | – |
| t265 fisheye 1 · fx px | 0.392 | 1.61 | 0.403 |
| t265 fisheye 1 · fy px | 0.316 | 1.69 | 0.332 |
| t265 fisheye 1 · cx px | 0.205 | 0.553 | 0.204 |
| t265 fisheye 1 · cy px | 0.207 | 1.09 | 0.175 |
| t265 fisheye 2 · fx px | 0.395 | 1.99 | 0.395 |
| t265 fisheye 2 · fy px | 0.317 | 2.08 | 0.333 |
| t265 fisheye 2 · cx px | 0.217 | 0.589 | 0.204 |
| t265 fisheye 2 · cy px | 0.164 | 1.01 | 0.135 |
- Basalt · shown only · 4 rows: other camera model (pinhole-radtan8)
- a Basalt's fisheye-2 frames are snapped onto fisheye-1 (1.8–5 ms apart).
- b The tool pairs here use different parameters, because one tool is not compared on every camera; the cell lists which.
Repeatability only — a tool can repeat well and still be biased.
Distortion coefficients · T6c · 10 matched recordings (MVIS 10 of 10 · Kalibr 10 of 10 · Basalt 10 of 10) · 3 GS cameras — camera calibration, camera
The spreads of MVIS and Basalt differ by 1.5×, but a gap this size appears often by chance with 10 recordings (p = 0.055). Treated as a tie. Both scatter less than Kalibr: across the same 10 recordings Kalibr's estimates scatter about 9.9× more than MVIS's and 19× more than Basalt's. Holds with any one recording left out.
MVIS here: the camera values of the T6 camera+IMU solve.
| Pair | R | 95 % interval | p (Holm) | Decision | Leave one out |
|---|---|---|---|---|---|
| MVIS ÷ Kalibr · 12 param. | 0.1 | 0.05 – 0.32 | 0.0059 (raw 0.002) | MVIS tighter | holds with any one recording left out |
| MVIS ÷ Basalt · 8 param. | 1.47 | 1 – 2.74 | 0.055 | tie: gap within chance | |
| Kalibr ÷ Basalt · 8 param. | 19.49 | 4.54 – 66.05 | 0.0059 (raw 0.002) | Basalt tighter | holds with any one recording left out |
| Parameter | MVIS sd | Kalibr sd | Basalt sd |
|---|---|---|---|
| Blackfly · dist k1 | 0.00256 | 0.00996 | – |
| Blackfly · dist k2 | 0.00261 | 0.00889 | – |
| Blackfly · dist p1 | 0.000167 | 0.000385 | – |
| Blackfly · dist p2 | 0.000185 | 0.000954 | – |
| t265 fisheye 1 · dist k1 | 0.00155 | 0.0188 | 0.00115 |
| t265 fisheye 1 · dist k2 | 0.0037 | 0.042 | 0.00248 |
| t265 fisheye 1 · dist k3 | 0.00435 | 0.0373 | 0.00239 |
| t265 fisheye 1 · dist k4 | 0.0017 | 0.011 | 0.000761 |
| t265 fisheye 2 · dist k1 | 0.0013 | 0.0324 | 0.00104 |
| t265 fisheye 2 · dist k2 | 0.00336 | 0.0785 | 0.00276 |
| t265 fisheye 2 · dist k3 | 0.00419 | 0.073 | 0.00289 |
| t265 fisheye 2 · dist k4 | 0.00171 | 0.0224 | 0.001 |
- Basalt · shown only · 4 rows: other camera model (pinhole-radtan8)
- c Coefficients trade off against each other, so their scatter can overstate differences in the lens mapping.
- a Basalt's fisheye-2 frames are snapped onto fisheye-1 (1.8–5 ms apart).
- b The tool pairs here use different parameters, because one tool is not compared on every camera; the cell lists which.
Repeatability only — a tool can repeat well and still be biased.
Camera–camera distance · T6c · Kalibr only (MVIS no value · Kalibr 10 of 10 · Basalt no value) · 3 GS cameras — camera calibration, camera
Kalibr only: no value for this tool
- MVIS · missing · 2 rows: no value for this tool
- Basalt · missing · 2 rows: not in one run
Repeatability only — a tool can repeat well and still be biased.
Focal length + principal point · T6 · Input, not compared (MVIS 10 of 10 · Kalibr input · Basalt not run) · 3 GS cameras + 4 IMUs, cam+IMU
Kalibr's camera+IMU run starts from these values, exported from MVIS for each recording, and keeps them fixed. Their spread copies the input, so it is not Kalibr's repeatability.
- Kalibr · input, not compared · 12 rows: Kalibr's camera+IMU run starts from these values, exported from MVIS for each recording, and keeps them fixed. Their spread copies the input, so it is not Kalibr's repeatability.
- Basalt · 12 rows: not run: one IMU per run; no run holds the whole rig
Repeatability only — a tool can repeat well and still be biased.
Distortion coefficients · T6 · Input, not compared (MVIS 10 of 10 · Kalibr input · Basalt not run) · 3 GS cameras + 4 IMUs, cam+IMU
Kalibr's camera+IMU run starts from these values, exported from MVIS for each recording, and keeps them fixed. Their spread copies the input, so it is not Kalibr's repeatability.
- Kalibr · input, not compared · 12 rows: Kalibr's camera+IMU run starts from these values, exported from MVIS for each recording, and keeps them fixed. Their spread copies the input, so it is not Kalibr's repeatability.
- Basalt · 12 rows: not run: one IMU per run; no run holds the whole rig
Repeatability only — a tool can repeat well and still be biased.
Camera–camera distance · T6 · Input, not compared (MVIS 10 of 10 · Kalibr input · Basalt not run) · 3 GS cameras + 4 IMUs, cam+IMU
Kalibr's camera+IMU run starts from these values, exported from MVIS for each recording, and keeps them fixed. Their spread copies the input, so it is not Kalibr's repeatability.
- Kalibr · input, not compared · 2 rows: Kalibr's camera+IMU run starts from these values, exported from MVIS for each recording, and keeps them fixed. Their spread copies the input, so it is not Kalibr's repeatability.
- Basalt · 2 rows: not run: one IMU per run; no run holds the whole rig
Repeatability only — a tool can repeat well and still be biased.
Camera–IMU time offset · T6 · 10 matched recordings (MVIS 10 of 10 · Kalibr 10 of 10 · Basalt not run) · 3 GS cameras + 4 IMUs, cam+IMU
The spreads of MVIS and Kalibr differ by 1.03×, but a gap this size appears often by chance with 10 recordings (p = 0.73). Treated as a tie.
MVIS here: its default IMU model.
| Pair | R | 95 % interval | p (Holm) | Decision | Leave one out |
|---|---|---|---|---|---|
| MVIS ÷ Kalibr · 6 param. | 1.03 | 0.82 – 1.33 | 0.73 | tie: gap within chance |
| Parameter | MVIS sd | Kalibr sd | Ratio |
|---|---|---|---|
| Blackfly · time offset td to base IMU ms | 0.0964 | 0.149 | 0.65 |
| t265 fisheye 1 · time offset td to base IMU ms | 0.155 | 0.247 | 0.63 |
| t265 fisheye 2 · time offset td to base IMU ms | 0.237 | 0.244 | 0.97 |
| GX3-25 · time delay td to base IMU ms | 0.208 | 0.189 | 1.10 |
| GX3-35 · time delay td to base IMU ms | 0.209 | 0.17 | 1.23 |
| t265 IMU · time delay td to base IMU ms | 0.212 | 0.188 | 1.13 |
- Basalt · 6 rows: not run: one IMU per run; no run holds the whole rig
- d Data settings still differ between the tools on this family.
- e MVIS also fits a gyro–accel delay (t_ga) that Kalibr and Basalt do not, so its td is not quite the same quantity.
Repeatability only — a tool can repeat well and still be biased.
Camera–IMU distance · T6 · 10 matched recordings (MVIS 10 of 10 · Kalibr 10 of 10 · Basalt not run) · 3 GS cameras + 4 IMUs, cam+IMU
Across the same 10 recordings, Kalibr's estimates scatter about 3.4× more than MVIS's (median over 6 parameters). A gap this large appeared in 0.59 % of recording-by-recording swaps. Holds with any one recording left out.
MVIS here: its default IMU model.
| Pair | R | 95 % interval | p (Holm) | Decision | Leave one out |
|---|---|---|---|---|---|
| MVIS ÷ Kalibr · 6 param. | 0.29 | 0.16 – 0.51 | 0.0059 | MVIS tighter | holds with any one recording left out |
| Parameter | MVIS sd | Kalibr sd | Ratio |
|---|---|---|---|
| Blackfly · distance to base IMU ‖p‖ mm | 1.41 | 3.64 | 0.39 |
| t265 fisheye 1 · distance to base IMU ‖p‖ mm | 1.48 | 3.19 | 0.46 |
| t265 fisheye 2 · distance to base IMU ‖p‖ mm | 1.7 | 3.99 | 0.43 |
| GX3-25 · distance to base IMU ‖p‖ mm | 0.198 | 0.883 | 0.22 |
| GX3-35 · distance to base IMU ‖p‖ mm | 0.189 | 0.862 | 0.22 |
| t265 IMU · distance to base IMU ‖p‖ mm | 0.194 | 1.42 | 0.14 |
- Basalt · 6 rows: not run: one IMU per run; no run holds the whole rig
- d Data settings still differ between the tools on this family.
Repeatability only — a tool can repeat well and still be biased.
Gyro scale + cross-axis · T6 · 10 matched recordings (MVIS 10 of 10 · Kalibr 10 of 10 · Basalt not run) · 3 GS cameras + 4 IMUs, cam+IMU
Across the same 10 recordings, Kalibr's estimates scatter about 2.5× more than MVIS's (median over 24 parameters). A gap this large appeared in 0.59 % of recording-by-recording swaps. Holds with any one recording left out.
MVIS here: its run with Kalibr's IMU model (K-IMU).
| Pair | R | 95 % interval | p (Holm) | Decision | Leave one out |
|---|---|---|---|---|---|
| MVIS ÷ Kalibr · 24 param. | 0.4 | 0.25 – 0.6 | 0.0059 | MVIS tighter | holds with any one recording left out |
| Parameter | MVIS sd | Kalibr sd | Ratio |
|---|---|---|---|
| Xsens MTi · gyro Dw[0,0] scale x | 0.00149 | 0.00344 | 0.43 |
| Xsens MTi · gyro Dw[1,1] scale y | 0.00051 | 0.00182 | 0.28 |
| Xsens MTi · gyro Dw[2,2] scale z | 0.00201 | 0.00248 | 0.81 |
| Xsens MTi · gyro Dw[1,0] cross | 0.000808 | 0.00266 | 0.30 |
| Xsens MTi · gyro Dw[2,0] cross | 0.00143 | 0.00393 | 0.36 |
| Xsens MTi · gyro Dw[2,1] cross | 0.00144 | 0.00345 | 0.42 |
| GX3-25 · gyro Dw[0,0] scale x | 0.000544 | 0.00193 | 0.28 |
| GX3-25 · gyro Dw[1,1] scale y | 0.00161 | 0.0039 | 0.41 |
| GX3-25 · gyro Dw[2,2] scale z | 0.00235 | 0.00197 | 1.19 |
| GX3-25 · gyro Dw[1,0] cross | 0.000649 | 0.00239 | 0.27 |
| GX3-25 · gyro Dw[2,0] cross | 0.00149 | 0.00333 | 0.45 |
| GX3-25 · gyro Dw[2,1] cross | 0.0016 | 0.00438 | 0.37 |
| GX3-35 · gyro Dw[0,0] scale x | 0.000392 | 0.00172 | 0.23 |
| GX3-35 · gyro Dw[1,1] scale y | 0.0016 | 0.00388 | 0.41 |
| GX3-35 · gyro Dw[2,2] scale z | 0.00228 | 0.00211 | 1.08 |
| GX3-35 · gyro Dw[1,0] cross | 0.000785 | 0.00242 | 0.32 |
| GX3-35 · gyro Dw[2,0] cross | 0.00131 | 0.0032 | 0.41 |
| GX3-35 · gyro Dw[2,1] cross | 0.00175 | 0.00448 | 0.39 |
| t265 IMU · gyro Dw[0,0] scale x | 0.00139 | 0.00344 | 0.40 |
| t265 IMU · gyro Dw[1,1] scale y | 0.00203 | 0.00276 | 0.74 |
| t265 IMU · gyro Dw[2,2] scale z | 0.000568 | 0.00208 | 0.27 |
| t265 IMU · gyro Dw[1,0] cross | 0.00163 | 0.00408 | 0.40 |
| t265 IMU · gyro Dw[2,0] cross | 0.000649 | 0.00264 | 0.25 |
| t265 IMU · gyro Dw[2,1] cross | 0.00141 | 0.00351 | 0.40 |
- Basalt · 24 rows: not run: one IMU per run; no run holds the whole rig
- d Data settings still differ between the tools on this family.
- f MVIS here uses Kalibr's IMU model, so the gyro and accel terms mean the same thing in both tools.
Repeatability only — a tool can repeat well and still be biased.
Accel scale · T6 · 10 matched recordings (MVIS 10 of 10 · Kalibr 10 of 10 · Basalt not run) · 3 GS cameras + 4 IMUs, cam+IMU
Across the same 10 recordings, Kalibr's estimates scatter about 2.7× more than MVIS's (median over 12 parameters). A gap this large appeared in 0.2 % of recording-by-recording swaps. Holds with any one recording left out.
MVIS here: its run with Kalibr's IMU model (K-IMU).
| Pair | R | 95 % interval | p (Holm) | Decision | Leave one out |
|---|---|---|---|---|---|
| MVIS ÷ Kalibr · 12 param. | 0.37 | 0.27 – 0.58 | 0.002 | MVIS tighter | holds with any one recording left out |
| Parameter | MVIS sd | Kalibr sd | Ratio |
|---|---|---|---|
| Xsens MTi · accel Da[0,0] scale x | 0.000437 | 0.000925 | 0.47 |
| Xsens MTi · accel Da[1,1] scale y | 0.00163 | 0.00332 | 0.49 |
| Xsens MTi · accel Da[2,2] scale z | 0.00132 | 0.00292 | 0.45 |
| GX3-25 · accel Da[0,0] scale x | 0.00179 | 0.00627 | 0.29 |
| GX3-25 · accel Da[1,1] scale y | 0.000409 | 0.00167 | 0.24 |
| GX3-25 · accel Da[2,2] scale z | 0.00137 | 0.00239 | 0.57 |
| GX3-35 · accel Da[0,0] scale x | 0.00173 | 0.0053 | 0.33 |
| GX3-35 · accel Da[1,1] scale y | 0.000384 | 0.00149 | 0.26 |
| GX3-35 · accel Da[2,2] scale z | 0.00133 | 0.00315 | 0.42 |
| t265 IMU · accel Da[0,0] scale x | 0.000525 | 0.00611 | 0.09 |
| t265 IMU · accel Da[1,1] scale y | 0.0016 | 0.00544 | 0.29 |
| t265 IMU · accel Da[2,2] scale z | 0.002 | 0.00206 | 0.97 |
- Basalt · 12 rows: not run: one IMU per run; no run holds the whole rig
- d Data settings still differ between the tools on this family.
- f MVIS here uses Kalibr's IMU model, so the gyro and accel terms mean the same thing in both tools.
Repeatability only — a tool can repeat well and still be biased.
T6 · camera + IMU
Section titled “T6 · camera + IMU”3 GS cameras + 4 IMUs · 10 recordings
Read first: Kalibr's intrinsics and baselines are inputs from its own camera-only calibration; its td and lever are solved given them. Data settings differ: see Notes.
Repeatability Focal + ppDistortionDistanceTime offsetCam–IMU distanceGyroKAccelK
Coverage
Section titled “Coverage”- MVIS 10 of 10
- Kalibr 10 of 10
- Basalt 0 of 10 not run: one IMU per run; no run holds the whole rig
MVIS made two runs per recording: its default IMU model ("MVIS") and Kalibr's IMU model ("MVIS (K-IMU)"), so the IMU terms of the second mean the same thing as Kalibr's.
Records behind these numbers: MVIS T6.json · Kalibr T6.json · Basalt T6.json
Fit: reprojection median, px (fit of each tool's own model, not accuracy)
| Camera | MVIS | MVIS (K-IMU) | Kalibr |
|---|---|---|---|
| Blackfly | 0.349 | 0.349 | 0.483 |
| t265 fisheye 1 | 0.225 | 0.225 | 0.272 |
| t265 fisheye 2 | 0.239 | 0.239 | 0.288 |
Where the tools differ
Section titled “Where the tools differ”MVIS (K-IMU) − Kalibr ◆ 21 of 48 compared rows
- Blackfly · time offset td to base IMU +1.145 ms ◆
- Blackfly · distance to base IMU ‖p‖ −2.09 mm
- t265 fisheye 1 · time offset td to base IMU +0.977 ms ◆
- t265 fisheye 1 · distance to base IMU ‖p‖ −3.83 mm ◆
- t265 fisheye 2 · time offset td to base IMU +0.980 ms ◆
- t265 fisheye 2 · distance to base IMU ‖p‖ −2.63 mm
- Xsens MTi · gyro Dw[0,0] scale x −0.00135
- Xsens MTi · gyro Dw[1,1] scale y +0.00099
- Xsens MTi · gyro Dw[2,2] scale z −0.00406 ◆
- Xsens MTi · gyro Dw[1,0] cross −0.00382 ◆
- Xsens MTi · gyro Dw[2,0] cross −0.00353
- Xsens MTi · gyro Dw[2,1] cross −0.01034 ◆
- Xsens MTi · accel Da[0,0] scale x −0.00017
- Xsens MTi · accel Da[1,1] scale y +0.00132
- Xsens MTi · accel Da[2,2] scale z −0.00433 ◆
- GX3-25 · gyro Dw[0,0] scale x +0.00140
- GX3-25 · gyro Dw[1,1] scale y −0.00078
- GX3-25 · gyro Dw[2,2] scale z −0.00712 ◆
- GX3-25 · gyro Dw[1,0] cross −0.00155
- GX3-25 · gyro Dw[2,0] cross +0.00929 ◆
- GX3-25 · gyro Dw[2,1] cross +0.00293
- GX3-25 · accel Da[0,0] scale x +0.00134
- GX3-25 · accel Da[1,1] scale y −0.00267 ◆
- GX3-25 · accel Da[2,2] scale z −0.00116
- GX3-25 · time delay td to base IMU +0.101 ms
- GX3-25 · distance to base IMU ‖p‖ +2.05 mm ◆
- GX3-35 · gyro Dw[0,0] scale x +0.00070
- GX3-35 · gyro Dw[1,1] scale y −0.00264
- GX3-35 · gyro Dw[2,2] scale z −0.00710 ◆
- GX3-35 · gyro Dw[1,0] cross −0.00250 ◆
- GX3-35 · gyro Dw[2,0] cross +0.00923 ◆
- GX3-35 · gyro Dw[2,1] cross +0.00381
- GX3-35 · accel Da[0,0] scale x +0.00130
- GX3-35 · accel Da[1,1] scale y −0.00232 ◆
- GX3-35 · accel Da[2,2] scale z −0.00614 ◆
- GX3-35 · time delay td to base IMU +0.068 ms
- GX3-35 · distance to base IMU ‖p‖ +1.12 mm ◆
- t265 IMU · gyro Dw[0,0] scale x −0.00172
- t265 IMU · gyro Dw[1,1] scale y −0.00439 ◆
- t265 IMU · gyro Dw[2,2] scale z +0.00146
- t265 IMU · gyro Dw[1,0] cross −0.00376
- t265 IMU · gyro Dw[2,0] cross +0.00216
- t265 IMU · gyro Dw[2,1] cross +0.01034 ◆
- t265 IMU · accel Da[0,0] scale x +0.00386
- t265 IMU · accel Da[1,1] scale y +0.00452
- t265 IMU · accel Da[2,2] scale z +0.00388 ◆
- t265 IMU · time delay td to base IMU +0.077 ms
- t265 IMU · distance to base IMU ‖p‖ +0.74 mm
Dot = median difference Δ on an axis in units of the larger of the two tools' sd; shaded = ±1 sd; filled dot and ◆ = outside it; an arrow = beyond ±5 sd. No tool is the reference. "≠n" = the tools solved different recordings.
Parameters by sensor
Section titled “Parameters by sensor”7 sensors, 78 parameter charts (open to see each tool's spread)
fx px axis 448 ± 4.56
fy px axis 448 ± 5.91
cx px axis 371 ± 12.9
cy px axis 281 ± 5.41
dist k1 axis −0.312 ± 0.0285
dist k2 axis 0.0809 ± 0.0216
dist p1 axis −0.000333 ± 0.000911
dist p2 axis −0.000119 ± 0.00177
time offset td to base IMU ms axis −4.29 ± 1.48
distance to base IMU ‖p‖ mm axis 89.4 ± 6.96
fx px axis 287 ± 4.39
fy px axis 287 ± 4.97
cx px axis 415 ± 2.05
cy px axis 404 ± 3.25
dist k1 axis −0.0034 ± 0.0387
dist k2 axis 0.032 ± 0.0824
dist k3 axis −0.0305 ± 0.0731
dist k4 axis 0.00456 ± 0.0218
baseline to Blackfly mm axis 71.3 ± 3.4
time offset td to base IMU ms axis −5.02 ± 1.45
distance to base IMU ‖p‖ mm axis 130 ± 9.13
fx px axis 287 ± 4.4
fy px axis 286 ± 4.94
cx px axis 415 ± 2.26
cy px axis 398 ± 3.15
dist k1 axis −0.00397 ± 0.0915
dist k2 axis 0.0344 ± 0.231
dist k3 axis −0.0314 ± 0.215
dist k4 axis 0.0043 ± 0.0656
baseline to Blackfly mm axis 69.8 ± 8.23
time offset td to base IMU ms axis −7.8 ± 1.58
distance to base IMU ‖p‖ mm axis 111 ± 8.97
gyro Dw[0,0] scale x axis 0.999 ± 0.0115 · line at 1
gyro Dw[1,1] scale y axis 0.997 ± 0.00527 · line at 1
gyro Dw[2,2] scale z axis 1 ± 0.00617 · line at 1
gyro Dw[1,0] cross axis 0.000438 ± 0.00645
gyro Dw[2,0] cross axis 0.00506 ± 0.0102
gyro Dw[2,1] cross axis 0.00696 ± 0.0126
accel Da[0,0] scale x axis 1 ± 0.00209 · line at 1
accel Da[1,1] scale y axis 0.996 ± 0.0059 · line at 1
accel Da[2,2] scale z axis 1 ± 0.0069 · line at 1
t_ga gyro−accel ms axis −0.307 ± 0.225
gyro Dw[0,0] scale x axis 0.999 ± 0.00529 · line at 1
gyro Dw[1,1] scale y axis 1 ± 0.013 · line at 1
gyro Dw[2,2] scale z axis 1.01 ± 0.00673 · line at 1
gyro Dw[1,0] cross axis −0.000326 ± 0.00409
gyro Dw[2,0] cross axis −0.00705 ± 0.0118
gyro Dw[2,1] cross axis 0.00024 ± 0.0116
accel Da[0,0] scale x axis 0.997 ± 0.0171 · line at 1
accel Da[1,1] scale y axis 1 ± 0.00466 · line at 1
accel Da[2,2] scale z axis 1 ± 0.00531 · line at 1
time delay td to base IMU ms axis −0.0322 ± 0.583 · line at 0
distance to base IMU ‖p‖ mm axis 131 ± 4.3
t_ga gyro−accel ms axis 0.147 ± 0.194 · line at 0
gyro Dw[0,0] scale x axis 0.999 ± 0.00456 · line at 1
gyro Dw[1,1] scale y axis 1 ± 0.0138 · line at 1
gyro Dw[2,2] scale z axis 1.01 ± 0.00698 · line at 1
gyro Dw[1,0] cross axis −0.000355 ± 0.00512
gyro Dw[2,0] cross axis −0.0064 ± 0.011
gyro Dw[2,1] cross axis −0.00422 ± 0.0122
accel Da[0,0] scale x axis 0.996 ± 0.0131 · line at 1
accel Da[1,1] scale y axis 1 ± 0.0041 · line at 1
accel Da[2,2] scale z axis 1 ± 0.0106 · line at 1
time delay td to base IMU ms axis −1.61 ± 0.496
distance to base IMU ‖p‖ mm axis 94.7 ± 3.29
t_ga gyro−accel ms axis 0.0811 ± 0.196 · line at 0
gyro Dw[0,0] scale x axis 0.998 ± 0.0117 · line at 1
gyro Dw[1,1] scale y axis 1.01 ± 0.0074 · line at 1
gyro Dw[2,2] scale z axis 1 ± 0.00626 · line at 1
gyro Dw[1,0] cross axis 0.00429 ± 0.00885
gyro Dw[2,0] cross axis 0.00188 ± 0.00607
gyro Dw[2,1] cross axis −0.00687 ± 0.0107
accel Da[0,0] scale x axis 1.02 ± 0.015
accel Da[1,1] scale y axis 1.02 ± 0.0106
accel Da[2,2] scale z axis 1.01 ± 0.00559
time delay td to base IMU ms axis 2.83 ± 0.552
distance to base IMU ‖p‖ mm axis 125 ± 3.09
t_ga gyro−accel ms axis −6.56 ± 0.121
Whisker = lowest to highest value over the tool's solved recordings; box = median ± sd; tick = median. Min and max come from the per-recording values behind each record's median; only these two numbers are published, not the values. Rotations are not shown: the records do not hold them yet.
Model notes and how each tool was run
Section titled “Model notes and how each tool was run”6 notes on models, inputs and run settings
- Kalibr: 26 values are input, not estimated (hollow boxes). Their spread copies the input, so it is not that tool's repeatability.
- t_ga, the gyro–accel delay, is estimated by MVIS only; Kalibr and Basalt have no such term, so MVIS's td is not quite the same quantity.
- Tg, the IMU g-sensitivity, is a term of Kalibr's IMU model, here from MVIS (K-IMU) and Kalibr; the MVIS default model has no counterpart, so it is not compared.
Kalibr IMU-model terms Tg (median; sd on hover)
- Basalt not run: Basalt cannot calibrate T6 — one IMU per run (the rig has four) and frames grouped by exact stamp (the t265 pair and the Blackfly share none), so no single run holds the rig.
- Like for like: MVIS uses two corners per tag, non-base cameras at 4 Hz or lower and an estimated board shape; Kalibr has none of these. Every tool uses the same IMU noise, measured at rest (the rig's noisiest IMU, one set for all four IMUs). Kalibr's runs date from 2026-11-08.
- Note: Kalibr starts from its own camera-only calibration of each bag. Every tool uses the same IMU noise, measured at rest on the rig's noisiest IMU.
Run configs, commands and the full parameter tables are in Full tables at the end of this page.
T6c · camera only
Section titled “T6c · camera only”3 GS cameras — camera calibration · 10 recordings
Read first: MVIS runs the Blackfly and the t265 pair separately, so it has no baseline to the Blackfly; Kalibr solves the three cameras jointly.
Repeatability Focal + ppDistortionDistanceTime offsetCam–IMU distanceGyroAccel
Coverage
Section titled “Coverage”- MVIS 10 of 10
- Kalibr 10 of 10
- Basalt 10 of 10
Records behind these numbers: MVIS T6c.json · Kalibr T6c.json · Basalt T6c.json
Where the tools differ
Section titled “Where the tools differ”MVIS − Kalibr ◆ 5 of 24 compared rows
- Blackfly · fx +3.20 px ◆
- Blackfly · fy +4.21 px ◆
- Blackfly · cx +1.13 px
- Blackfly · cy +1.50 px ◆
- Blackfly · dist k1 −0.00609
- Blackfly · dist k2 +0.00711
- Blackfly · dist p1 −0.00008
- Blackfly · dist p2 −0.00027
- t265 fisheye 1 · fx +0.58 px
- t265 fisheye 1 · fy +0.82 px
- t265 fisheye 1 · cx −0.67 px ◆
- t265 fisheye 1 · cy −0.10 px
- t265 fisheye 1 · dist k1 −0.00617
- t265 fisheye 1 · dist k2 +0.01371
- t265 fisheye 1 · dist k3 −0.00847
- t265 fisheye 1 · dist k4 +0.00180
- t265 fisheye 2 · fx +0.91 px
- t265 fisheye 2 · fy +1.15 px
- t265 fisheye 2 · cx −0.86 px ◆
- t265 fisheye 2 · cy −0.16 px
- t265 fisheye 2 · dist k1 −0.00837
- t265 fisheye 2 · dist k2 +0.01637
- t265 fisheye 2 · dist k3 −0.01037
- t265 fisheye 2 · dist k4 +0.00352
Basalt − Kalibr ◆ 2 of 16 compared rows
- t265 fisheye 1 · fx +0.45 px
- t265 fisheye 1 · fy +0.47 px
- t265 fisheye 1 · cx −0.83 px ◆
- t265 fisheye 1 · cy −0.05 px
- t265 fisheye 1 · dist k1 −0.00621
- t265 fisheye 1 · dist k2 +0.01800
- t265 fisheye 1 · dist k3 −0.01508
- t265 fisheye 1 · dist k4 +0.00434
- t265 fisheye 2 · fx +0.68 px
- t265 fisheye 2 · fy +0.75 px
- t265 fisheye 2 · cx −0.86 px ◆
- t265 fisheye 2 · cy −0.24 px
- t265 fisheye 2 · dist k1 −0.00773
- t265 fisheye 2 · dist k2 +0.01934
- t265 fisheye 2 · dist k3 −0.01523
- t265 fisheye 2 · dist k4 +0.00483
Basalt − MVIS ◆ 6 of 16 compared rows
- t265 fisheye 1 · fx −0.13 px
- t265 fisheye 1 · fy −0.35 px ◆
- t265 fisheye 1 · cx −0.16 px
- t265 fisheye 1 · cy +0.06 px
- t265 fisheye 1 · dist k1 −0.00004
- t265 fisheye 1 · dist k2 +0.00429 ◆
- t265 fisheye 1 · dist k3 −0.00662 ◆
- t265 fisheye 1 · dist k4 +0.00254 ◆
- t265 fisheye 2 · fx −0.23 px
- t265 fisheye 2 · fy −0.40 px ◆
- t265 fisheye 2 · cx 0.00 px
- t265 fisheye 2 · cy −0.08 px
- t265 fisheye 2 · dist k1 +0.00064
- t265 fisheye 2 · dist k2 +0.00297
- t265 fisheye 2 · dist k3 −0.00486 ◆
- t265 fisheye 2 · dist k4 +0.00131
Dot = median difference Δ on an axis in units of the larger of the two tools' sd; shaded = ±1 sd; filled dot and ◆ = outside it; an arrow = beyond ±5 sd. No tool is the reference. "≠n" = the tools solved different recordings.
Parameters by sensor
Section titled “Parameters by sensor”3 sensors, 26 parameter charts (open to see each tool's spread)
fx px axis 448 ± 4.61
fy px axis 447 ± 5.23
cx px axis 369 ± 11.2
cy px axis 279 ± 3.03
dist k1 axis −0.311 ± 0.0277
dist k2 axis 0.0809 ± 0.0216
dist p1 axis 0.0000684 ± 0.000807
dist p2 axis 0.00000759 ± 0.00191
fx px axis 286 ± 3.38
fy px axis 286 ± 3.75
cx px axis 415 ± 2.23
cy px axis 404 ± 2.69
dist k1 axis −0.00451 ± 0.04
dist k2 axis 0.0368 ± 0.0877
dist k3 axis −0.034 ± 0.0769
dist k4 axis 0.00501 ± 0.0223
baseline to Blackfly mm axis 71.9 ± 4.05
fx px axis 286 ± 3.96
fy px axis 285 ± 4.2
cx px axis 415 ± 2.24
cy px axis 398 ± 2.61
dist k1 axis −0.00554 ± 0.0898
dist k2 axis 0.0401 ± 0.225
dist k3 axis −0.0367 ± 0.21
dist k4 axis 0.00632 ± 0.0634
baseline to Blackfly mm axis 71.6 ± 6.27
Whisker = lowest to highest value over the tool's solved recordings; box = median ± sd; tick = median. Min and max come from the per-recording values behind each record's median; only these two numbers are published, not the values. Rotations are not shown: the records do not hold them yet.
Model notes and how each tool was run
Section titled “Model notes and how each tool was run”4 notes on models, inputs and run settings
- Basalt: 8 values come from another model (hatched lanes), so they are printed and not compared.
- Like for like: MVIS uses two corners per tag and estimates the board shape; Kalibr uses all four corners and assumes a flat board.
- Note: MVIS runs camera-only per bag, the Blackfly alone and the t265 pair (the rig's cameras share no frame stamps), so it has no baseline to the Blackfly; Kalibr's 10 camera-only runs solve the three cameras jointly.
- Basalt: t265 pair (kb4, fisheye 2 snapped onto fisheye 1) and Blackfly alone (pinhole-radtan8, a different model from radtan: its intrinsics are shown only); no camera-only Basalt run holds both devices, so no baselines to the Blackfly.
Run configs, commands and the full parameter tables are in Full tables at the end of this page.
Full tables
Section titled “Full tables”Every parameter table, tool difference and run config (VI-Rig 4 IMUs + 3 cams)
How to read this
- Spread shows repeatability across recordings, not accuracy. A tool can repeat well and still be biased.
448.50 ± 0.48 (10): median ± sd across the 10 recordings that tool solved. With 3 or 4 recordings the sd itself is rough.(3/15): this tool has 3 of the family's 15 recordings.fixed: Kalibr doesn't estimate this value. Its camera + IMU runs take intrinsics and baselines as input, from an MVIS export or, on T6 and T11, from its own camera-only calibration; T7 ELP-L readout is held at 0. The spread here isn't repeatability.shown: the tool uses a different model here, so the value has no difference next to it.other model: Kalibr's coefficients here belong to a different lens model.not in model,not reported,no run,no data,no RS model,not in one run: the tool has no value for this row, and the words say why.no runmeans the tool never ran with this sensor;not in one runmeans it ran with each sensor, but no single run holds both ends of the baseline.not run, in the recordings line: the tool has no run for the family.- Differences: the column header gives the subtraction, using stored medians. No tool is the reference.
◆: the difference is larger than the larger of the two sds. It marks disagreement, not an error in either tool.≠n: the two medians come from different numbers of recordings.≠ model: the tools' models differ, so no difference is shown.fit: reprojection error measures fit and isn't comparable across models.‡ td: MVIS splits the IMU into gyro (td) and accel (td + t_ga); Kalibr and Basalt have one timeline. Basalt − Kalibr is the like-for-like check.- Each family folds; the first is open. Click a family's title to open or close it.
No ground truth: ◆ marks disagreement, not who is right.
median ± sd (recordings) · (3/15) partial · fixed Kalibr input · shown / other model, no Δ · ≠ model, fit: no Δ · ◆ |Δ| above the larger sd · ≠n different recording counts · ‡ see How to read this
On camera + IMU families the MVIS column uses Kalibr's IMU model, not the MVIS default. The default fills fewer rows and is in a closed fold under each family.
Key and MVIS column
Swipe a table sideways for the other tools and differences.
median ± sd (recordings) · (3/15) partial · fixed Kalibr input · shown / other model, no Δ · ≠ model, fit: no Δ · ◆ |Δ| above the larger sd · ≠n different recording counts · ‡ see How to read this
On camera + IMU families the MVIS column uses Kalibr's IMU model, not the MVIS default. The default fills fewer rows and is in a closed fold under each family.
T6c · 3 GS cameras — camera calibration
MVIS 10 of 10 · Kalibr 10 of 10 · Basalt 10 of 10, Blackfly shown only
Camera · april 01–10 · Kalibr kalibr_calibrate_cameras, 3 cameras jointly
Read first: MVIS runs the Blackfly and the t265 pair separately, so it has no baseline to the Blackfly; Kalibr solves the three cameras jointly.
Notes
Like for like: MVIS uses two corners per tag and estimates the board shape; Kalibr uses all four corners and assumes a flat board.
Note: MVIS runs camera-only per bag, the Blackfly alone and the t265 pair (the rig's cameras share no frame stamps), so it has no baseline to the Blackfly; Kalibr's 10 camera-only runs solve the three cameras jointly.
Basalt: t265 pair (kb4, fisheye 2 snapped onto fisheye 1) and Blackfly alone (pinhole-radtan8, a different model from radtan: its intrinsics are shown only); no camera-only Basalt run holds both devices, so no baselines to the Blackfly.
cam0 – Blackfly · 8 rows · ◆ 3
| Parameter | MVIS | Kalibr | Basalt | MVIS− Kalibr |
|---|---|---|---|---|
| fx px | 449.95 ± 0.98 (10) | 446.75 ± 2.17 (10) | shown 448.12 ± 1.02 (10) | ◆ +3.20 |
| fy px | 449.10 ± 1.12 (10) | 444.89 ± 2.50 (10) | shown 446.93 ± 0.98 (10) | ◆ +4.21 |
| cx px | 369.81 ± 0.55 (10) | 368.67 ± 3.28 (10) | shown 368.56 ± 0.47 (10) | +1.13 |
| cy px | 279.90 ± 0.66 (10) | 278.41 ± 1.44 (10) | shown 281.06 ± 0.51 (10) | ◆ +1.50 |
| dist k1 | −0.31405 ± 0.00256 (10) | −0.30796 ± 0.00996 (10) | shown 0.31003 ± 6.46473 (10) | −0.00609 |
| dist k2 | 0.084 ± 0.003 (10) | 0.077 ± 0.009 (10) | shown 11.204 ± 13.707 (10) | +0.007 |
| dist p1 | 0.00003 ± 0.00017 (10) | 0.00011 ± 0.00038 (10) | shown −0.00034 ± 0.00026 (10) | −0.00008 |
| dist p2 | −0.00013 ± 0.00018 (10) | 0.00014 ± 0.00095 (10) | shown −0.00032 ± 0.00024 (10) | −0.00027 |
cam1 – t265 fisheye 1 · 9 rows · ◆ 5
| Parameter | MVIS | Kalibr | Basalt | MVIS− Kalibr | Basalt− Kalibr | Basalt− MVIS |
|---|---|---|---|---|---|---|
| fx px | 286.30 ± 0.39 (10) | 285.72 ± 1.61 (10) | 286.17 ± 0.40 (10) | +0.58 | +0.45 | −0.13 |
| fy px | 285.95 ± 0.32 (10) | 285.13 ± 1.69 (10) | 285.60 ± 0.33 (10) | +0.82 | +0.47 | ◆ −0.35 |
| cx px | 415.16 ± 0.20 (10) | 415.83 ± 0.55 (10) | 415.00 ± 0.20 (10) | ◆ −0.67 | ◆ −0.83 | −0.16 |
| cy px | 403.99 ± 0.21 (10) | 404.09 ± 1.09 (10) | 404.05 ± 0.17 (10) | −0.10 | −0.05 | +0.06 |
| dist k1 | −0.00451 ± 0.00155 (10) | 0.00165 ± 0.01882 (10) | −0.00455 ± 0.00115 (10) | −0.00617 | −0.00621 | −0.00004 |
| dist k2 | 0.03678 ± 0.00370 (10) | 0.02307 ± 0.04201 (10) | 0.04107 ± 0.00248 (10) | +0.01371 | +0.01800 | ◆ +0.00429 |
| dist k3 | −0.03395 ± 0.00435 (10) | −0.02549 ± 0.03728 (10) | −0.04057 ± 0.00239 (10) | −0.00847 | −0.01508 | ◆ −0.00662 |
| dist k4 | 0.00501 ± 0.00170 (10) | 0.00321 ± 0.01100 (10) | 0.00755 ± 0.00076 (10) | +0.00180 | +0.00434 | ◆ +0.00254 |
| baseline to Blackfly mm | not in one run | 71.856 ± 1.457 (10) | not in one run |
cam2 – t265 fisheye 2 · 9 rows · ◆ 3
| Parameter | MVIS | Kalibr | Basalt | MVIS− Kalibr | Basalt− Kalibr | Basalt− MVIS |
|---|---|---|---|---|---|---|
| fx px | 286.28 ± 0.39 (10) | 285.37 ± 1.99 (10) | 286.05 ± 0.39 (10) | +0.91 | +0.68 | −0.23 |
| fy px | 285.73 ± 0.32 (10) | 284.57 ± 2.08 (10) | 285.32 ± 0.33 (10) | +1.15 | +0.75 | ◆ −0.40 |
| cx px | 414.58 ± 0.22 (10) | 415.44 ± 0.59 (10) | 414.58 ± 0.20 (10) | ◆ −0.86 | ◆ −0.86 | 0.00 |
| cy px | 398.45 ± 0.16 (10) | 398.62 ± 1.01 (10) | 398.38 ± 0.13 (10) | −0.16 | −0.24 | −0.08 |
| dist k1 | −0.00618 ± 0.00130 (10) | 0.00218 ± 0.03237 (10) | −0.00554 ± 0.00104 (10) | −0.00837 | −0.00773 | +0.00064 |
| dist k2 | 0.04011 ± 0.00336 (10) | 0.02374 ± 0.07849 (10) | 0.04308 ± 0.00276 (10) | +0.01637 | +0.01934 | +0.00297 |
| dist k3 | −0.03668 ± 0.00419 (10) | −0.02631 ± 0.07301 (10) | −0.04154 ± 0.00289 (10) | −0.01037 | −0.01523 | ◆ −0.00486 |
| dist k4 | 0.00632 ± 0.00171 (10) | 0.00280 ± 0.02243 (10) | 0.00763 ± 0.00100 (10) | +0.00352 | +0.00483 | +0.00131 |
| baseline to Blackfly mm | not in one run | 71.630 ± 2.455 (10) | not in one run |
T6 · 3 GS cameras + 4 IMUs
MVIS 10 of 10 · Kalibr 10 of 10 · Basalt not run
Camera + IMU · april 01–10 · Kalibr 3 cameras + 4 IMUs jointly
Read first: Kalibr's intrinsics and baselines are inputs from its own camera-only calibration; its td and lever are solved given them. Data settings differ: see Notes.
Notes, including why Basalt has no run
Basalt not run: Basalt cannot calibrate T6 — one IMU per run (the rig has four) and frames grouped by exact stamp (the t265 pair and the Blackfly share none), so no single run holds the rig.
Like for like: MVIS uses two corners per tag, non-base cameras at 4 Hz or lower and an estimated board shape; Kalibr has none of these. Every tool uses the same IMU noise, measured at rest (the rig's noisiest IMU, one set for all four IMUs). Kalibr's runs date from 2026-11-08.
Note: Kalibr starts from its own camera-only calibration of each bag. Every tool uses the same IMU noise, measured at rest on the rig's noisiest IMU.
cam0 – Blackfly · 11 rows · ◆ 1
| Parameter | MVISKalibr IMU model | Kalibr | MVIS− Kalibr |
|---|---|---|---|
| fx px | 448.30 ± 0.61 (10) | fixed 446.75 ± 2.17 (10) | |
| fy px | 447.62 ± 0.58 (10) | fixed 444.89 ± 2.50 (10) | |
| cx px | 370.78 ± 0.71 (10) | fixed 368.67 ± 3.28 (10) | |
| cy px | 281.31 ± 0.69 (10) | fixed 278.41 ± 1.44 (10) | |
| dist k1 | −0.31178 ± 0.00310 (10) | fixed −0.30796 ± 0.00996 (10) | |
| dist k2 | 0.08088 ± 0.00268 (10) | fixed 0.07731 ± 0.00889 (10) | |
| dist p1 | −0.00033 ± 0.00010 (10) | fixed 0.00011 ± 0.00038 (10) | |
| dist p2 | −0.00012 ± 0.00013 (10) | fixed 0.00014 ± 0.00095 (10) | |
| time offset td to base IMU‡ ms | −4.293 ± 0.093 (10) | −5.438 ± 0.149 (10) | ◆ +1.145 |
| distance to base IMU ‖p‖ mm | 89.32 ± 1.41 (10) | 91.41 ± 3.64 (10) | −2.09 |
| reproj median px | 0.349 ± 0.032 (10) | 0.483 ± 0.209 (10) | fit |
cam1 – t265 fisheye 1 · 12 rows · ◆ 2
| Parameter | MVISKalibr IMU model | Kalibr | MVIS− Kalibr |
|---|---|---|---|
| fx px | 287.08 ± 0.36 (10) | fixed 285.72 ± 1.61 (10) | |
| fy px | 286.70 ± 0.34 (10) | fixed 285.13 ± 1.69 (10) | |
| cx px | 415.32 ± 0.27 (10) | fixed 415.83 ± 0.55 (10) | |
| cy px | 403.53 ± 0.25 (10) | fixed 404.09 ± 1.09 (10) | |
| dist k1 | −0.00341 ± 0.00286 (10) | fixed 0.00165 ± 0.01882 (10) | |
| dist k2 | 0.03197 ± 0.00592 (10) | fixed 0.02307 ± 0.04201 (10) | |
| dist k3 | −0.03046 ± 0.00596 (10) | fixed −0.02549 ± 0.03728 (10) | |
| dist k4 | 0.00456 ± 0.00208 (10) | fixed 0.00321 ± 0.01100 (10) | |
| baseline to Blackfly mm | 71.267 ± 0.140 (10) | fixed 71.856 ± 1.457 (10) | |
| time offset td to base IMU‡ ms | −5.022 ± 0.149 (10) | −5.999 ± 0.247 (10) | ◆ +0.977 |
| distance to base IMU ‖p‖ mm | 130.10 ± 1.48 (10) | 133.92 ± 3.19 (10) | ◆ −3.83 |
| reproj median px | 0.225 ± 0.013 (10) | 0.272 ± 0.126 (10) | fit |
cam2 – t265 fisheye 2 · 12 rows · ◆ 1
| Parameter | MVISKalibr IMU model | Kalibr | MVIS− Kalibr |
|---|---|---|---|
| fx px | 287.02 ± 0.33 (10) | fixed 285.37 ± 1.99 (10) | |
| fy px | 286.40 ± 0.32 (10) | fixed 284.57 ± 2.08 (10) | |
| cx px | 414.56 ± 0.32 (10) | fixed 415.44 ± 0.59 (10) | |
| cy px | 397.96 ± 0.28 (10) | fixed 398.62 ± 1.01 (10) | |
| dist k1 | −0.00397 ± 0.00264 (10) | fixed 0.00218 ± 0.03237 (10) | |
| dist k2 | 0.03443 ± 0.00611 (10) | fixed 0.02374 ± 0.07849 (10) | |
| dist k3 | −0.03139 ± 0.00675 (10) | fixed −0.02631 ± 0.07301 (10) | |
| dist k4 | 0.00430 ± 0.00258 (10) | fixed 0.00280 ± 0.02243 (10) | |
| baseline to Blackfly mm | 69.849 ± 0.327 (10) | fixed 71.630 ± 2.455 (10) | |
| time offset td to base IMU‡ ms | −7.798 ± 0.237 (10) | −8.778 ± 0.244 (10) | ◆ +0.980 |
| distance to base IMU ‖p‖ mm | 111.39 ± 1.72 (10) | 114.03 ± 3.99 (10) | −2.63 |
| reproj median px | 0.239 ± 0.014 (10) | 0.288 ± 0.140 (10) | fit |
base IMU – Xsens MTi · 19 rows · ◆ 4
| Parameter | MVISKalibr IMU model | Kalibr | MVIS− Kalibr |
|---|---|---|---|
| gyro Dw[0,0] scale x | 0.99863 ± 0.00149 (10) | 0.99998 ± 0.00344 (10) | −0.00135 |
| gyro Dw[1,1] scale y | 0.99778 ± 0.00051 (10) | 0.99679 ± 0.00182 (10) | +0.00099 |
| gyro Dw[2,2] scale z | 1.00183 ± 0.00201 (10) | 1.00589 ± 0.00248 (10) | ◆ −0.00406 |
| gyro Dw[1,0] cross | −0.00147 ± 0.00081 (10) | 0.00235 ± 0.00266 (10) | ◆ −0.00382 |
| gyro Dw[2,0] cross | 0.00329 ± 0.00143 (10) | 0.00682 ± 0.00393 (10) | −0.00353 |
| gyro Dw[2,1] cross | 0.00179 ± 0.00144 (10) | 0.01213 ± 0.00345 (10) | ◆ −0.01034 |
| accel Da[0,0] scale x | 0.99988 ± 0.00044 (10) | 1.00005 ± 0.00093 (10) | −0.00017 |
| accel Da[1,1] scale y | 0.99681 ± 0.00163 (10) | 0.99549 ± 0.00332 (10) | +0.00132 |
| accel Da[2,2] scale z | 1.00043 ± 0.00132 (10) | 1.00476 ± 0.00292 (10) | ◆ −0.00433 |
| Tg[0,0] g-sensitivity mrad·s/m | 0.016 ± 0.048 (10) | 0.512 ± 0.824 (10) | ≠ model |
| Tg[0,1] g-sensitivity mrad·s/m | 0.074 ± 0.087 (10) | 0.042 ± 0.564 (10) | ≠ model |
| Tg[0,2] g-sensitivity mrad·s/m | 0.053 ± 0.085 (10) | 2.760 ± 1.449 (10) | ≠ model |
| Tg[1,0] g-sensitivity mrad·s/m | −0.033 ± 0.033 (10) | 0.184 ± 0.967 (10) | ≠ model |
| Tg[1,1] g-sensitivity mrad·s/m | −0.004 ± 0.064 (10) | 0.032 ± 0.643 (10) | ≠ model |
| Tg[1,2] g-sensitivity mrad·s/m | 0.020 ± 0.086 (10) | 3.582 ± 1.728 (10) | ≠ model |
| Tg[2,0] g-sensitivity mrad·s/m | 0.012 ± 0.074 (10) | 0.101 ± 0.275 (10) | ≠ model |
| Tg[2,1] g-sensitivity mrad·s/m | 0.058 ± 0.090 (10) | −1.158 ± 0.364 (10) | ≠ model |
| Tg[2,2] g-sensitivity mrad·s/m | −0.100 ± 0.087 (10) | 0.093 ± 0.296 (10) | ≠ model |
| t_ga gyro−accel ms | −0.307 ± 0.109 (10) | not in model |
aux IMU – GX3-25 · 21 rows · ◆ 4
| Parameter | MVISKalibr IMU model | Kalibr | MVIS− Kalibr |
|---|---|---|---|
| gyro Dw[0,0] scale x | 0.99989 ± 0.00054 (10) | 0.99849 ± 0.00193 (10) | +0.00140 |
| gyro Dw[1,1] scale y | 1.00107 ± 0.00161 (10) | 1.00185 ± 0.00390 (10) | −0.00078 |
| gyro Dw[2,2] scale z | 1.00310 ± 0.00235 (10) | 1.01022 ± 0.00197 (10) | ◆ −0.00712 |
| gyro Dw[1,0] cross | −0.00110 ± 0.00065 (10) | 0.00045 ± 0.00239 (10) | −0.00155 |
| gyro Dw[2,0] cross | −0.00240 ± 0.00149 (10) | −0.01170 ± 0.00333 (10) | ◆ +0.00929 |
| gyro Dw[2,1] cross | 0.00170 ± 0.00160 (10) | −0.00122 ± 0.00438 (10) | +0.00293 |
| accel Da[0,0] scale x | 0.99729 ± 0.00179 (10) | 0.99594 ± 0.00627 (10) | +0.00134 |
| accel Da[1,1] scale y | 1.00073 ± 0.00041 (10) | 1.00340 ± 0.00167 (10) | ◆ −0.00267 |
| accel Da[2,2] scale z | 1.00040 ± 0.00137 (10) | 1.00156 ± 0.00239 (10) | −0.00116 |
| Tg[0,0] g-sensitivity mrad·s/m | 0.041 ± 0.110 (10) | −1.083 ± 0.406 (10) | ≠ model |
| Tg[0,1] g-sensitivity mrad·s/m | 0.038 ± 0.060 (10) | −0.181 ± 0.517 (10) | ≠ model |
| Tg[0,2] g-sensitivity mrad·s/m | −0.072 ± 0.126 (10) | 1.498 ± 0.973 (10) | ≠ model |
| Tg[1,0] g-sensitivity mrad·s/m | 0.001 ± 0.092 (10) | −0.526 ± 0.339 (10) | ≠ model |
| Tg[1,1] g-sensitivity mrad·s/m | −0.026 ± 0.056 (10) | −0.033 ± 0.398 (10) | ≠ model |
| Tg[1,2] g-sensitivity mrad·s/m | 0.038 ± 0.076 (10) | 1.217 ± 0.829 (10) | ≠ model |
| Tg[2,0] g-sensitivity mrad·s/m | −0.036 ± 0.087 (10) | −0.224 ± 0.341 (10) | ≠ model |
| Tg[2,1] g-sensitivity mrad·s/m | 0.002 ± 0.067 (10) | 0.131 ± 0.245 (10) | ≠ model |
| Tg[2,2] g-sensitivity mrad·s/m | −0.103 ± 0.091 (10) | 1.146 ± 0.569 (10) | ≠ model |
| time delay td to base IMU‡ ms | −0.032 ± 0.209 (10) | −0.133 ± 0.189 (10) | +0.101 |
| distance to base IMU ‖p‖ mm | 131.31 ± 0.20 (10) | 129.26 ± 0.88 (10) | ◆ +2.05 |
| t_ga gyro−accel ms | 0.147 ± 0.068 (10) | not in model |
aux IMU – GX3-35 · 21 rows · ◆ 6
| Parameter | MVISKalibr IMU model | Kalibr | MVIS− Kalibr |
|---|---|---|---|
| gyro Dw[0,0] scale x | 0.99888 ± 0.00039 (10) | 0.99818 ± 0.00172 (10) | +0.00070 |
| gyro Dw[1,1] scale y | 0.99978 ± 0.00160 (10) | 1.00242 ± 0.00388 (10) | −0.00264 |
| gyro Dw[2,2] scale z | 1.00149 ± 0.00228 (10) | 1.00859 ± 0.00211 (10) | ◆ −0.00710 |
| gyro Dw[1,0] cross | −0.00161 ± 0.00078 (10) | 0.00090 ± 0.00242 (10) | ◆ −0.00250 |
| gyro Dw[2,0] cross | −0.00179 ± 0.00131 (10) | −0.01102 ± 0.00320 (10) | ◆ +0.00923 |
| gyro Dw[2,1] cross | −0.00232 ± 0.00175 (10) | −0.00612 ± 0.00448 (10) | +0.00381 |
| accel Da[0,0] scale x | 0.99673 ± 0.00173 (10) | 0.99543 ± 0.00530 (10) | +0.00130 |
| accel Da[1,1] scale y | 1.00005 ± 0.00038 (10) | 1.00237 ± 0.00149 (10) | ◆ −0.00232 |
| accel Da[2,2] scale z | 1.00009 ± 0.00133 (10) | 1.00623 ± 0.00315 (10) | ◆ −0.00614 |
| Tg[0,0] g-sensitivity mrad·s/m | 0.006 ± 0.100 (10) | −0.924 ± 0.474 (10) | ≠ model |
| Tg[0,1] g-sensitivity mrad·s/m | −0.026 ± 0.034 (10) | −0.013 ± 0.691 (10) | ≠ model |
| Tg[0,2] g-sensitivity mrad·s/m | −0.061 ± 0.081 (10) | −0.251 ± 1.086 (10) | ≠ model |
| Tg[1,0] g-sensitivity mrad·s/m | −0.024 ± 0.069 (10) | −0.556 ± 0.390 (10) | ≠ model |
| Tg[1,1] g-sensitivity mrad·s/m | −0.024 ± 0.031 (10) | 0.182 ± 0.584 (10) | ≠ model |
| Tg[1,2] g-sensitivity mrad·s/m | 0.038 ± 0.052 (10) | −0.144 ± 1.024 (10) | ≠ model |
| Tg[2,0] g-sensitivity mrad·s/m | −0.042 ± 0.086 (10) | 0.140 ± 0.334 (10) | ≠ model |
| Tg[2,1] g-sensitivity mrad·s/m | 0.009 ± 0.031 (10) | 0.188 ± 0.251 (10) | ≠ model |
| Tg[2,2] g-sensitivity mrad·s/m | −0.012 ± 0.061 (10) | 1.292 ± 0.607 (10) | ≠ model |
| time delay td to base IMU‡ ms | −1.612 ± 0.209 (10) | −1.680 ± 0.170 (10) | +0.068 |
| distance to base IMU ‖p‖ mm | 94.70 ± 0.19 (10) | 93.58 ± 0.86 (10) | ◆ +1.12 |
| t_ga gyro−accel ms | 0.081 ± 0.066 (10) | not in model |
aux IMU – t265 IMU · 21 rows · ◆ 3
| Parameter | MVISKalibr IMU model | Kalibr | MVIS− Kalibr |
|---|---|---|---|
| gyro Dw[0,0] scale x | 0.99736 ± 0.00139 (10) | 0.99908 ± 0.00344 (10) | −0.00172 |
| gyro Dw[1,1] scale y | 1.00472 ± 0.00203 (10) | 1.00911 ± 0.00276 (10) | ◆ −0.00439 |
| gyro Dw[2,2] scale z | 1.00288 ± 0.00057 (10) | 1.00142 ± 0.00208 (10) | +0.00146 |
| gyro Dw[1,0] cross | 0.00242 ± 0.00163 (10) | 0.00617 ± 0.00408 (10) | −0.00376 |
| gyro Dw[2,0] cross | 0.00296 ± 0.00065 (10) | 0.00080 ± 0.00264 (10) | +0.00216 |
| gyro Dw[2,1] cross | −0.00170 ± 0.00141 (10) | −0.01204 ± 0.00351 (10) | ◆ +0.01034 |
| accel Da[0,0] scale x | 1.01987 ± 0.00053 (10) | 1.01601 ± 0.00611 (10) | +0.00386 |
| accel Da[1,1] scale y | 1.01927 ± 0.00160 (10) | 1.01475 ± 0.00544 (10) | +0.00452 |
| accel Da[2,2] scale z | 1.01301 ± 0.00200 (10) | 1.00913 ± 0.00206 (10) | ◆ +0.00388 |
| Tg[0,0] g-sensitivity mrad·s/m | 0.006 ± 0.042 (10) | 1.183 ± 0.753 (10) | ≠ model |
| Tg[0,1] g-sensitivity mrad·s/m | 0.020 ± 0.067 (10) | 5.084 ± 1.362 (10) | ≠ model |
| Tg[0,2] g-sensitivity mrad·s/m | −0.018 ± 0.096 (10) | 0.238 ± 0.726 (10) | ≠ model |
| Tg[1,0] g-sensitivity mrad·s/m | 0.000 ± 0.040 (10) | −0.908 ± 0.691 (10) | ≠ model |
| Tg[1,1] g-sensitivity mrad·s/m | −0.030 ± 0.050 (10) | 0.003 ± 0.318 (10) | ≠ model |
| Tg[1,2] g-sensitivity mrad·s/m | −0.068 ± 0.080 (10) | 1.923 ± 0.432 (10) | ≠ model |
| Tg[2,0] g-sensitivity mrad·s/m | 0.043 ± 0.035 (10) | −1.374 ± 1.098 (10) | ≠ model |
| Tg[2,1] g-sensitivity mrad·s/m | −0.031 ± 0.091 (10) | −6.191 ± 1.532 (10) | ≠ model |
| Tg[2,2] g-sensitivity mrad·s/m | 0.026 ± 0.054 (10) | 0.110 ± 0.803 (10) | ≠ model |
| time delay td to base IMU‡ ms | 2.830 ± 0.212 (10) | 2.753 ± 0.188 (10) | +0.077 |
| distance to base IMU ‖p‖ mm | 125.15 ± 0.19 (10) | 124.41 ± 1.42 (10) | +0.74 |
| t_ga gyro−accel ms | −6.564 ± 0.054 (10) | not in model |
MVIS default IMU model (calyx) · 41 of 117 rows, model-independent only · ◆ 6
| Parameter | MVISKalibr IMU model | MVIS default | Kalibr | default− Kalibr | default− Kalibr IMU model |
|---|---|---|---|---|---|
| cam0 – Blackfly | |||||
| fx px | 448.30 ± 0.61 (10) | 448.30 ± 0.61 (10) | fixed 446.75 ± 2.17 (10) | 0.00 | |
| fy px | 447.62 ± 0.58 (10) | 447.63 ± 0.58 (10) | fixed 444.89 ± 2.50 (10) | +0.02 | |
| cx px | 370.78 ± 0.71 (10) | 370.78 ± 0.72 (10) | fixed 368.67 ± 3.28 (10) | 0.00 | |
| cy px | 281.31 ± 0.69 (10) | 281.31 ± 0.69 (10) | fixed 278.41 ± 1.44 (10) | 0.00 | |
| dist k1 | −0.31178 ± 0.00310 (10) | −0.31177 ± 0.00309 (10) | fixed −0.30796 ± 0.00996 (10) | +0.00001 | |
| dist k2 | 0.08088 ± 0.00268 (10) | 0.08088 ± 0.00267 (10) | fixed 0.07731 ± 0.00889 (10) | 0.00000 | |
| dist p1 | −0.00033 ± 0.00010 (10) | −0.00033 ± 0.00010 (10) | fixed 0.00011 ± 0.00038 (10) | 0.00000 | |
| dist p2 | −0.00012 ± 0.00013 (10) | −0.00012 ± 0.00013 (10) | fixed 0.00014 ± 0.00095 (10) | 0.00000 | |
| time offset td to base IMU‡ ms | −4.293 ± 0.093 (10) | −4.279 ± 0.096 (10) | −5.438 ± 0.149 (10) | ◆ +1.158 | +0.014 |
| distance to base IMU ‖p‖ mm | 89.32 ± 1.41 (10) | 89.35 ± 1.41 (10) | 91.41 ± 3.64 (10) | −2.06 | +0.03 |
| reproj median px | 0.349 ± 0.032 (10) | 0.349 ± 0.032 (10) | 0.483 ± 0.209 (10) | fit | fit |
| cam1 – t265 fisheye 1 | |||||
| fx px | 287.08 ± 0.36 (10) | 287.09 ± 0.36 (10) | fixed 285.72 ± 1.61 (10) | +0.01 | |
| fy px | 286.70 ± 0.34 (10) | 286.70 ± 0.34 (10) | fixed 285.13 ± 1.69 (10) | +0.01 | |
| cx px | 415.32 ± 0.27 (10) | 415.33 ± 0.27 (10) | fixed 415.83 ± 0.55 (10) | +0.01 | |
| cy px | 403.53 ± 0.25 (10) | 403.53 ± 0.26 (10) | fixed 404.09 ± 1.09 (10) | −0.01 | |
| dist k1 | −0.00341 ± 0.00286 (10) | −0.00340 ± 0.00284 (10) | fixed 0.00165 ± 0.01882 (10) | +0.00001 | |
| dist k2 | 0.03197 ± 0.00592 (10) | 0.03209 ± 0.00589 (10) | fixed 0.02307 ± 0.04201 (10) | +0.00012 | |
| dist k3 | −0.03046 ± 0.00596 (10) | −0.03059 ± 0.00591 (10) | fixed −0.02549 ± 0.03728 (10) | −0.00013 | |
| dist k4 | 0.00456 ± 0.00208 (10) | 0.00457 ± 0.00206 (10) | fixed 0.00321 ± 0.01100 (10) | +0.00001 | |
| baseline to Blackfly mm | 71.267 ± 0.140 (10) | 71.268 ± 0.139 (10) | fixed 71.856 ± 1.457 (10) | +0.001 | |
| time offset td to base IMU‡ ms | −5.022 ± 0.149 (10) | −5.014 ± 0.155 (10) | −5.999 ± 0.247 (10) | ◆ +0.984 | +0.008 |
| distance to base IMU ‖p‖ mm | 130.10 ± 1.48 (10) | 130.13 ± 1.48 (10) | 133.92 ± 3.19 (10) | ◆ −3.79 | +0.03 |
| reproj median px | 0.225 ± 0.013 (10) | 0.225 ± 0.013 (10) | 0.272 ± 0.126 (10) | fit | fit |
| cam2 – t265 fisheye 2 | |||||
| fx px | 287.02 ± 0.33 (10) | 287.02 ± 0.33 (10) | fixed 285.37 ± 1.99 (10) | 0.00 | |
| fy px | 286.40 ± 0.32 (10) | 286.41 ± 0.32 (10) | fixed 284.57 ± 2.08 (10) | +0.01 | |
| cx px | 414.56 ± 0.32 (10) | 414.57 ± 0.32 (10) | fixed 415.44 ± 0.59 (10) | 0.00 | |
| cy px | 397.96 ± 0.28 (10) | 397.96 ± 0.28 (10) | fixed 398.62 ± 1.01 (10) | 0.00 | |
| dist k1 | −0.00397 ± 0.00264 (10) | −0.00397 ± 0.00264 (10) | fixed 0.00218 ± 0.03237 (10) | 0.00000 | |
| dist k2 | 0.03443 ± 0.00611 (10) | 0.03443 ± 0.00610 (10) | fixed 0.02374 ± 0.07849 (10) | 0.00000 | |
| dist k3 | −0.03139 ± 0.00675 (10) | −0.03146 ± 0.00673 (10) | fixed −0.02631 ± 0.07301 (10) | −0.00007 | |
| dist k4 | 0.00430 ± 0.00258 (10) | 0.00431 ± 0.00257 (10) | fixed 0.00280 ± 0.02243 (10) | +0.00001 | |
| baseline to Blackfly mm | 69.849 ± 0.327 (10) | 69.849 ± 0.328 (10) | fixed 71.630 ± 2.455 (10) | 0.000 | |
| time offset td to base IMU‡ ms | −7.798 ± 0.237 (10) | −7.791 ± 0.237 (10) | −8.778 ± 0.244 (10) | ◆ +0.987 | +0.007 |
| distance to base IMU ‖p‖ mm | 111.39 ± 1.72 (10) | 111.45 ± 1.70 (10) | 114.03 ± 3.99 (10) | −2.58 | +0.06 |
| reproj median px | 0.239 ± 0.014 (10) | 0.239 ± 0.015 (10) | 0.288 ± 0.140 (10) | fit | fit |
| aux IMU – GX3-25 | |||||
| time delay td to base IMU‡ ms | −0.032 ± 0.209 (10) | −0.022 ± 0.208 (10) | −0.133 ± 0.189 (10) | +0.111 | +0.011 |
| distance to base IMU ‖p‖ mm | 131.31 ± 0.20 (10) | 131.31 ± 0.20 (10) | 129.26 ± 0.88 (10) | ◆ +2.05 | 0.00 |
| aux IMU – GX3-35 | |||||
| time delay td to base IMU‡ ms | −1.612 ± 0.209 (10) | −1.602 ± 0.209 (10) | −1.680 ± 0.170 (10) | +0.078 | +0.010 |
| distance to base IMU ‖p‖ mm | 94.70 ± 0.19 (10) | 94.70 ± 0.19 (10) | 93.58 ± 0.86 (10) | ◆ +1.12 | 0.00 |
| aux IMU – t265 IMU | |||||
| time delay td to base IMU‡ ms | 2.830 ± 0.212 (10) | 2.832 ± 0.212 (10) | 2.753 ± 0.188 (10) | +0.079 | +0.002 |
| distance to base IMU ‖p‖ mm | 125.15 ± 0.19 (10) | 125.16 ± 0.19 (10) | 124.41 ± 1.42 (10) | +0.75 | +0.01 |