
- Cameras
- 2 × 1280×720 in the recordingDataset
- Shutter
- RollingMaker ↗︎
- Field of view
- Calibrated ~102° × 69°Measured
110° × 70°Maker ↗︎ - Baseline
- 120.1 mmMeasured
- IMU
- 6-axis, 400 HzMaker ↗︎
- Output
- USB 3.0; ROS bag in the datasetMaker ↗︎
Values measured in the WHUVID calibration recording · Maker values from the Stereolabs ZED 2 page, read 2026-11-17 · ~ marks a value read past where the board corners reached. Past the fit: the edge lies beyond where the lens fit holds, so we give no value.
Demo and values
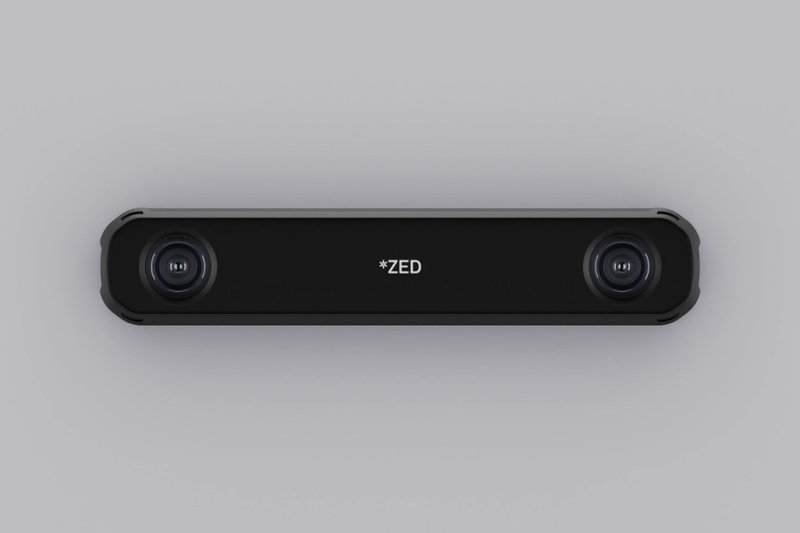
Section titled “Demo and values”Stereo depth camera from Stereolabs with two rolling-shutter cameras 120 mm apart, wide 2.1 mm lenses and a built-in IMU at 400 Hz. This is the camera of the WHUVID driving dataset from Wuhan University; both cameras and the IMU are solved together from the authors' own calibration recording, with the rolling-shutter readout estimated.
Reprojection is how far, in pixels, the detected corners lie from where the solve puts them. td is the camera–IMU time offset, and the lever arm is the camera–IMU position offset.
No independent reference. The authors publish a Kalibr calibration from the same recording with a global-shutter camera model; it isn't an independent check.
Calibration process
Section titled “Calibration process”The path of the rig around the board, as MVIS solved it. To explore it:
- Press Play or drag the bar to follow the path.
- Use the view buttons to change the view.
- Pick a camera card to put that camera on the frustum, the pyramid that shows its view.
Each card draws the board from the solved pose, with the corners MVIS detected. We publish no camera images.
Solved rig
Section titled “Solved rig”The solved rig in 3D, to scale. Tap a sensor to see its values. In full screen you can rotate and zoom. Grid squares are 20 mm.
To scale, from above and the front
| Camera | Lever x, y, z (mm) | Distance (mm) | log(R) (rad) | td (ms) | Field of view |
|---|---|---|---|---|---|
| cam0 | −0.2, −24.1, −21.3 | 32.2 | [+2.202, +2.211, −0.042] | −2.49 | ~102° × 69° |
| cam1 | −0.4, +96.0, −23.3 | 98.8 | [+2.201, +2.208, −0.036] | −2.46 | ~102° × 69° |
Solved by MVIS. Lever arms (camera–IMU position offsets) are in the IMU frame. Rotation is log(R), camera in the IMU frame.
Specifications
Section titled “Specifications”| Published by the maker | |
|---|---|
| Maker | Stereolabs |
| Image sensors | 2 × 4 MP 1/3-inch back-illuminated CMOS, 2 µm pixels |
| Shutter | Rolling, the two cameras synchronised; readout 14.1 ms (left) and 14.0 ms (right) solved here |
| Lenses | 2.1 mm, 110° × 70° (120° diagonal) |
| Baseline | 120 mm |
| Video modes | Up to 2208×1242 at 15 fps; 1280×720 at 60, 30 or 15 fps |
| Measured in these recordings | |
| Images in the recording | 2 × 1280×720 grey at 19.7 Hz (the dataset states 30 fps) |
| IMU | 6-axis, 400 Hz on the sheet; 381 Hz in the recording |
| Calibrated field of view | cam0 ~102° × 69° · cam1 ~102° × 69° |
| From the dataset | |
| Model | The dataset names a ZED2. The original ZED 2 rather than the later ZED 2i is inferred from the recording date (December 2020) and the solved focal length |
Dataset
Section titled “Dataset”| Recordings | 1 camera + IMU recording, 74 s, hand-held in front of the board. 1,457 frames per camera, 29,410 IMU samples |
| Source | WHUVID dataset (Wuhan University), calibration recording published by the authors |
| Format | ROS 1 bag. Two IMU samples repeat the one before (same time and values) and are dropped |
| Board | AprilGrid 6×6, tag 20.8 mm, spacing 0.3 |
| Data | Calibench community, zed2/data/ (access by automatic approval). The authors' calibration bag, unchanged (myCalibrate.bag, 2.7 GB), with a script that drops the two repeated IMU samples. Recorded by the WHUVID authors; the dataset states no licence, so ask them before reuse |
| Configs and results | Calibench community, zed2/ (access by automatic approval) |
Detailed results
Section titled “Detailed results”Lens Calibrated field of view
Calibrated field of view, horizontal × vertical. cam0: ~102° × 69°, corners reach 49° from the axis · cam1: ~102° × 69°, corners reach 49° from the axis
cam0 cam1
We read these from the calibrated lens fit at the image edges, through the principal point (where the optical axis meets the image). ~ marks an axis past where the corners reached, so the fit is extrapolated there. Past the fit means an edge lies beyond where the fit holds, so we give no value.
IMU Gyro–accel time offset t_ga +3.13 ms
Each bar shows a scale as its deviation from 1. IMU model: calyx. t_ga, the time offset between the gyroscope and accelerometer channels: +3.13 ± 0.37 ms.
Timing cam0 td, first row −2.49 ms
The time offsets, to scale. td is the camera–IMU time offset, with t_imu = t_cam + td. For a rolling-shutter camera td is the time of the first image row; the middle row is td + readout / 2, which is what a global-shutter calibration reports.
Full results Every solved parameter
Rotation is log(R) in rad, camera in the IMU frame.
| Parameter | MVIS |
|---|---|
| cam0 | |
| fx px | 532.54 |
| fy px | 534.37 |
| cx px | 636.86 |
| cy px | 361.39 |
| k1 | −0.07103 |
| k2 | 0.03219 |
| k3 | −0.00034 |
| k4 | −0.00557 |
| Lever x mm | −0.16 |
| Lever y mm | −24.11 |
| Lever z mm | −21.27 |
| log(R) rad | [+2.2024, +2.2114, −0.0420] |
| td ms | −2.486 |
| Reprojection px | 0.474 |
| Readout ms | +14.06 |
| cam1 | |
| fx px | 532.75 |
| fy px | 536.02 |
| cx px | 654.60 |
| cy px | 340.71 |
| k1 | −0.07322 |
| k2 | 0.03995 |
| k3 | −0.00006 |
| k4 | −0.00525 |
| Lever x mm | −0.38 |
| Lever y mm | +96.02 |
| Lever z mm | −23.34 |
| log(R) rad | [+2.2011, +2.2085, −0.0358] |
| td ms | −2.459 |
| Reprojection px | 0.475 |
| Readout ms | +14.01 |
| IMU | |
| t_ga ms | +3.13 ± 0.37 |
Limits
Section titled “Limits”- No independent reference. The authors publish a Kalibr calibration from the same recording with a global-shutter camera model; it isn't an independent check.
- The time offset is given at the first image row. At mid-image, the time a global-shutter model reports, it is about 7 ms later (+4.5 ms).
- The board is small (about 15 cm), so the image edges are covered less well and the principal point trades with the lens distortion: a Kannala–Brandt model moves it by about 10 px with no change in fit.
- The recording runs at 19.7 Hz and the IMU at 381 Hz, below the 30 fps and 400 Hz on the sheet, probably from drops while recording.
How it was run
Section titled “How it was run”- Both cameras and the IMU together. Camera intrinsics (pinhole with radial-tangential distortion, as in the authors' calibration) start from a camera-only solve and stay free; rolling-shutter readout, camera time offsets, IMU scale and misalignment and the gyro-to-accel offset t_ga are estimated. IMU noise from the authors' IMU file. Solved 2026-11-16.