
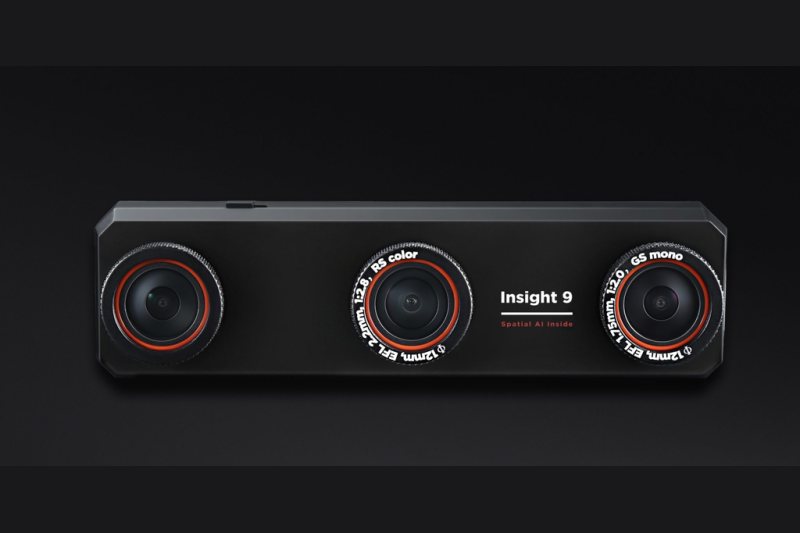
Looper Insight 9
Repeatability, not accuracy. There is no ground truth: a small spread shows that a tool repeats, not that it is right, and a difference shows that two tools disagree, not which one is wrong. The MVIS authors made every run, including Kalibr and Basalt.
Repeatability
Section titled “Repeatability”| Family | Focal + pp px | Distortion | Distance mm | Readout ms | Time offset ms | Cam–IMU distance mm | Gyro | Accel |
|---|---|---|---|---|---|---|---|---|
| T4 · camera n = 10 matched Camera stereo | Kalibr ×1.4 | Tie a | Tie | — | — | — | — | — |
| T11 · cam+IMU n = 10 matched 3-cam + IMU | MVIS ×1.8 | Tie a | Tie | MVIS only | Not separated b | Tie | Tie c | Tie c |
T4 · camera · Camera stereo More repeatable or tie: Focal + pp Kalibr · Distortion tie · Distance tie n = 10 matched · MVIS 10 of 10 · Kalibr 10 of 10 · Basalt 10 of 10
T11 · cam+IMU · 3-cam + IMU More repeatable or tie: Focal + pp MVIS · Distortion tie · Distance tie · Time offset not separated · Cam–IMU distance tie · Gyro tie · Accel tie n = 10 matched · MVIS 10 of 10 · Kalibr 10 of 10 · Basalt 10 of 10
MVIS Kalibr Basalt tool ×k more repeatable: the other tools' typical scatter is k times larger Tie gap within chance or under 20 % too few under 6 shared recordings input no comparison, reason in the cell
k = the looser tool's typical scatter divided by the tighter tool's (median over the group's parameters, on the recordings every compared tool ran). Click a cell for its numbers.
- a Coefficients trade off against each other, so their scatter can overstate differences in the lens mapping.
- b MVIS also fits a gyro–accel delay (t_ga) that Kalibr and Basalt do not, so its td is not quite the same quantity.
- c MVIS here uses Kalibr's IMU model, so the gyro and accel terms mean the same thing in both tools.
Each cell is a separate comparison on the recordings every compared tool ran. Cells are not added up and nothing is ordered across datasets.
Not part of this comparison
- T11 reprojection error (2 rows): fit quality, not repeatability and not accuracy
- T11 focal length + principal point of Looper RS cam2 (4 rows): no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- T11 distortion coefficients of Looper RS cam2 (4 rows): no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- T11 rolling-shutter readout of Looper RS cam2 (1 row): no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- T11 camera–camera distance of Looper RS cam2 (1 row): no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- T11 camera–imu time offset of Looper RS cam2 (1 row): no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- T11 camera–imu distance of Looper RS cam2 (1 row): no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- T11 reproj median of Looper RS cam2 (1 row): no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- T11 IMU g-sensitivity Tg (9 rows): Kalibr absorbs it in its IMU model
- T11 gyro–accel delay t_ga (1 row): MVIS only
Focal length + principal point · T4 · 10 matched recordings (MVIS 10 of 10 · Kalibr 10 of 10 · Basalt 10 of 10) · Camera stereo, camera
Across the same 10 recordings, MVIS's estimates scatter about 1.7× more than Kalibr's (median over 8 parameters); Basalt's about 1.4×. A gap this large appeared in 0.59 % (MVIS) and 1.6 % (Basalt) of recording-by-recording swaps. Holds with any one recording left out.
MVIS here: its camera-only run.
| Pair | R | 95 % interval | p (Holm) | Decision | Leave one out |
|---|---|---|---|---|---|
| MVIS ÷ Kalibr · 8 param. | 1.68 | 1.24 – 2.3 | 0.018 (raw 0.0059) | Kalibr tighter | holds with any one recording left out |
| MVIS ÷ Basalt · 8 param. | 1.04 | 0.85 – 1.22 | 0.56 | tie: gap within chance | |
| Kalibr ÷ Basalt · 8 param. | 0.71 | 0.58 – 0.92 | 0.031 (raw 0.016) | Kalibr tighter | holds with any one recording left out |
The 95 % interval of MVIS ÷ Kalibr reaches into the tie band (0.80–1.25): the ratio shown is a point value.
The 95 % interval of Kalibr ÷ Basalt reaches into the tie band (0.80–1.25): the ratio shown is a point value.
| Parameter | MVIS sd | Kalibr sd | Basalt sd |
|---|---|---|---|
| Looper GS cam0 · fx px | 0.379 | 0.187 | 0.383 |
| Looper GS cam0 · fy px | 0.374 | 0.186 | 0.38 |
| Looper GS cam0 · cx px | 0.106 | 0.169 | 0.109 |
| Looper GS cam0 · cy px | 0.0451 | 0.0548 | 0.0321 |
| Looper GS cam1 · fx px | 0.398 | 0.202 | 0.382 |
| Looper GS cam1 · fy px | 0.399 | 0.197 | 0.381 |
| Looper GS cam1 · cx px | 0.117 | 0.162 | 0.0915 |
| Looper GS cam1 · cy px | 0.0701 | 0.0489 | 0.0516 |
Repeatability only — a tool can repeat well and still be biased.
Distortion coefficients · T4 · 10 matched recordings (MVIS 10 of 10 · Kalibr 10 of 10 · Basalt 10 of 10) · Camera stereo, camera
The spreads of MVIS and Kalibr differ by 1.6×, but a gap this size appears often by chance with 10 recordings (p = 0.21). Treated as a tie. The spreads of MVIS and Basalt differ by 1.2×, but a gap this size appears often by chance with 10 recordings (p = 0.21). Treated as a tie. The spreads of Kalibr and Basalt differ by 1.8×, but a gap this size appears often by chance with 10 recordings (p = 0.21). Treated as a tie.
MVIS here: its camera-only run.
| Pair | R | 95 % interval | p (Holm) | Decision | Leave one out |
|---|---|---|---|---|---|
| MVIS ÷ Kalibr · 8 param. | 0.62 | 0.39 – 1.13 | 0.21 (raw 0.068) | tie: gap within chance | |
| MVIS ÷ Basalt · 8 param. | 1.22 | 0.94 – 1.52 | 0.21 (raw 0.11) | tie: gap within chance | |
| Kalibr ÷ Basalt · 8 param. | 1.77 | 0.96 – 2.62 | 0.21 (raw 0.08) | tie: gap within chance |
| Parameter | MVIS sd | Kalibr sd | Basalt sd |
|---|---|---|---|
| Looper GS cam0 · dist k1 | 0.00109 | 0.00139 | 0.000789 |
| Looper GS cam0 · dist k2 | 0.00284 | 0.00481 | 0.00156 |
| Looper GS cam0 · dist k3 | 0.00381 | 0.00588 | 0.00177 |
| Looper GS cam0 · dist k4 | 0.0017 | 0.00244 | 0.000639 |
| Looper GS cam1 · dist k1 | 0.0011 | 0.00095 | 0.00103 |
| Looper GS cam1 · dist k2 | 0.00224 | 0.00393 | 0.00226 |
| Looper GS cam1 · dist k3 | 0.00259 | 0.00515 | 0.00288 |
| Looper GS cam1 · dist k4 | 0.00103 | 0.00219 | 0.00126 |
- a Coefficients trade off against each other, so their scatter can overstate differences in the lens mapping.
Repeatability only — a tool can repeat well and still be biased.
Camera–camera distance · T4 · 10 matched recordings (MVIS 10 of 10 · Kalibr 10 of 10 · Basalt 10 of 10) · Camera stereo, camera
The spreads of MVIS and Kalibr differ by 1.4×, but a gap this size appears often by chance with 10 recordings (p = 0.72). Treated as a tie. The spreads of MVIS and Basalt differ by 1.04×, but a gap this size appears often by chance with 10 recordings (p = 0.79). Treated as a tie. The spreads of Kalibr and Basalt differ by 1.3×, but a gap this size appears often by chance with 10 recordings (p = 0.72). Treated as a tie.
MVIS here: its camera-only run.
| Pair | R | 95 % interval | p (Holm) | Decision | Leave one out |
|---|---|---|---|---|---|
| MVIS ÷ Kalibr · 1 param. | 0.74 | 0.56 – 1.31 | 0.72 (raw 0.24) | tie: gap within chance | |
| MVIS ÷ Basalt · 1 param. | 0.96 | 0.72 – 1.57 | 0.79 | tie: gap within chance | |
| Kalibr ÷ Basalt · 1 param. | 1.3 | 0.8 – 1.72 | 0.72 (raw 0.32) | tie: gap within chance |
| Parameter | MVIS sd | Kalibr sd | Basalt sd |
|---|---|---|---|
| Looper GS cam1 · baseline to Looper GS cam0 mm | 0.176 | 0.238 | 0.183 |
Repeatability only — a tool can repeat well and still be biased.
Focal length + principal point · T11 · 10 matched recordings (MVIS 10 of 10 · Kalibr input · Basalt 10 of 10) · 3-cam + IMU, cam+IMU
Across the same 10 recordings, Basalt's estimates scatter about 1.8× more than MVIS's (median over 8 parameters). A gap this large appeared in 4.9 % of recording-by-recording swaps. Holds with any one recording left out.
MVIS here: its default IMU model.
| Pair | R | 95 % interval | p (Holm) | Decision | Leave one out |
|---|---|---|---|---|---|
| MVIS ÷ Basalt · 8 param. | 0.57 | 0.34 – 0.98 | 0.049 | MVIS tighter | holds with any one recording left out |
The 95 % interval of MVIS ÷ Basalt reaches into the tie band (0.80–1.25): the ratio shown is a point value.
| Parameter | MVIS sd | Basalt sd | Ratio |
|---|---|---|---|
| Looper GS cam0 · fx px | 0.155 | 0.44 | 0.35 |
| Looper GS cam0 · fy px | 0.164 | 0.435 | 0.38 |
| Looper GS cam0 · cx px | 0.132 | 0.154 | 0.86 |
| Looper GS cam0 · cy px | 0.065 | 0.0408 | 1.59 |
| Looper GS cam1 · fx px | 0.121 | 0.449 | 0.27 |
| Looper GS cam1 · fy px | 0.13 | 0.443 | 0.29 |
| Looper GS cam1 · cx px | 0.119 | 0.0931 | 1.28 |
| Looper GS cam1 · cy px | 0.0818 | 0.0562 | 1.46 |
- Kalibr · input, not compared · 8 rows: Kalibr's camera+IMU run starts from these values, exported from MVIS for each recording, and keeps them fixed. Their spread copies the input, so it is not Kalibr's repeatability.
- MVIS · only this tool · 4 rows: no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- Kalibr · missing · 4 rows: no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- Basalt · missing · 4 rows: no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
Repeatability only — a tool can repeat well and still be biased.
Distortion coefficients · T11 · 10 matched recordings (MVIS 10 of 10 · Kalibr input · Basalt 10 of 10) · 3-cam + IMU, cam+IMU
The spreads of MVIS and Basalt differ by 1.3×, but a gap this size appears often by chance with 10 recordings (p = 0.17). Treated as a tie.
MVIS here: its default IMU model.
| Pair | R | 95 % interval | p (Holm) | Decision | Leave one out |
|---|---|---|---|---|---|
| MVIS ÷ Basalt · 8 param. | 1.3 | 0.86 – 1.75 | 0.17 | tie: gap within chance |
| Parameter | MVIS sd | Basalt sd | Ratio |
|---|---|---|---|
| Looper GS cam0 · dist k1 | 0.00123 | 0.0012 | 1.03 |
| Looper GS cam0 · dist k2 | 0.00408 | 0.00243 | 1.68 |
| Looper GS cam0 · dist k3 | 0.00483 | 0.00284 | 1.70 |
| Looper GS cam0 · dist k4 | 0.00187 | 0.00111 | 1.68 |
| Looper GS cam1 · dist k1 | 0.000887 | 0.00137 | 0.65 |
| Looper GS cam1 · dist k2 | 0.00328 | 0.00265 | 1.24 |
| Looper GS cam1 · dist k3 | 0.00426 | 0.00328 | 1.30 |
| Looper GS cam1 · dist k4 | 0.00174 | 0.00133 | 1.31 |
- Kalibr · input, not compared · 8 rows: Kalibr's camera+IMU run starts from these values, exported from MVIS for each recording, and keeps them fixed. Their spread copies the input, so it is not Kalibr's repeatability.
- MVIS · only this tool · 4 rows: no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- Kalibr · missing · 4 rows: no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- Basalt · missing · 4 rows: no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- a Coefficients trade off against each other, so their scatter can overstate differences in the lens mapping.
Repeatability only — a tool can repeat well and still be biased.
Camera–camera distance · T11 · 10 matched recordings (MVIS 10 of 10 · Kalibr input · Basalt 10 of 10) · 3-cam + IMU, cam+IMU
The spreads of MVIS and Basalt differ by 1.1×, but a gap this size appears often by chance with 10 recordings (p = 0.38). Treated as a tie.
MVIS here: its default IMU model.
| Pair | R | 95 % interval | p (Holm) | Decision | Leave one out |
|---|---|---|---|---|---|
| MVIS ÷ Basalt · 1 param. | 1.11 | 0.9 – 1.39 | 0.38 | tie: gap within chance |
| Parameter | MVIS sd | Basalt sd | Ratio |
|---|---|---|---|
| Looper GS cam1 · baseline to Looper GS cam0 mm | 0.211 | 0.191 | 1.10 |
- Kalibr · input, not compared · 1 row: Kalibr's camera+IMU run starts from these values, exported from MVIS for each recording, and keeps them fixed. Their spread copies the input, so it is not Kalibr's repeatability.
- MVIS · only this tool · 1 row: no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- Kalibr · missing · 1 row: no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- Basalt · missing · 1 row: no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
Repeatability only — a tool can repeat well and still be biased.
Rolling-shutter readout · T11 · MVIS only (MVIS only · Kalibr no value · Basalt no value) · 3-cam + IMU, cam+IMU
MVIS only: no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- MVIS · only this tool · 1 row: no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- Kalibr · missing · 1 row: no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- Basalt · missing · 1 row: no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
Repeatability only — a tool can repeat well and still be biased.
Camera–IMU time offset · T11 · 10 matched recordings (MVIS 10 of 10 · Kalibr 10 of 10 · Basalt 10 of 10) · 3-cam + IMU, cam+IMU
MVIS is tighter than Basalt; the other pairs are not separated. No single tool is marked.
MVIS here: its default IMU model.
| Pair | R | 95 % interval | p (Holm) | Decision | Leave one out |
|---|---|---|---|---|---|
| MVIS ÷ Kalibr · 2 param. | 0.59 | 0.36 – 1.19 | 0.22 (raw 0.11) | tie: gap within chance | |
| MVIS ÷ Basalt · 2 param. | 0.5 | 0.34 – 0.65 | 0.012 (raw 0.0039) | MVIS tighter | holds with any one recording left out |
| Kalibr ÷ Basalt · 2 param. | 0.85 | 0.43 – 1.28 | 0.43 | tie: gap within chance |
| Parameter | MVIS sd | Kalibr sd | Basalt sd |
|---|---|---|---|
| Looper GS cam0 · time offset td to base IMU ms | 0.0767 | 0.131 | 0.156 |
| Looper GS cam1 · time offset td to base IMU ms | 0.0801 | 0.135 | 0.156 |
- MVIS · only this tool · 1 row: no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- Kalibr · missing · 1 row: no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- Basalt · missing · 1 row: no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- b MVIS also fits a gyro–accel delay (t_ga) that Kalibr and Basalt do not, so its td is not quite the same quantity.
Repeatability only — a tool can repeat well and still be biased.
Camera–IMU distance · T11 · 10 matched recordings (MVIS 10 of 10 · Kalibr 10 of 10 · Basalt 10 of 10) · 3-cam + IMU, cam+IMU
The spreads of MVIS and Kalibr differ by 1.1×, but a gap this size appears often by chance with 10 recordings (p = 1). Treated as a tie. The spreads of MVIS and Basalt differ by 1.2×, but a gap this size appears often by chance with 10 recordings (p = 1). Treated as a tie. The spreads of Kalibr and Basalt differ by 1.03×, but a gap this size appears often by chance with 10 recordings (p = 1). Treated as a tie.
MVIS here: its default IMU model.
| Pair | R | 95 % interval | p (Holm) | Decision | Leave one out |
|---|---|---|---|---|---|
| MVIS ÷ Kalibr · 2 param. | 0.9 | 0.67 – 1.24 | 1 (raw 0.39) | tie: gap within chance | |
| MVIS ÷ Basalt · 2 param. | 0.87 | 0.56 – 1.28 | 1 (raw 0.47) | tie: gap within chance | |
| Kalibr ÷ Basalt · 2 param. | 0.97 | 0.59 – 1.57 | 1 (raw 0.87) | tie: gap within chance |
| Parameter | MVIS sd | Kalibr sd | Basalt sd |
|---|---|---|---|
| Looper GS cam0 · distance to base IMU ‖p‖ mm | 0.375 | 0.512 | 0.564 |
| Looper GS cam1 · distance to base IMU ‖p‖ mm | 0.375 | 0.341 | 0.329 |
- MVIS · only this tool · 1 row: no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- Kalibr · missing · 1 row: no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
- Basalt · missing · 1 row: no Kalibr rolling-shutter run; Basalt has no rolling-shutter model
Repeatability only — a tool can repeat well and still be biased.
Gyro scale + cross-axis · T11 · 10 matched recordings (MVIS 10 of 10 · Kalibr 10 of 10 · Basalt 10 of 10) · 3-cam + IMU, cam+IMU
The spreads of MVIS and Kalibr differ by 1.2×, but a gap this size appears often by chance with 10 recordings (p = 0.28). Treated as a tie. The spreads of MVIS and Basalt differ by 1.4×, but a gap this size appears often by chance with 10 recordings (p = 0.14). Treated as a tie. The spreads of Kalibr and Basalt differ by 1.4×, but a gap this size appears often by chance with 10 recordings (p = 0.28). Treated as a tie.
MVIS here: its run with Kalibr's IMU model (K-IMU).
| Pair | R | 95 % interval | p (Holm) | Decision | Leave one out |
|---|---|---|---|---|---|
| MVIS ÷ Kalibr · 6 param. | 1.15 | 0.94 – 1.64 | 0.28 (raw 0.17) | tie: gap within chance | |
| MVIS ÷ Basalt · 6 param. | 0.73 | 0.5 – 1 | 0.14 (raw 0.047) | tie: gap within chance | |
| Kalibr ÷ Basalt · 6 param. | 0.73 | 0.41 – 1.17 | 0.28 (raw 0.14) | tie: gap within chance |
| Parameter | MVIS sd | Kalibr sd | Basalt sd |
|---|---|---|---|
| Looper MEMS imu0 · gyro Dw[0,0] scale x | 0.000875 | 0.00131 | 0.00144 |
| Looper MEMS imu0 · gyro Dw[1,1] scale y | 0.000964 | 0.000679 | 0.00131 |
| Looper MEMS imu0 · gyro Dw[2,2] scale z | 0.000329 | 0.000342 | 0.000454 |
| Looper MEMS imu0 · gyro Dw[1,0] cross | 0.00122 | 0.00103 | 0.000703 |
| Looper MEMS imu0 · gyro Dw[2,0] cross | 0.000459 | 0.000337 | 0.00048 |
| Looper MEMS imu0 · gyro Dw[2,1] cross | 0.000619 | 0.000549 | 0.00111 |
- c MVIS here uses Kalibr's IMU model, so the gyro and accel terms mean the same thing in both tools.
Repeatability only — a tool can repeat well and still be biased.
Accel scale · T11 · 10 matched recordings (MVIS 10 of 10 · Kalibr 10 of 10 · Basalt 10 of 10) · 3-cam + IMU, cam+IMU
The gap between MVIS and Kalibr is clear but under 20 % (1.2×), so it is treated as a tie. The spreads of MVIS and Basalt differ by 1.2×, but a gap this size appears often by chance with 10 recordings (p = 0.7). Treated as a tie. The spreads of Kalibr and Basalt differ by 1.01×, but a gap this size appears often by chance with 10 recordings (p = 0.92). Treated as a tie.
MVIS here: its run with Kalibr's IMU model (K-IMU).
| Pair | R | 95 % interval | p (Holm) | Decision | Leave one out |
|---|---|---|---|---|---|
| MVIS ÷ Kalibr · 3 param. | 0.82 | 0.62 – 0.95 | 0.029 (raw 0.0098) | tie: gap under 20 % | |
| MVIS ÷ Basalt · 3 param. | 0.81 | 0.6 – 1.4 | 0.7 (raw 0.35) | tie: gap within chance | |
| Kalibr ÷ Basalt · 3 param. | 1.01 | 0.78 – 1.93 | 0.92 | tie: gap within chance |
| Parameter | MVIS sd | Kalibr sd | Basalt sd |
|---|---|---|---|
| Looper MEMS imu0 · accel Da[0,0] scale x | 0.000395 | 0.000286 | 0.000485 |
| Looper MEMS imu0 · accel Da[1,1] scale y | 0.000281 | 0.000502 | 0.000495 |
| Looper MEMS imu0 · accel Da[2,2] scale z | 0.00159 | 0.00195 | 0.00179 |
- c MVIS here uses Kalibr's IMU model, so the gyro and accel terms mean the same thing in both tools.
Repeatability only — a tool can repeat well and still be biased.
T4 · camera only
Section titled “T4 · camera only”Camera stereo · 10 recordings
Repeatability Focal + ppDistortionDistanceReadoutTime offsetCam–IMU distanceGyroAccel
Coverage
Section titled “Coverage”- MVIS 10 of 10
- Kalibr 10 of 10
- Basalt 10 of 10
Records behind these numbers: MVIS T4.json · Kalibr T4.json · Basalt T4.json
Where the tools differ
Section titled “Where the tools differ”MVIS − Kalibr ◆ 6 of 17 compared rows
- Looper GS cam0 · fx +0.60 px ◆
- Looper GS cam0 · fy +0.63 px ◆
- Looper GS cam0 · cx +0.06 px
- Looper GS cam0 · cy +0.02 px
- Looper GS cam0 · dist k1 −0.00189 ◆
- Looper GS cam0 · dist k2 −0.00026
- Looper GS cam0 · dist k3 +0.00344
- Looper GS cam0 · dist k4 −0.00200
- Looper GS cam1 · fx +0.53 px ◆
- Looper GS cam1 · fy +0.54 px ◆
- Looper GS cam1 · cx −0.13 px
- Looper GS cam1 · cy +0.01 px
- Looper GS cam1 · dist k1 −0.00243 ◆
- Looper GS cam1 · dist k2 +0.00213
- Looper GS cam1 · dist k3 +0.00022
- Looper GS cam1 · dist k4 −0.00097
- Looper GS cam1 · baseline to Looper GS cam0 −0.059 mm
Basalt − Kalibr ◆ 3 of 17 compared rows
- Looper GS cam0 · fx +0.33 px
- Looper GS cam0 · fy +0.35 px
- Looper GS cam0 · cx +0.09 px
- Looper GS cam0 · cy −0.01 px
- Looper GS cam0 · dist k1 −0.00156 ◆
- Looper GS cam0 · dist k2 +0.00205
- Looper GS cam0 · dist k3 +0.00010
- Looper GS cam0 · dist k4 −0.00088
- Looper GS cam1 · fx +0.32 px
- Looper GS cam1 · fy +0.31 px
- Looper GS cam1 · cx −0.10 px
- Looper GS cam1 · cy −0.03 px
- Looper GS cam1 · dist k1 −0.00212 ◆
- Looper GS cam1 · dist k2 +0.00399 ◆
- Looper GS cam1 · dist k3 −0.00420
- Looper GS cam1 · dist k4 +0.00154
- Looper GS cam1 · baseline to Looper GS cam0 −0.062 mm
Basalt − MVIS ◆ 2 of 17 compared rows
- Looper GS cam0 · fx −0.27 px
- Looper GS cam0 · fy −0.28 px
- Looper GS cam0 · cx +0.03 px
- Looper GS cam0 · cy −0.03 px
- Looper GS cam0 · dist k1 +0.00033
- Looper GS cam0 · dist k2 +0.00230
- Looper GS cam0 · dist k3 −0.00334
- Looper GS cam0 · dist k4 +0.00113
- Looper GS cam1 · fx −0.22 px
- Looper GS cam1 · fy −0.23 px
- Looper GS cam1 · cx +0.02 px
- Looper GS cam1 · cy −0.04 px
- Looper GS cam1 · dist k1 +0.00030
- Looper GS cam1 · dist k2 +0.00186
- Looper GS cam1 · dist k3 −0.00442 ◆
- Looper GS cam1 · dist k4 +0.00251 ◆
- Looper GS cam1 · baseline to Looper GS cam0 −0.004 mm
Dot = median difference Δ on an axis in units of the larger of the two tools' sd; shaded = ±1 sd; filled dot and ◆ = outside it; an arrow = beyond ±5 sd. No tool is the reference. "≠n" = the tools solved different recordings.
Parameters by sensor
Section titled “Parameters by sensor”2 sensors, 17 parameter charts (open to see each tool's spread)
fx px axis 335 ± 1
fy px axis 335 ± 0.98
cx px axis 272 ± 0.314
cy px axis 318 ± 0.108
dist k1 axis −0.0232 ± 0.00386
dist k2 axis 0.0116 ± 0.0088
dist k3 axis −0.0136 ± 0.0121
dist k4 axis 0.00236 ± 0.00614
fx px axis 335 ± 1
fy px axis 335 ± 1.01
cx px axis 269 ± 0.304
cy px axis 318 ± 0.134
dist k1 axis −0.0234 ± 0.00376
dist k2 axis 0.0113 ± 0.00781
dist k3 axis −0.00998 ± 0.0135
dist k4 axis 0.0015 ± 0.00559
baseline to Looper GS cam0 mm axis 99.1 ± 0.498
Whisker = lowest to highest value over the tool's solved recordings; box = median ± sd; tick = median. Min and max come from the per-recording values behind each record's median; only these two numbers are published, not the values. Rotations are not shown: the records do not hold them yet.
Model notes and how each tool was run
Section titled “Model notes and how each tool was run”1 note on models, inputs and run settings
- No charted value is an input or comes from another model.
Run configs, commands and the full parameter tables are in Full tables at the end of this page.
T11 · camera + IMU
Section titled “T11 · camera + IMU”3-cam + IMU · 10 recordings
Read first: Kalibr's intrinsics and baselines are inputs from its own camera-only calibration; its td and lever are solved given them.
Repeatability Focal + ppDistortionDistanceReadoutTime offsetCam–IMU distanceGyroKAccelK
Coverage
Section titled “Coverage”- MVIS 10 of 10
- Kalibr 10 of 10
- Basalt 10 of 10
MVIS made two runs per recording: its default IMU model ("MVIS") and Kalibr's IMU model ("MVIS (K-IMU)"), so the IMU terms of the second mean the same thing as Kalibr's.
Records behind these numbers: MVIS T11.json · Kalibr T11.json · Basalt T11.json
Fit: reprojection median, px (fit of each tool's own model, not accuracy)
| Camera | MVIS | MVIS (K-IMU) | Kalibr | Basalt |
|---|---|---|---|---|
| Looper GS cam0 | 0.154 | 0.153 | 0.195 | – |
| Looper GS cam1 | 0.162 | 0.161 | 0.209 | – |
| Looper RS cam2 | 0.434 | 0.434 | – | – |
Where the tools differ
Section titled “Where the tools differ”MVIS (K-IMU) − Kalibr ◆ 7 of 13 compared rows
- Looper GS cam0 · time offset td to base IMU +1.598 ms ◆
- Looper GS cam0 · distance to base IMU ‖p‖ −0.83 mm ◆
- Looper GS cam1 · time offset td to base IMU +1.616 ms ◆
- Looper GS cam1 · distance to base IMU ‖p‖ +0.63 mm ◆
- Looper MEMS imu0 · gyro Dw[0,0] scale x +0.00236 ◆
- Looper MEMS imu0 · gyro Dw[1,1] scale y +0.00002
- Looper MEMS imu0 · gyro Dw[2,2] scale z −0.00003
- Looper MEMS imu0 · gyro Dw[1,0] cross +0.00001
- Looper MEMS imu0 · gyro Dw[2,0] cross −0.00205 ◆
- Looper MEMS imu0 · gyro Dw[2,1] cross +0.00014
- Looper MEMS imu0 · accel Da[0,0] scale x +0.00043 ◆
- Looper MEMS imu0 · accel Da[1,1] scale y +0.00045
- Looper MEMS imu0 · accel Da[2,2] scale z −0.00084
Basalt − Kalibr ◆ 3 of 13 compared rows
- Looper GS cam0 · time offset td to base IMU +0.852 ms ◆
- Looper GS cam0 · distance to base IMU ‖p‖ +0.49 mm
- Looper GS cam1 · time offset td to base IMU +0.836 ms ◆
- Looper GS cam1 · distance to base IMU ‖p‖ −0.12 mm
- Looper MEMS imu0 · gyro Dw[0,0] scale x +0.00036
- Looper MEMS imu0 · gyro Dw[1,1] scale y −0.00003
- Looper MEMS imu0 · gyro Dw[2,2] scale z −0.00004
- Looper MEMS imu0 · gyro Dw[1,0] cross +0.00031
- Looper MEMS imu0 · gyro Dw[2,0] cross −0.00119 ◆
- Looper MEMS imu0 · gyro Dw[2,1] cross +0.00004
- Looper MEMS imu0 · accel Da[0,0] scale x −0.00011
- Looper MEMS imu0 · accel Da[1,1] scale y −0.00011
- Looper MEMS imu0 · accel Da[2,2] scale z −0.00064
Basalt − MVIS (K-IMU) ◆ 15 of 30 compared rows
- Looper GS cam0 · fx +0.31 px
- Looper GS cam0 · fy +0.26 px
- Looper GS cam0 · cx −0.23 px ◆
- Looper GS cam0 · cy −0.07 px
- Looper GS cam0 · dist k1 +0.00037
- Looper GS cam0 · dist k2 −0.00115
- Looper GS cam0 · dist k3 +0.00266
- Looper GS cam0 · dist k4 −0.00153
- Looper GS cam0 · time offset td to base IMU −0.746 ms ◆
- Looper GS cam0 · distance to base IMU ‖p‖ +1.33 mm ◆
- Looper GS cam1 · fx +0.27 px
- Looper GS cam1 · fy +0.32 px
- Looper GS cam1 · cx −0.29 px ◆
- Looper GS cam1 · cy −0.15 px ◆
- Looper GS cam1 · dist k1 +0.00144 ◆
- Looper GS cam1 · dist k2 −0.00668 ◆
- Looper GS cam1 · dist k3 +0.00642 ◆
- Looper GS cam1 · dist k4 −0.00186 ◆
- Looper GS cam1 · baseline to Looper GS cam0 −0.023 mm
- Looper GS cam1 · time offset td to base IMU −0.780 ms ◆
- Looper GS cam1 · distance to base IMU ‖p‖ −0.74 mm ◆
- Looper MEMS imu0 · gyro Dw[0,0] scale x −0.00200 ◆
- Looper MEMS imu0 · gyro Dw[1,1] scale y −0.00005
- Looper MEMS imu0 · gyro Dw[2,2] scale z −0.00001
- Looper MEMS imu0 · gyro Dw[1,0] cross +0.00030
- Looper MEMS imu0 · gyro Dw[2,0] cross +0.00086 ◆
- Looper MEMS imu0 · gyro Dw[2,1] cross −0.00010
- Looper MEMS imu0 · accel Da[0,0] scale x −0.00055 ◆
- Looper MEMS imu0 · accel Da[1,1] scale y −0.00055 ◆
- Looper MEMS imu0 · accel Da[2,2] scale z +0.00020
Dot = median difference Δ on an axis in units of the larger of the two tools' sd; shaded = ±1 sd; filled dot and ◆ = outside it; an arrow = beyond ±5 sd. No tool is the reference. "≠n" = the tools solved different recordings.
Parameters by sensor
Section titled “Parameters by sensor”4 sensors, 43 parameter charts (open to see each tool's spread)
fx px axis 334 ± 1.34
fy px axis 334 ± 1.35
cx px axis 272 ± 0.366
cy px axis 319 ± 0.146
dist k1 axis −0.0218 ± 0.00351
dist k2 axis 0.0118 ± 0.00863
dist k3 axis −0.0135 ± 0.0121
dist k4 axis 0.00285 ± 0.0056
time offset td to base IMU ms axis 0.948 ± 1.69 · line at 0
distance to base IMU ‖p‖ mm axis 44.1 ± 1.62
fx px axis 334 ± 1.45
fy px axis 334 ± 1.43
cx px axis 269 ± 0.487
cy px axis 318 ± 0.259
dist k1 axis −0.0222 ± 0.00308
dist k2 axis 0.0145 ± 0.0122
dist k3 axis −0.0151 ± 0.0145
dist k4 axis 0.00301 ± 0.00548
baseline to Looper GS cam0 mm axis 99 ± 0.508
time offset td to base IMU ms axis 0.965 ± 1.69 · line at 0
distance to base IMU ‖p‖ mm axis 63.6 ± 1.02
fx px axis 775 ± 1.37
fy px axis 775 ± 1.22
cx px axis 960 ± 0.408
cy px axis 536 ± 0.6
dist k1 axis −0.0327 ± 0.00253
dist k2 axis 0.000669 ± 0.00873
dist k3 axis −0.0022 ± 0.0127
dist k4 axis 0.000702 ± 0.00565
readout tr ms axis 32.1 ± 0.43
baseline to Looper GS cam0 mm axis 49.5 ± 0.222
time offset td to base IMU ms axis −5.68 ± 0.277
distance to base IMU ‖p‖ mm axis 22.9 ± 0.992
gyro Dw[0,0] scale x axis 0.999 ± 0.00417 · line at 1
gyro Dw[1,1] scale y axis 1 ± 0.0039 · line at 1
gyro Dw[2,2] scale z axis 0.996 ± 0.000873
gyro Dw[1,0] cross axis 0.00176 ± 0.00205
gyro Dw[2,0] cross axis 0.0000818 ± 0.00194
gyro Dw[2,1] cross axis −0.00176 ± 0.00239
accel Da[0,0] scale x axis 0.996 ± 0.00125
accel Da[1,1] scale y axis 0.996 ± 0.00137
accel Da[2,2] scale z axis 1 ± 0.00508 · line at 1
t_ga gyro−accel ms axis −5.3 ± 0.202
Whisker = lowest to highest value over the tool's solved recordings; box = median ± sd; tick = median. Min and max come from the per-recording values behind each record's median; only these two numbers are published, not the values. Rotations are not shown: the records do not hold them yet.
Model notes and how each tool was run
Section titled “Model notes and how each tool was run”6 notes on models, inputs and run settings
- Kalibr: 17 values are input, not estimated (hollow boxes). Their spread copies the input, so it is not that tool's repeatability.
- t_ga, the gyro–accel delay, is estimated by MVIS only; Kalibr and Basalt have no such term, so MVIS's td is not quite the same quantity.
- Tg, the IMU g-sensitivity, is a term of Kalibr's IMU model, here from MVIS (K-IMU) and Kalibr; the MVIS default model has no counterpart, so it is not compared.
Kalibr IMU-model terms Tg (median; sd on hover)
- Like for like: Every tool uses the same IMU noise, measured at rest on this unit. Kalibr's td and lever are solved given its inputs. RS cam2 is MVIS only.
- Note: Kalibr's camera + IMU solver is global-shutter only, so the RS cam2 is not in its runs. Every tool uses the same IMU noise, measured at rest on this unit.
- Basalt: cam0 + cam1 (no rolling-shutter model, so no cam2).
Run configs, commands and the full parameter tables are in Full tables at the end of this page.
Full tables
Section titled “Full tables”Every parameter table, tool difference and run config (Looper Insight 9)
How to read this
- Spread shows repeatability across recordings, not accuracy. A tool can repeat well and still be biased.
448.50 ± 0.48 (10): median ± sd across the 10 recordings that tool solved. With 3 or 4 recordings the sd itself is rough.(3/15): this tool has 3 of the family's 15 recordings.fixed: Kalibr doesn't estimate this value. Its camera + IMU runs take intrinsics and baselines as input, from an MVIS export or, on T6 and T11, from its own camera-only calibration; T7 ELP-L readout is held at 0. The spread here isn't repeatability.shown: the tool uses a different model here, so the value has no difference next to it.other model: Kalibr's coefficients here belong to a different lens model.not in model,not reported,no run,no data,no RS model,not in one run: the tool has no value for this row, and the words say why.no runmeans the tool never ran with this sensor;not in one runmeans it ran with each sensor, but no single run holds both ends of the baseline.not run, in the recordings line: the tool has no run for the family.- Differences: the column header gives the subtraction, using stored medians. No tool is the reference.
◆: the difference is larger than the larger of the two sds. It marks disagreement, not an error in either tool.≠n: the two medians come from different numbers of recordings.≠ model: the tools' models differ, so no difference is shown.fit: reprojection error measures fit and isn't comparable across models.‡ td: MVIS splits the IMU into gyro (td) and accel (td + t_ga); Kalibr and Basalt have one timeline. Basalt − Kalibr is the like-for-like check.- Each family folds; the first is open. Click a family's title to open or close it.
No ground truth: ◆ marks disagreement, not who is right.
median ± sd (recordings) · (3/15) partial · fixed Kalibr input · shown / other model, no Δ · ≠ model, fit: no Δ · ◆ |Δ| above the larger sd · ≠n different recording counts · ‡ see How to read this
On camera + IMU families the MVIS column uses Kalibr's IMU model, not the MVIS default. The default fills fewer rows and is in a closed fold under each family.
Key and MVIS column
Swipe a table sideways for the other tools and differences.
median ± sd (recordings) · (3/15) partial · fixed Kalibr input · shown / other model, no Δ · ≠ model, fit: no Δ · ◆ |Δ| above the larger sd · ≠n different recording counts · ‡ see How to read this
On camera + IMU families the MVIS column uses Kalibr's IMU model, not the MVIS default. The default fills fewer rows and is in a closed fold under each family.
T4 · Camera stereo
MVIS 10 of 10 · Kalibr 10 of 10 · Basalt 10 of 10
Camera · stereo01–stereo10 · Kalibr pinhole-equi
cam0 – Looper GS cam0 · 8 rows · ◆ 3
| Parameter | MVIS | Kalibr | Basalt | MVIS− Kalibr | Basalt− Kalibr | Basalt− MVIS |
|---|---|---|---|---|---|---|
| fx px | 335.60 ± 0.38 (10) | 335.00 ± 0.19 (10) | 335.33 ± 0.38 (10) | ◆ +0.60 | +0.33 | −0.27 |
| fy px | 335.60 ± 0.37 (10) | 334.97 ± 0.19 (10) | 335.31 ± 0.38 (10) | ◆ +0.63 | +0.35 | −0.28 |
| cx px | 271.99 ± 0.11 (10) | 271.93 ± 0.17 (10) | 272.01 ± 0.11 (10) | +0.06 | +0.09 | +0.03 |
| cy px | 318.49 ± 0.05 (10) | 318.48 ± 0.05 (10) | 318.46 ± 0.03 (10) | +0.02 | −0.01 | −0.03 |
| dist k1 | −0.02356 ± 0.00109 (10) | −0.02167 ± 0.00139 (10) | −0.02323 ± 0.00079 (10) | ◆ −0.00189 | ◆ −0.00156 | +0.00033 |
| dist k2 | 0.01131 ± 0.00284 (10) | 0.01157 ± 0.00481 (10) | 0.01362 ± 0.00156 (10) | −0.00026 | +0.00205 | +0.00230 |
| dist k3 | −0.01022 ± 0.00381 (10) | −0.01366 ± 0.00588 (10) | −0.01356 ± 0.00177 (10) | +0.00344 | +0.00010 | −0.00334 |
| dist k4 | 0.00123 ± 0.00170 (10) | 0.00324 ± 0.00244 (10) | 0.00236 ± 0.00064 (10) | −0.00200 | −0.00088 | +0.00113 |
cam1 – Looper GS cam1 · 9 rows · ◆ 6
| Parameter | MVIS | Kalibr | Basalt | MVIS− Kalibr | Basalt− Kalibr | Basalt− MVIS |
|---|---|---|---|---|---|---|
| fx px | 335.62 ± 0.40 (10) | 335.09 ± 0.20 (10) | 335.41 ± 0.38 (10) | ◆ +0.53 | +0.32 | −0.22 |
| fy px | 335.61 ± 0.40 (10) | 335.07 ± 0.20 (10) | 335.38 ± 0.38 (10) | ◆ +0.54 | +0.31 | −0.23 |
| cx px | 269.29 ± 0.12 (10) | 269.42 ± 0.16 (10) | 269.31 ± 0.09 (10) | −0.13 | −0.10 | +0.02 |
| cy px | 318.27 ± 0.07 (10) | 318.25 ± 0.05 (10) | 318.22 ± 0.05 (10) | +0.01 | −0.03 | −0.04 |
| dist k1 | −0.02366 ± 0.00110 (10) | −0.02123 ± 0.00095 (10) | −0.02336 ± 0.00103 (10) | ◆ −0.00243 | ◆ −0.00212 | +0.00030 |
| dist k2 | 0.01135 ± 0.00224 (10) | 0.00922 ± 0.00393 (10) | 0.01321 ± 0.00226 (10) | +0.00213 | ◆ +0.00399 | +0.00186 |
| dist k3 | −0.00975 ± 0.00259 (10) | −0.00998 ± 0.00515 (10) | −0.01417 ± 0.00288 (10) | +0.00022 | −0.00420 | ◆ −0.00442 |
| dist k4 | 0.00053 ± 0.00103 (10) | 0.00150 ± 0.00219 (10) | 0.00304 ± 0.00126 (10) | −0.00097 | +0.00154 | ◆ +0.00251 |
| baseline to Looper GS cam0 mm | 99.129 ± 0.176 (10) | 99.188 ± 0.238 (10) | 99.126 ± 0.183 (10) | −0.059 | −0.062 | −0.004 |
T11 · 3-cam + IMU
MVIS 10 of 10 · Kalibr 10 of 10, no values on Looper RS cam2 · Basalt 10 of 10, no values on Looper RS cam2
Camera + IMU · bags 1–10 · Kalibr from its own camera calibration
Read first: Kalibr's intrinsics and baselines are inputs from its own camera-only calibration; its td and lever are solved given them.
Notes
Like for like: Every tool uses the same IMU noise, measured at rest on this unit. Kalibr's td and lever are solved given its inputs. RS cam2 is MVIS only.
Note: Kalibr's camera + IMU solver is global-shutter only, so the RS cam2 is not in its runs. Every tool uses the same IMU noise, measured at rest on this unit.
Basalt: cam0 + cam1 (no rolling-shutter model, so no cam2).
cam0 – Looper GS cam0 · 11 rows · ◆ 3
| Parameter | MVISKalibr IMU model | Kalibr | Basalt | MVIS− Kalibr | Basalt− Kalibr | Basalt− MVIS |
|---|---|---|---|---|---|---|
| fx px | 333.93 ± 0.15 (10) | fixed 335.00 ± 0.19 (10) | 334.24 ± 0.44 (10) | +0.31 | ||
| fy px | 333.93 ± 0.16 (10) | fixed 334.97 ± 0.19 (10) | 334.19 ± 0.43 (10) | +0.26 | ||
| cx px | 272.18 ± 0.14 (10) | fixed 271.93 ± 0.17 (10) | 271.96 ± 0.15 (10) | ◆ −0.23 | ||
| cy px | 318.58 ± 0.07 (10) | fixed 318.48 ± 0.05 (10) | 318.51 ± 0.04 (10) | −0.07 | ||
| dist k1 | −0.02193 ± 0.00122 (10) | fixed −0.02167 ± 0.00139 (10) | −0.02156 ± 0.00120 (10) | +0.00037 | ||
| dist k2 | 0.01207 ± 0.00406 (10) | fixed 0.01157 ± 0.00481 (10) | 0.01092 ± 0.00243 (10) | −0.00115 | ||
| dist k3 | −0.01359 ± 0.00479 (10) | fixed −0.01366 ± 0.00588 (10) | −0.01093 ± 0.00284 (10) | +0.00266 | ||
| dist k4 | 0.00288 ± 0.00186 (10) | fixed 0.00324 ± 0.00244 (10) | 0.00135 ± 0.00111 (10) | −0.00153 | ||
| time offset td to base IMU‡ ms | 1.326 ± 0.087 (10) | −0.272 ± 0.131 (10) | 0.580 ± 0.156 (10) | ◆ +1.598 | ◆ +0.852 | ◆ −0.746 |
| distance to base IMU ‖p‖ mm | 43.73 ± 0.37 (10) | 44.56 ± 0.51 (10) | 45.05 ± 0.56 (10) | ◆ −0.83 | +0.49 | ◆ +1.33 |
| reproj median px | 0.153 ± 0.006 (10) | 0.195 ± 0.008 (10) | not reported | fit |
cam1 – Looper GS cam1 · 12 rows · ◆ 8
| Parameter | MVISKalibr IMU model | Kalibr | Basalt | MVIS− Kalibr | Basalt− Kalibr | Basalt− MVIS |
|---|---|---|---|---|---|---|
| fx px | 333.99 ± 0.12 (10) | fixed 335.09 ± 0.20 (10) | 334.26 ± 0.45 (10) | +0.27 | ||
| fy px | 333.91 ± 0.13 (10) | fixed 335.07 ± 0.20 (10) | 334.22 ± 0.44 (10) | +0.32 | ||
| cx px | 269.53 ± 0.12 (10) | fixed 269.42 ± 0.16 (10) | 269.25 ± 0.09 (10) | ◆ −0.29 | ||
| cy px | 318.46 ± 0.09 (10) | fixed 318.25 ± 0.05 (10) | 318.31 ± 0.06 (10) | ◆ −0.15 | ||
| dist k1 | −0.02296 ± 0.00090 (10) | fixed −0.02123 ± 0.00095 (10) | −0.02152 ± 0.00137 (10) | ◆ +0.00144 | ||
| dist k2 | 0.01788 ± 0.00329 (10) | fixed 0.00922 ± 0.00393 (10) | 0.01120 ± 0.00265 (10) | ◆ −0.00668 | ||
| dist k3 | −0.01837 ± 0.00428 (10) | fixed −0.00998 ± 0.00515 (10) | −0.01195 ± 0.00328 (10) | ◆ +0.00642 | ||
| dist k4 | 0.00396 ± 0.00176 (10) | fixed 0.00150 ± 0.00219 (10) | 0.00210 ± 0.00133 (10) | ◆ −0.00186 | ||
| baseline to Looper GS cam0 mm | 99.003 ± 0.211 (10) | fixed 99.188 ± 0.238 (10) | 98.980 ± 0.191 (10) | −0.023 | ||
| time offset td to base IMU‡ ms | 1.360 ± 0.092 (10) | −0.256 ± 0.135 (10) | 0.580 ± 0.156 (10) | ◆ +1.616 | ◆ +0.836 | ◆ −0.780 |
| distance to base IMU ‖p‖ mm | 63.96 ± 0.38 (10) | 63.33 ± 0.34 (10) | 63.21 ± 0.33 (10) | ◆ +0.63 | −0.12 | ◆ −0.74 |
| reproj median px | 0.161 ± 0.006 (10) | 0.209 ± 0.009 (10) | not reported | fit |
cam2 – Looper RS cam2 · 13 rows
Kalibr: not in its runs, which are global-shutter only.
Basalt: no rolling-shutter model.
| Parameter | MVISKalibr IMU model | Kalibr | Basalt |
|---|---|---|---|
| fx px | 775.21 ± 0.53 (10) | no run | no run |
| fy px | 775.31 ± 0.49 (10) | no run | no run |
| cx px | 960.13 ± 0.22 (10) | no run | no run |
| cy px | 535.71 ± 0.27 (10) | no run | no run |
| dist k1 | −0.03264 ± 0.00129 (10) | no run | no run |
| dist k2 | 0.00067 ± 0.00441 (10) | no run | no run |
| dist k3 | −0.00223 ± 0.00569 (10) | no run | no run |
| dist k4 | 0.00072 ± 0.00238 (10) | no run | no run |
| readout tr ms | 32.148 ± 0.231 (10) | no run | no run |
| baseline to Looper GS cam0 mm | 49.527 ± 0.116 (10) | no run | no run |
| time offset td to base IMU‡ ms | −5.673 ± 0.150 (10) | no run | no run |
| distance to base IMU ‖p‖ mm | 22.94 ± 0.43 (10) | no run | no run |
| reproj median px | 0.434 ± 0.016 (10) | no run | no run |
base IMU – Looper MEMS imu0 · 19 rows · ◆ 4
| Parameter | MVISKalibr IMU model | Kalibr | Basalt | MVIS− Kalibr | Basalt− Kalibr | Basalt− MVIS |
|---|---|---|---|---|---|---|
| gyro Dw[0,0] scale x | 1.00082 ± 0.00087 (10) | 0.99846 ± 0.00131 (10) | 0.99882 ± 0.00144 (10) | ◆ +0.00236 | +0.00036 | ◆ −0.00200 |
| gyro Dw[1,1] scale y | 1.00000 ± 0.00096 (10) | 0.99998 ± 0.00068 (10) | 0.99995 ± 0.00131 (10) | +0.00002 | −0.00003 | −0.00005 |
| gyro Dw[2,2] scale z | 0.99572 ± 0.00033 (10) | 0.99575 ± 0.00034 (10) | 0.99571 ± 0.00045 (10) | −0.00003 | −0.00004 | −0.00001 |
| gyro Dw[1,0] cross | 0.00176 ± 0.00122 (10) | 0.00175 ± 0.00103 (10) | 0.00206 ± 0.00070 (10) | +0.00001 | +0.00031 | +0.00030 |
| gyro Dw[2,0] cross | −0.00078 ± 0.00046 (10) | 0.00127 ± 0.00034 (10) | 0.00008 ± 0.00048 (10) | ◆ −0.00205 | ◆ −0.00119 | ◆ +0.00086 |
| gyro Dw[2,1] cross | −0.00166 ± 0.00062 (10) | −0.00180 ± 0.00055 (10) | −0.00176 ± 0.00111 (10) | +0.00014 | +0.00004 | −0.00010 |
| accel Da[0,0] scale x | 0.99618 ± 0.00040 (10) | 0.99574 ± 0.00029 (10) | 0.99563 ± 0.00049 (10) | ◆ +0.00043 | −0.00011 | ◆ −0.00055 |
| accel Da[1,1] scale y | 0.99681 ± 0.00028 (10) | 0.99636 ± 0.00050 (10) | 0.99625 ± 0.00049 (10) | +0.00045 | −0.00011 | ◆ −0.00055 |
| accel Da[2,2] scale z | 1.00457 ± 0.00159 (10) | 1.00541 ± 0.00195 (10) | 1.00477 ± 0.00179 (10) | −0.00084 | −0.00064 | +0.00020 |
| Tg[0,0] g-sensitivity mrad·s/m | −0.077 ± 0.075 (10) | −0.234 ± 0.108 (10) | not in model | ≠ model | ||
| Tg[0,1] g-sensitivity mrad·s/m | 0.029 ± 0.039 (10) | −0.246 ± 0.118 (10) | not in model | ≠ model | ||
| Tg[0,2] g-sensitivity mrad·s/m | −0.073 ± 0.130 (10) | 0.063 ± 0.184 (10) | not in model | ≠ model | ||
| Tg[1,0] g-sensitivity mrad·s/m | −0.131 ± 0.099 (10) | 0.804 ± 0.164 (10) | not in model | ≠ model | ||
| Tg[1,1] g-sensitivity mrad·s/m | 0.006 ± 0.078 (10) | 0.021 ± 0.055 (10) | not in model | ≠ model | ||
| Tg[1,2] g-sensitivity mrad·s/m | 0.051 ± 0.162 (10) | −2.207 ± 0.370 (10) | not in model | ≠ model | ||
| Tg[2,0] g-sensitivity mrad·s/m | 0.139 ± 0.189 (10) | 0.000 ± 0.258 (10) | not in model | ≠ model | ||
| Tg[2,1] g-sensitivity mrad·s/m | −0.048 ± 0.041 (10) | 1.381 ± 0.082 (10) | not in model | ≠ model | ||
| Tg[2,2] g-sensitivity mrad·s/m | 0.001 ± 0.068 (10) | −0.018 ± 0.190 (10) | not in model | ≠ model | ||
| t_ga gyro−accel ms | −5.297 ± 0.107 (10) | not in model | not in model |
MVIS default IMU model (calyx) · 36 of 55 rows, model-independent only · ◆ 4
| Parameter | MVISKalibr IMU model | MVIS default | Kalibr | default− Kalibr | default− Kalibr IMU model |
|---|---|---|---|---|---|
| cam0 – Looper GS cam0 | |||||
| fx px | 333.93 ± 0.15 (10) | 333.92 ± 0.16 (10) | fixed 335.00 ± 0.19 (10) | −0.01 | |
| fy px | 333.93 ± 0.16 (10) | 333.91 ± 0.16 (10) | fixed 334.97 ± 0.19 (10) | −0.01 | |
| cx px | 272.18 ± 0.14 (10) | 272.18 ± 0.13 (10) | fixed 271.93 ± 0.17 (10) | 0.00 | |
| cy px | 318.58 ± 0.07 (10) | 318.58 ± 0.07 (10) | fixed 318.48 ± 0.05 (10) | 0.00 | |
| dist k1 | −0.02193 ± 0.00122 (10) | −0.02197 ± 0.00123 (10) | fixed −0.02167 ± 0.00139 (10) | −0.00004 | |
| dist k2 | 0.01207 ± 0.00406 (10) | 0.01205 ± 0.00408 (10) | fixed 0.01157 ± 0.00481 (10) | −0.00002 | |
| dist k3 | −0.01359 ± 0.00479 (10) | −0.01349 ± 0.00483 (10) | fixed −0.01366 ± 0.00588 (10) | +0.00009 | |
| dist k4 | 0.00288 ± 0.00186 (10) | 0.00283 ± 0.00187 (10) | fixed 0.00324 ± 0.00244 (10) | −0.00005 | |
| time offset td to base IMU‡ ms | 1.326 ± 0.087 (10) | 1.315 ± 0.077 (10) | −0.272 ± 0.131 (10) | ◆ +1.587 | −0.011 |
| distance to base IMU ‖p‖ mm | 43.73 ± 0.37 (10) | 43.70 ± 0.37 (10) | 44.56 ± 0.51 (10) | ◆ −0.86 | −0.03 |
| reproj median px | 0.153 ± 0.006 (10) | 0.154 ± 0.006 (10) | 0.195 ± 0.008 (10) | fit | fit |
| cam1 – Looper GS cam1 | |||||
| fx px | 333.99 ± 0.12 (10) | 333.99 ± 0.12 (10) | fixed 335.09 ± 0.20 (10) | 0.00 | |
| fy px | 333.91 ± 0.13 (10) | 333.91 ± 0.13 (10) | fixed 335.07 ± 0.20 (10) | 0.00 | |
| cx px | 269.53 ± 0.12 (10) | 269.53 ± 0.12 (10) | fixed 269.42 ± 0.16 (10) | 0.00 | |
| cy px | 318.46 ± 0.09 (10) | 318.46 ± 0.08 (10) | fixed 318.25 ± 0.05 (10) | 0.00 | |
| dist k1 | −0.02296 ± 0.00090 (10) | −0.02297 ± 0.00089 (10) | fixed −0.02123 ± 0.00095 (10) | 0.00000 | |
| dist k2 | 0.01788 ± 0.00329 (10) | 0.01779 ± 0.00328 (10) | fixed 0.00922 ± 0.00393 (10) | −0.00009 | |
| dist k3 | −0.01837 ± 0.00428 (10) | −0.01823 ± 0.00426 (10) | fixed −0.00998 ± 0.00515 (10) | +0.00014 | |
| dist k4 | 0.00396 ± 0.00176 (10) | 0.00393 ± 0.00174 (10) | fixed 0.00150 ± 0.00219 (10) | −0.00003 | |
| baseline to Looper GS cam0 mm | 99.003 ± 0.211 (10) | 99.001 ± 0.211 (10) | fixed 99.188 ± 0.238 (10) | −0.002 | |
| time offset td to base IMU‡ ms | 1.360 ± 0.092 (10) | 1.349 ± 0.080 (10) | −0.256 ± 0.135 (10) | ◆ +1.606 | −0.010 |
| distance to base IMU ‖p‖ mm | 63.96 ± 0.38 (10) | 63.96 ± 0.37 (10) | 63.33 ± 0.34 (10) | ◆ +0.63 | 0.00 |
| reproj median px | 0.161 ± 0.006 (10) | 0.162 ± 0.006 (10) | 0.209 ± 0.009 (10) | fit | fit |
| cam2 – Looper RS cam2 | |||||
| fx px | 775.21 ± 0.53 (10) | 775.21 ± 0.51 (10) | no run | 0.00 | |
| fy px | 775.31 ± 0.49 (10) | 775.33 ± 0.48 (10) | no run | +0.02 | |
| cx px | 960.13 ± 0.22 (10) | 960.12 ± 0.22 (10) | no run | −0.01 | |
| cy px | 535.71 ± 0.27 (10) | 535.69 ± 0.27 (10) | no run | −0.02 | |
| dist k1 | −0.03264 ± 0.00129 (10) | −0.03266 ± 0.00131 (10) | no run | −0.00002 | |
| dist k2 | 0.00067 ± 0.00441 (10) | 0.00066 ± 0.00441 (10) | no run | −0.00001 | |
| dist k3 | −0.00223 ± 0.00569 (10) | −0.00217 ± 0.00568 (10) | no run | +0.00006 | |
| dist k4 | 0.00072 ± 0.00238 (10) | 0.00069 ± 0.00237 (10) | no run | −0.00003 | |
| readout tr ms | 32.148 ± 0.231 (10) | 32.136 ± 0.224 (10) | no run | −0.012 | |
| baseline to Looper GS cam0 mm | 49.527 ± 0.116 (10) | 49.527 ± 0.117 (10) | no run | 0.000 | |
| time offset td to base IMU‡ ms | −5.673 ± 0.150 (10) | −5.687 ± 0.141 (10) | no run | −0.014 | |
| distance to base IMU ‖p‖ mm | 22.94 ± 0.43 (10) | 22.90 ± 0.38 (10) | no run | −0.04 | |
| reproj median px | 0.434 ± 0.016 (10) | 0.434 ± 0.016 (10) | no run | fit | |