
UZH-FPV
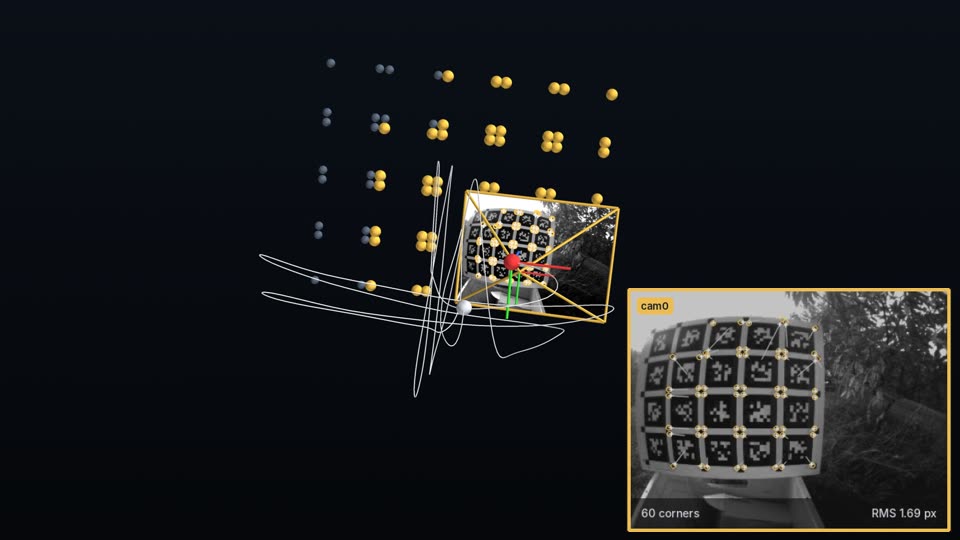
Repeatability, not accuracy. There is no ground truth: a small spread shows that a tool repeats, not that it is right, and a difference shows that two tools disagree, not which one is wrong. The MVIS authors made every run, including Kalibr and Basalt.
Repeatability
Section titled “Repeatability”This study has no repeatability cells: it was made before the current schema, and 4 bags per device are too few for the test (it needs 6).
DAVIS · camera + IMU
Section titled “DAVIS · camera + IMU”mDAVIS346 + IMU · 4 recordings
Read first: All three tools use each bag's IMU weights from the residuals in UZH's own Kalibr results. Kalibr's intrinsics and baseline are inputs from the calibration UZH ships.
Coverage
Section titled “Coverage”- MVIS 4 of 4
- Kalibr 4 of 4
- Basalt 3 of 4
MVIS made two runs per recording: its default IMU model ("MVIS") and Kalibr's IMU model ("MVIS (K-IMU)"), so the IMU terms of the second mean the same thing as Kalibr's.
Fit: reprojection median, px (fit of each tool's own model, not accuracy)
| Camera | MVIS | MVIS (K-IMU) | Kalibr | Basalt |
|---|---|---|---|---|
| mDAVIS346 | 0.343 | 0.344 | 0.137 | – |
Where the tools differ
Section titled “Where the tools differ”MVIS (K-IMU) − Kalibr ◆ 3 of 11 compared rows
- mDAVIS346 · time offset td to base IMU +0.024 ms
- mDAVIS346 · distance to base IMU ‖p‖ −2.29 mm ◆
- DAVIS IMU · gyro Dw[0,0] scale x +0.00198 ◆
- DAVIS IMU · gyro Dw[1,1] scale y +0.00159
- DAVIS IMU · gyro Dw[2,2] scale z +0.00071
- DAVIS IMU · gyro Dw[1,0] cross −0.00003
- DAVIS IMU · gyro Dw[2,0] cross +0.00046
- DAVIS IMU · gyro Dw[2,1] cross −0.00037
- DAVIS IMU · accel Da[0,0] scale x +0.00120
- DAVIS IMU · accel Da[1,1] scale y +0.00067
- DAVIS IMU · accel Da[2,2] scale z +0.00482 ◆
Basalt − Kalibr ◆ 4 of 11 compared rows
- mDAVIS346 · time offset td to base IMU +0.010 ms ≠n
- mDAVIS346 · distance to base IMU ‖p‖ +10.17 mm ◆ ≠n
- DAVIS IMU · gyro Dw[0,0] scale x −0.01284 ◆ ≠n
- DAVIS IMU · gyro Dw[1,1] scale y −0.00655 ≠n
- DAVIS IMU · gyro Dw[2,2] scale z −0.00030 ≠n
- DAVIS IMU · gyro Dw[1,0] cross −0.00100 ≠n
- DAVIS IMU · gyro Dw[2,0] cross +0.00172 ≠n
- DAVIS IMU · gyro Dw[2,1] cross −0.00179 ≠n
- DAVIS IMU · accel Da[0,0] scale x −0.00454 ≠n
- DAVIS IMU · accel Da[1,1] scale y −0.00642 ◆ ≠n
- DAVIS IMU · accel Da[2,2] scale z −0.01989 ◆ ≠n
Basalt − MVIS (K-IMU) ◆ 8 of 19 compared rows
- mDAVIS346 · fx −1.68 px ≠n
- mDAVIS346 · fy −1.56 px ≠n
- mDAVIS346 · cx −0.24 px ◆ ≠n
- mDAVIS346 · cy −0.52 px ≠n
- mDAVIS346 · dist k1 +0.00629 ≠n
- mDAVIS346 · dist k2 −0.01806 ≠n
- mDAVIS346 · dist k3 +0.04632 ◆ ≠n
- mDAVIS346 · dist k4 −0.02500 ◆ ≠n
- mDAVIS346 · time offset td to base IMU −0.014 ms ≠n
- mDAVIS346 · distance to base IMU ‖p‖ +12.46 mm ◆ ≠n
- DAVIS IMU · gyro Dw[0,0] scale x −0.01482 ◆ ≠n
- DAVIS IMU · gyro Dw[1,1] scale y −0.00814 ≠n
- DAVIS IMU · gyro Dw[2,2] scale z −0.00101 ≠n
- DAVIS IMU · gyro Dw[1,0] cross −0.00097 ≠n
- DAVIS IMU · gyro Dw[2,0] cross +0.00125 ≠n
- DAVIS IMU · gyro Dw[2,1] cross −0.00142 ≠n
- DAVIS IMU · accel Da[0,0] scale x −0.00573 ◆ ≠n
- DAVIS IMU · accel Da[1,1] scale y −0.00709 ◆ ≠n
- DAVIS IMU · accel Da[2,2] scale z −0.02471 ◆ ≠n
Dot = median difference Δ on an axis in units of the larger of the two tools' sd; shaded = ±1 sd; filled dot and ◆ = outside it; an arrow = beyond ±5 sd. No tool is the reference. "≠n" = the tools solved different recordings.
Parameters by sensor
Section titled “Parameters by sensor”2 sensors, 20 parameter charts (open to see each tool's spread)
fx px axis 173 ± 3.35
fy px axis 173 ± 3.41
cx px axis 164 ± 0.586
cy px axis 135 ± 6.36
dist k1 axis −0.0272 ± 0.0148
dist k2 axis 0.000876 ± 0.0482
dist k3 axis −0.0128 ± 0.0551
dist k4 axis 0.00651 ± 0.0285
time offset td to base IMU ms axis 5.83 ± 0.672
distance to base IMU ‖p‖ mm axis 22.5 ± 14.6
gyro Dw[0,0] scale x axis 0.997 ± 0.0187 · line at 1
gyro Dw[1,1] scale y axis 1 ± 0.033 · line at 1
gyro Dw[2,2] scale z axis 1.01 ± 0.00385
gyro Dw[1,0] cross axis −0.000614 ± 0.00394
gyro Dw[2,0] cross axis −0.00356 ± 0.0194
gyro Dw[2,1] cross axis −0.0177 ± 0.0101
accel Da[0,0] scale x axis 0.998 ± 0.0104 · line at 1
accel Da[1,1] scale y axis 1 ± 0.0122 · line at 1
accel Da[2,2] scale z axis 0.98 ± 0.0288 · line at 1
t_ga gyro−accel ms axis −0.514 ± 0.303
Whisker = lowest to highest value over the tool's solved recordings; box = median ± sd; tick = median. Min and max come from the per-recording values behind each record's median; only these two numbers are published, not the values. Rotations are not shown: the records do not hold them yet.
Model notes and how each tool was run
Section titled “Model notes and how each tool was run”5 notes on models, inputs and run settings
- Kalibr: 8 values are input, not estimated (hollow boxes). Their spread copies the input, so it is not that tool's repeatability.
- t_ga, the gyro–accel delay, is estimated by MVIS only; Kalibr and Basalt have no such term, so MVIS's td is not quite the same quantity.
- Tg, the IMU g-sensitivity, is a term of Kalibr's IMU model, here from MVIS (K-IMU) and Kalibr; the MVIS default model has no counterpart, so it is not compared.
Kalibr IMU-model terms Tg (median; sd on hover)
- Like for like: Every tool starts from the camera chain UZH ships and uses the same IMU sigmas on the same bags. Kalibr keeps the camera values fixed; MVIS and Basalt refine them.
- Note: Basalt has 3 of 4 recordings: its davis_indoor_forward solve failed (lever 120 mm, accel scale 0.84) and is left out.
Run configs, commands and the full parameter tables are in Full tables at the end of this page.
SNAP · camera + IMU
Section titled “SNAP · camera + IMU”Snapdragon stereo + IMU · 4 recordings
Read first: All three tools use each bag's IMU weights from the residuals in UZH's own Kalibr results. Kalibr's intrinsics and baseline are inputs from the calibration UZH ships.
Coverage
Section titled “Coverage”- MVIS 4 of 4
- Kalibr 4 of 4
- Basalt 4 of 4
MVIS made two runs per recording: its default IMU model ("MVIS") and Kalibr's IMU model ("MVIS (K-IMU)"), so the IMU terms of the second mean the same thing as Kalibr's.
Fit: reprojection median, px (fit of each tool's own model, not accuracy)
| Camera | MVIS | MVIS (K-IMU) | Kalibr | Basalt |
|---|---|---|---|---|
| Snapdragon left | 0.203 | 0.203 | 0.483 | – |
| Snapdragon right | 0.202 | 0.201 | 0.405 | – |
Where the tools differ
Section titled “Where the tools differ”MVIS (K-IMU) − Kalibr ◆ 1 of 13 compared rows
- Snapdragon left · time offset td to base IMU +0.253 ms
- Snapdragon left · distance to base IMU ‖p‖ +1.19 mm
- Snapdragon right · time offset td to base IMU +0.272 ms
- Snapdragon right · distance to base IMU ‖p‖ −0.80 mm
- Snapdragon IMU · gyro Dw[0,0] scale x +0.00010
- Snapdragon IMU · gyro Dw[1,1] scale y −0.00161
- Snapdragon IMU · gyro Dw[2,2] scale z −0.00019
- Snapdragon IMU · gyro Dw[1,0] cross +0.00104 ◆
- Snapdragon IMU · gyro Dw[2,0] cross −0.00098
- Snapdragon IMU · gyro Dw[2,1] cross +0.00042
- Snapdragon IMU · accel Da[0,0] scale x −0.00193
- Snapdragon IMU · accel Da[1,1] scale y +0.00021
- Snapdragon IMU · accel Da[2,2] scale z −0.00160
Basalt − Kalibr ◆ 4 of 13 compared rows
- Snapdragon left · time offset td to base IMU +0.042 ms
- Snapdragon left · distance to base IMU ‖p‖ +3.10 mm
- Snapdragon right · time offset td to base IMU +0.077 ms
- Snapdragon right · distance to base IMU ‖p‖ +0.71 mm
- Snapdragon IMU · gyro Dw[0,0] scale x −0.00044
- Snapdragon IMU · gyro Dw[1,1] scale y −0.00559
- Snapdragon IMU · gyro Dw[2,2] scale z −0.00409 ◆
- Snapdragon IMU · gyro Dw[1,0] cross +0.00052
- Snapdragon IMU · gyro Dw[2,0] cross −0.00290
- Snapdragon IMU · gyro Dw[2,1] cross +0.00026
- Snapdragon IMU · accel Da[0,0] scale x −0.01035 ◆
- Snapdragon IMU · accel Da[1,1] scale y −0.00613 ◆
- Snapdragon IMU · accel Da[2,2] scale z −0.01265 ◆
Basalt − MVIS (K-IMU) ◆ 10 of 30 compared rows
- Snapdragon left · fx −2.14 px ◆
- Snapdragon left · fy −2.15 px ◆
- Snapdragon left · cx +0.23 px
- Snapdragon left · cy −0.07 px
- Snapdragon left · dist k1 +0.00353
- Snapdragon left · dist k2 −0.00204
- Snapdragon left · dist k3 +0.00502
- Snapdragon left · dist k4 −0.00267
- Snapdragon left · time offset td to base IMU −0.211 ms
- Snapdragon left · distance to base IMU ‖p‖ +1.91 mm ◆
- Snapdragon right · fx −1.66 px ◆
- Snapdragon right · fy −1.64 px
- Snapdragon right · cx +0.36 px ◆
- Snapdragon right · cy +0.06 px
- Snapdragon right · dist k1 +0.00518
- Snapdragon right · dist k2 −0.00561
- Snapdragon right · dist k3 +0.00559
- Snapdragon right · dist k4 −0.00189
- Snapdragon right · baseline to Snapdragon left +0.119 mm
- Snapdragon right · time offset td to base IMU −0.195 ms
- Snapdragon right · distance to base IMU ‖p‖ +1.51 mm
- Snapdragon IMU · gyro Dw[0,0] scale x −0.00054
- Snapdragon IMU · gyro Dw[1,1] scale y −0.00399 ◆
- Snapdragon IMU · gyro Dw[2,2] scale z −0.00390
- Snapdragon IMU · gyro Dw[1,0] cross −0.00052
- Snapdragon IMU · gyro Dw[2,0] cross −0.00192 ◆
- Snapdragon IMU · gyro Dw[2,1] cross −0.00016
- Snapdragon IMU · accel Da[0,0] scale x −0.00842 ◆
- Snapdragon IMU · accel Da[1,1] scale y −0.00634 ◆
- Snapdragon IMU · accel Da[2,2] scale z −0.01105 ◆
Dot = median difference Δ on an axis in units of the larger of the two tools' sd; shaded = ±1 sd; filled dot and ◆ = outside it; an arrow = beyond ±5 sd. No tool is the reference. "≠n" = the tools solved different recordings.
Parameters by sensor
Section titled “Parameters by sensor”3 sensors, 31 parameter charts (open to see each tool's spread)
fx px axis 277 ± 2.78
fy px axis 277 ± 2.89
cx px axis 318 ± 3.78
cy px axis 242 ± 9.8
dist k1 axis −0.0104 ± 0.0115
dist k2 axis 0.019 ± 0.0348
dist k3 axis −0.016 ± 0.0377
dist k4 axis 0.00492 ± 0.0129
time offset td to base IMU ms axis −10.9 ± 6.12
distance to base IMU ‖p‖ mm axis 25.6 ± 8.48
fx px axis 276 ± 3.98
fy px axis 276 ± 3.59
cx px axis 315 ± 1.47
cy px axis 236 ± 16.9
dist k1 axis −0.00903 ± 0.0406
dist k2 axis 0.0116 ± 0.0432
dist k3 axis −0.00627 ± 0.0493
dist k4 axis 0.00113 ± 0.0238
baseline to Snapdragon left mm axis 79.5 ± 1.04
time offset td to base IMU ms axis −10.9 ± 6.12
distance to base IMU ‖p‖ mm axis 58.4 ± 6.64
gyro Dw[0,0] scale x axis 1 ± 0.00846 · line at 1
gyro Dw[1,1] scale y axis 0.998 ± 0.00915 · line at 1
gyro Dw[2,2] scale z axis 0.998 ± 0.00879 · line at 1
gyro Dw[1,0] cross axis 0.000182 ± 0.00308
gyro Dw[2,0] cross axis 0.00606 ± 0.00937
gyro Dw[2,1] cross axis −0.0000173 ± 0.00169
accel Da[0,0] scale x axis 0.998 ± 0.0149 · line at 1
accel Da[1,1] scale y axis 0.999 ± 0.0136 · line at 1
accel Da[2,2] scale z axis 0.989 ± 0.0197 · line at 1
t_ga gyro−accel ms axis −0.832 ± 0.227
Whisker = lowest to highest value over the tool's solved recordings; box = median ± sd; tick = median. Min and max come from the per-recording values behind each record's median; only these two numbers are published, not the values. Rotations are not shown: the records do not hold them yet.
Model notes and how each tool was run
Section titled “Model notes and how each tool was run”4 notes on models, inputs and run settings
- Kalibr: 17 values are input, not estimated (hollow boxes). Their spread copies the input, so it is not that tool's repeatability.
- t_ga, the gyro–accel delay, is estimated by MVIS only; Kalibr and Basalt have no such term, so MVIS's td is not quite the same quantity.
- Tg, the IMU g-sensitivity, is a term of Kalibr's IMU model, here from MVIS (K-IMU) and Kalibr; the MVIS default model has no counterpart, so it is not compared.
Kalibr IMU-model terms Tg (median; sd on hover)
- Like for like: Every tool starts from the camera chain UZH ships and uses the same IMU sigmas on the same bags. Kalibr keeps the camera values fixed; MVIS and Basalt refine them.
Run configs, commands and the full parameter tables are in Full tables at the end of this page.
Reading these results
Section titled “Reading these results”- IMU weights. All three tools use IMU sigmas taken from the residuals in UZH's own Kalibr results, not the MVIS defaults. The example page explains how they are derived.
- One Basalt solve is left out. On davis_indoor_forward with these weights, Basalt gives a 120 mm lever and an accel scale (accelerometer scale factor) of 0.84. So its Davis column has 3 of 4 bags. At Basalt's default noise that bag is plausible, but snapdragon_indoor_45 then fails with a broken spline.
- Basalt's Davis distance stands out. Its camera-to-IMU distance is 33.6 mm. Kalibr gives 23.2 mm and MVIS 22.8 mm on the same 3 bags. We haven't established why. At default noise Basalt's lever z is 14–25 mm.
- Each device's 4 bags form one family, because the camera and IMU are on the same device. That assumes the camera–IMU geometry stayed the same across recordings, which we can't confirm.
- Snapdragon's time offset really does differ between bags, with an sd (standard deviation) near 4.7 ms in every tool. So a small difference between tools on that row says little about each bag.
Full tables
Section titled “Full tables”Every parameter table, tool difference and run config (UZH-FPV)
How to read this
- Spread shows repeatability across recordings, not accuracy. A tool can repeat well and still be biased.
448.50 ± 0.48 (10): median ± sd across the 10 recordings that tool solved. With 3 or 4 recordings the sd itself is rough.(3/15): this tool has 3 of the family's 15 recordings.fixed: Kalibr doesn't estimate this value. Its camera + IMU runs take intrinsics and baselines as input, here from the calibration UZH ships. The spread here isn't repeatability.shown: the tool uses a different model here, so the value has no difference next to it.other model: Kalibr's coefficients here belong to a different lens model.not in model,not reported,no run,no data,no RS model,not in one run: the tool has no value for this row, and the words say why.no runmeans the tool never ran with this sensor;not in one runmeans it ran with each sensor, but no single run holds both ends of the baseline.not run, in the recordings line: the tool has no run for the family.- Differences: the column header gives the subtraction, using stored medians. No tool is the reference.
◆: the difference is larger than the larger of the two sds. It marks disagreement, not an error in either tool.≠n: the two medians come from different numbers of recordings.≠ model: the tools' models differ, so no difference is shown.fit: reprojection error measures fit and isn't comparable across models.‡ td: MVIS splits the IMU into gyro (td) and accel (td + t_ga); Kalibr and Basalt have one timeline. Basalt − Kalibr is the like-for-like check.- Each family folds; the first is open. Click a family's title to open or close it.
No ground truth: ◆ marks disagreement, not who is right.
median ± sd (recordings) · (3/15) partial · fixed Kalibr input · shown / other model, no Δ · ≠ model, fit: no Δ · ◆ |Δ| above the larger sd · ≠n different recording counts · ‡ see How to read this
On camera + IMU families the MVIS column uses Kalibr's IMU model, not the MVIS default. The default fills fewer rows and is in a closed fold under each family.
Key and MVIS column
Swipe a table sideways for the other tools and differences.
median ± sd (recordings) · (3/15) partial · fixed Kalibr input · shown / other model, no Δ · ≠ model, fit: no Δ · ◆ |Δ| above the larger sd · ≠n different recording counts · ‡ see How to read this
On camera + IMU families the MVIS column uses Kalibr's IMU model, not the MVIS default. The default fills fewer rows and is in a closed fold under each family.
DAVIS · mDAVIS346 + IMU
MVIS 4 of 4 · Kalibr 4 of 4 · Basalt 3 of 4
Camera + IMU · 4 bags: indoor and outdoor, 45° and forward · Kalibr scale-misalignment vs MVIS (kalibr model)
Read first: All three tools use each bag's IMU weights from the residuals in UZH's own Kalibr results. Kalibr's intrinsics and baseline are inputs from the calibration UZH ships.
Notes
Like for like: Every tool starts from the camera chain UZH ships and uses the same IMU sigmas on the same bags. Kalibr keeps the camera values fixed; MVIS and Basalt refine them.
Note: Basalt has 3 of 4 recordings: its davis_indoor_forward solve failed (lever 120 mm, accel scale 0.84) and is left out.
Run config · MVIS · mvis cam-imu
mvis cam-imu -c configs/cam_imu_<bag>_kalibr_model.yaml
davis_indoor_45, commit f5cdce0
input:
  format: ros1
  path: <uzh-fpv>/davis/indoor_45_calib_davis_imu.bag
  imu_topics:
  - /davis/imu
  cache_dir: detcache
board:
  board_type: apriltag
  rows: 4
  cols: 5
  tag_size: 0.075
  tag_spacing: 0.2
  tag_family: t36h11
camera_input:
  path: <uzh-fpv>/indoor_45_calib_davis/indoor_45_calib_davis/camchain-..indoor_45_calib_davis_cam.yaml
  estimate_readout: false
solve:
  estimate_t_ga: true
  sigma_g: 0.0003396953287453848
  sigma_a: 0.001055920434500799
  sigma_bg: 3.396953287453848e-05
  sigma_ba: 0.00010559204345007991
output:
  path: ./davis_indoor_45/real/kalibrmodel/cam_imu.json
estimate:
  imu:
    intrinsics: full
    model: kalibr
Runs (4, gyro and accel noise density; bias sigmas are 0.1 of these):
- davis_indoor_45 · gyro 3.40e-04 · accel 1.06e-03
- davis_indoor_forward · gyro 3.08e-04 · accel 1.82e-03
- davis_outdoor_45 · gyro 5.74e-04 · accel 1.16e-03
- davis_outdoor_forward · gyro 4.87e-04 · accel 1.22e-03
Run config · Kalibr · kalibr_calibrate_imu_camera
kalibr_calibrate_imu_camera --bag input.bag --cams camchain.yaml --imu imu.yaml \
    --imu-models scale-misalignment --target target.yaml --timeoffset-padding 0.1 --dont-show-report
imu.yaml for davis_indoor_45
rostopic: /davis/imu
update_rate: 1000.0
accelerometer_noise_density: 0.001055920434500799
accelerometer_random_walk: 0.00010559204345007991
gyroscope_noise_density: 0.0003396953287453848
gyroscope_random_walk: 3.396953287453848e-05
Runs (4, gyro and accel noise density; bias sigmas are 0.1 of these):
- davis_indoor_45 · gyro 3.40e-04 · accel 1.06e-03
- davis_indoor_forward · gyro 3.08e-04 · accel 1.82e-03
- davis_outdoor_45 · gyro 5.74e-04 · accel 1.16e-03
- davis_outdoor_forward · gyro 4.87e-04 · accel 1.22e-03
Run config · Basalt · basalt_calibrate_imu
basalt/build/release/basalt_calibrate_imu \
    --dataset-path \
    <uzh-fpv>/davis/indoor_45_calib_davis_imu.bag \
    --dataset-type \
    bag \
    --aprilgrid \
    basalt_seeds/aprilgrid_4x5_75mm.json \
    --result-path \
    ./basalt/davis_indoor_45/ \
    --no-gui \
    --max-iter \
    200 \
    --stall-iter \
    5 \
    --ftol \
    1e-06 \
    --skip-images \
    2 \
    --cam-topics \
    /davis/image_raw \
    --imu-topic \
    /davis/imu \
    --init-knots \
    poses \
    --init-gyro-gap \
    0.1 \
    --init-min-inliers \
    15 \
    --imu-margin \
    1.0 \
    --gyro-noise-std \
    0.0003396953287453848 \
    --accel-noise-std \
    0.001055920434500799 \
    --gyro-bias-std \
    3.396953287453848e-05 \
    --accel-bias-std \
    0.00010559204345007991 \
    --spline-dt-ms \
    10 \
    --g-norm \
    9.81 \
    --no-mocap \
--opt-intrinsicsdavis_indoor_45, build 77daf1c
Runs (4, gyro and accel noise density; bias sigmas are 0.1 of these):
- davis_indoor_45 · gyro 3.40e-04 · accel 1.06e-03
- davis_indoor_forward · gyro 3.08e-04 · accel 1.82e-03
- davis_outdoor_45 · gyro 5.74e-04 · accel 1.16e-03
- davis_outdoor_forward · gyro 4.87e-04 · accel 1.22e-03
cam0 – mDAVIS346 · 11 rows · ◆ 4
| Parameter | MVISKalibr IMU model | Kalibr | Basalt | MVIS− Kalibr | Basalt− Kalibr | Basalt− MVIS |
|---|---|---|---|---|---|---|
| fx px | 173.30 ± 1.78 (4) | fixed 173.03 ± 1.20 (4) | 171.62 ± 1.10 (3/4) | −1.68 ≠n | ||
| fy px | 173.15 ± 1.68 (4) | fixed 173.03 ± 1.22 (4) | 171.59 ± 1.13 (3/4) | −1.56 ≠n | ||
| cx px | 163.65 ± 0.17 (4) | fixed 163.32 ± 0.33 (4) | 163.41 ± 0.17 (3/4) | ◆ −0.24 ≠n | ||
| cy px | 135.39 ± 2.84 (4) | fixed 135.00 ± 3.07 (4) | 134.87 ± 3.52 (3/4) | −0.52 ≠n | ||
| dist k1 | −0.02739 ± 0.00892 (4) | fixed −0.03125 ± 0.00344 (4) | −0.02110 ± 0.00480 (3/4) | +0.00629 ≠n | ||
| dist k2 | 0.00107 ± 0.02757 (4) | fixed 0.00082 ± 0.00394 (4) | −0.01699 ± 0.00945 (3/4) | −0.01806 ≠n | ||
| dist k3 | −0.02174 ± 0.03113 (4) | fixed −0.00386 ± 0.00263 (4) | 0.02458 ± 0.01275 (3/4) | ◆ +0.04632 ≠n | ||
| dist k4 | 0.01230 ± 0.01119 (4) | fixed 0.00071 ± 0.00082 (4) | −0.01269 ± 0.00674 (3/4) | ◆ −0.02500 ≠n | ||
| time offset td to base IMU‡ ms | 5.836 ± 0.369 (4) | 5.813 ± 0.192 (4) | 5.823 ± 0.076 (3/4) | +0.024 | +0.010 ≠n | −0.014 ≠n |
| distance to base IMU ‖p‖ mm | 21.11 ± 2.13 (4) | 23.40 ± 1.66 (4) | 33.57 ± 2.13 (3/4) | ◆ −2.29 | ◆ +10.17 ≠n | ◆ +12.46 ≠n |
| reproj median px | 0.344 ± 0.044 (4) | 0.137 ± 0.026 (4) | not reported | fit |
base IMU – DAVIS IMU · 19 rows · ◆ 4
| Parameter | MVISKalibr IMU model | Kalibr | Basalt | MVIS− Kalibr | Basalt− Kalibr | Basalt− MVIS |
|---|---|---|---|---|---|---|
| gyro Dw[0,0] scale x | 0.99921 ± 0.00124 (4) | 0.99723 ± 0.00158 (4) | 0.98439 ± 0.00415 (3/4) | ◆ +0.00198 | ◆ −0.01284 ≠n | ◆ −0.01482 ≠n |
| gyro Dw[1,1] scale y | 1.00373 ± 0.00703 (4) | 1.00214 ± 0.00812 (4) | 0.99559 ± 0.01401 (3/4) | +0.00159 | −0.00655 ≠n | −0.00814 ≠n |
| gyro Dw[2,2] scale z | 1.00683 ± 0.00117 (4) | 1.00612 ± 0.00184 (4) | 1.00582 ± 0.00071 (3/4) | +0.00071 | −0.00030 ≠n | −0.00101 ≠n |
| gyro Dw[1,0] cross | −0.00061 ± 0.00138 (4) | −0.00059 ± 0.00195 (4) | −0.00158 ± 0.00070 (3/4) | −0.00003 | −0.00100 ≠n | −0.00097 ≠n |
| gyro Dw[2,0] cross | −0.00356 ± 0.00925 (4) | −0.00403 ± 0.00781 (4) | −0.00231 ± 0.00987 (3/4) | +0.00046 | +0.00172 ≠n | +0.00125 ≠n |
| gyro Dw[2,1] cross | −0.01766 ± 0.00448 (4) | −0.01729 ± 0.00457 (4) | −0.01908 ± 0.00419 (3/4) | −0.00037 | −0.00179 ≠n | −0.00142 ≠n |
| accel Da[0,0] scale x | 0.99955 ± 0.00268 (4) | 0.99835 ± 0.00330 (4) | 0.99381 ± 0.00492 (3/4) | +0.00120 | −0.00454 ≠n | ◆ −0.00573 ≠n |
| accel Da[1,1] scale y | 1.00067 ± 0.00257 (4) | 1.00000 ± 0.00176 (4) | 0.99358 ± 0.00362 (3/4) | +0.00067 | ◆ −0.00642 ≠n | ◆ −0.00709 ≠n |
| accel Da[2,2] scale z | 0.98507 ± 0.00318 (4) | 0.98025 ± 0.00111 (4) | 0.96037 ± 0.00453 (3/4) | ◆ +0.00482 | ◆ −0.01989 ≠n | ◆ −0.02471 ≠n |
| Tg[0,0] g-sensitivity mrad·s/m | −0.061 ± 0.097 (4) | −0.054 ± 0.054 (4) | not in model | ≠ model | ||
| Tg[0,1] g-sensitivity mrad·s/m | 0.013 ± 0.262 (4) | −0.248 ± 0.191 (4) | not in model | ≠ model | ||
| Tg[0,2] g-sensitivity mrad·s/m | 0.081 ± 0.121 (4) | 0.146 ± 0.175 (4) | not in model | ≠ model | ||
| Tg[1,0] g-sensitivity mrad·s/m | 0.035 ± 0.078 (4) | 0.206 ± 0.134 (4) | not in model | ≠ model | ||
| Tg[1,1] g-sensitivity mrad·s/m | −0.052 ± 0.108 (4) | 0.072 ± 0.050 (4) | not in model | ≠ model | ||
| Tg[1,2] g-sensitivity mrad·s/m | 0.173 ± 0.173 (4) | 0.158 ± 0.174 (4) | not in model | ≠ model | ||
| Tg[2,0] g-sensitivity mrad·s/m | 0.067 ± 0.126 (4) | −0.098 ± 0.075 (4) | not in model | ≠ model | ||
| Tg[2,1] g-sensitivity mrad·s/m | −0.074 ± 0.167 (4) | 0.013 ± 0.099 (4) | not in model | ≠ model | ||
| Tg[2,2] g-sensitivity mrad·s/m | −0.131 ± 0.214 (4) | 0.045 ± 0.012 (4) | not in model | ≠ model | ||
| t_ga gyro−accel ms | −0.514 ± 0.217 (4) | not in model | not in model |
MVIS default IMU model (calyx) · 11 of 30 rows, model-independent only
| Parameter | MVISKalibr IMU model | MVIS default | Kalibr | default− Kalibr | default− Kalibr IMU model |
|---|---|---|---|---|---|
| cam0 – mDAVIS346 | |||||
| fx px | 173.30 ± 1.78 (4) | 173.16 ± 1.76 (4) | fixed 173.03 ± 1.20 (4) | −0.14 | |
| fy px | 173.15 ± 1.68 (4) | 173.01 ± 1.67 (4) | fixed 173.03 ± 1.22 (4) | −0.14 | |
| cx px | 163.65 ± 0.17 (4) | 163.66 ± 0.19 (4) | fixed 163.32 ± 0.33 (4) | +0.02 | |
| cy px | 135.39 ± 2.84 (4) | 135.38 ± 2.83 (4) | fixed 135.00 ± 3.07 (4) | −0.01 | |
| dist k1 | −0.02739 ± 0.00892 (4) | −0.02695 ± 0.00896 (4) | fixed −0.03125 ± 0.00344 (4) | +0.00044 | |
| dist k2 | 0.00107 ± 0.02757 (4) | 0.00093 ± 0.02778 (4) | fixed 0.00082 ± 0.00394 (4) | −0.00014 | |
| dist k3 | −0.02174 ± 0.03113 (4) | −0.02199 ± 0.03132 (4) | fixed −0.00386 ± 0.00263 (4) | −0.00025 | |
| dist k4 | 0.01230 ± 0.01119 (4) | 0.01262 ± 0.01123 (4) | fixed 0.00071 ± 0.00082 (4) | +0.00032 | |
| time offset td to base IMU‡ ms | 5.836 ± 0.369 (4) | 5.872 ± 0.376 (4) | 5.813 ± 0.192 (4) | +0.059 | +0.035 |
| distance to base IMU ‖p‖ mm | 21.11 ± 2.13 (4) | 21.52 ± 1.95 (4) | 23.40 ± 1.66 (4) | −1.88 | +0.41 |
| reproj median px | 0.344 ± 0.044 (4) | 0.343 ± 0.043 (4) | 0.137 ± 0.026 (4) | fit | fit |
SNAP · Snapdragon stereo + IMU
MVIS 4 of 4 · Kalibr 4 of 4 · Basalt 4 of 4
Camera + IMU · 4 bags: indoor and outdoor, 45° and forward · Kalibr scale-misalignment vs MVIS (kalibr model)
Read first: All three tools use each bag's IMU weights from the residuals in UZH's own Kalibr results. Kalibr's intrinsics and baseline are inputs from the calibration UZH ships.
Notes
Like for like: Every tool starts from the camera chain UZH ships and uses the same IMU sigmas on the same bags. Kalibr keeps the camera values fixed; MVIS and Basalt refine them.
Run config · MVIS · mvis cam-imu
mvis cam-imu -c configs/cam_imu_<bag>_kalibr_model.yaml
snapdragon_indoor_45, commit f5cdce0
input:
  format: ros1
  path: <uzh-fpv>/snapdragon/indoor_45_calib_snapdragon_imu.bag
  imu_topics:
  - /snappy_imu
  cache_dir: detcache
board:
  board_type: apriltag
  rows: 4
  cols: 5
  tag_size: 0.075
  tag_spacing: 0.2
  tag_family: t36h11
camera_input:
  path: <uzh-fpv>/indoor_45_calib_snapdragon/indoor_45_calib_snapdragon/camchain-..indoor_45_calib_snapdragon_cam.yaml
  estimate_readout: false
solve:
  estimate_t_ga: true
  sigma_g: 0.0007110208680826167
  sigma_a: 0.0032732613574351305
  sigma_bg: 7.110208680826167e-05
  sigma_ba: 0.00032732613574351307
output:
  path: ./snapdragon_indoor_45/real/kalibrmodel/cam_imu.json
estimate:
  imu:
    intrinsics: full
    model: kalibr
Runs (4, gyro and accel noise density; bias sigmas are 0.1 of these):
- snapdragon_indoor_45 · gyro 7.11e-04 · accel 3.27e-03
- snapdragon_indoor_forward · gyro 8.49e-04 · accel 5.15e-03
- snapdragon_outdoor_45 · gyro 6.61e-04 · accel 3.62e-03
- snapdragon_outdoor_forward · gyro 3.00e-04 · accel 2.53e-03
Run config · Kalibr · kalibr_calibrate_imu_camera
kalibr_calibrate_imu_camera --bag input.bag --cams camchain.yaml --imu imu.yaml \
    --imu-models scale-misalignment --target target.yaml --timeoffset-padding 0.1 --dont-show-report
imu.yaml for snapdragon_indoor_45
rostopic: /snappy_imu
update_rate: 500.0
accelerometer_noise_density: 0.0032732613574351305
accelerometer_random_walk: 0.00032732613574351307
gyroscope_noise_density: 0.0007110208680826167
gyroscope_random_walk: 7.110208680826167e-05
Runs (4, gyro and accel noise density; bias sigmas are 0.1 of these):
- snapdragon_indoor_45 · gyro 7.11e-04 · accel 3.27e-03
- snapdragon_indoor_forward · gyro 8.49e-04 · accel 5.15e-03
- snapdragon_outdoor_45 · gyro 6.61e-04 · accel 3.62e-03
- snapdragon_outdoor_forward · gyro 3.00e-04 · accel 2.53e-03
Run config · Basalt · basalt_calibrate_imu
basalt/build/release/basalt_calibrate_imu \
    --dataset-path \
    <uzh-fpv>/snapdragon/indoor_45_calib_snapdragon_imu.bag \
    --dataset-type \
    bag \
    --aprilgrid \
    basalt_seeds/aprilgrid_4x5_75mm.json \
    --result-path \
    ./basalt/snapdragon_indoor_45/ \
    --no-gui \
    --max-iter \
    200 \
    --stall-iter \
    5 \
    --ftol \
    1e-06 \
    --skip-images \
    2 \
    --cam-topics \
    /snappy_cam/stereo_l \
    /snappy_cam/stereo_r \
    --imu-topic \
    /snappy_imu \
    --init-knots \
    poses \
    --init-gyro-gap \
    0.1 \
    --init-min-inliers \
    15 \
    --imu-margin \
    1.0 \
    --gyro-noise-std \
    0.0007110208680826167 \
    --accel-noise-std \
    0.0032732613574351305 \
    --gyro-bias-std \
    7.110208680826167e-05 \
    --accel-bias-std \
    0.00032732613574351307 \
    --spline-dt-ms \
    10 \
    --g-norm \
    9.81 \
    --no-mocap \
--opt-intrinsicssnapdragon_indoor_45, build 77daf1c
Runs (4, gyro and accel noise density; bias sigmas are 0.1 of these):
- snapdragon_indoor_45 · gyro 7.11e-04 · accel 3.27e-03
- snapdragon_indoor_forward · gyro 8.49e-04 · accel 5.15e-03
- snapdragon_outdoor_45 · gyro 6.61e-04 · accel 3.62e-03
- snapdragon_outdoor_forward · gyro 3.00e-04 · accel 2.53e-03
cam0 – Snapdragon left · 11 rows · ◆ 3
| Parameter | MVISKalibr IMU model | Kalibr | Basalt | MVIS− Kalibr | Basalt− Kalibr | Basalt− MVIS |
|---|---|---|---|---|---|---|
| fx px | 277.79 ± 1.13 (4) | fixed 276.47 ± 1.62 (4) | 275.65 ± 1.05 (4) | ◆ −2.14 | ||
| fy px | 277.74 ± 1.36 (4) | fixed 276.25 ± 1.74 (4) | 275.58 ± 1.23 (4) | ◆ −2.15 | ||
| cx px | 317.90 ± 2.65 (4) | fixed 317.86 ± 2.35 (4) | 318.14 ± 2.74 (4) | +0.23 | ||
| cy px | 241.59 ± 4.55 (4) | fixed 242.03 ± 4.28 (4) | 241.52 ± 4.52 (4) | −0.07 | ||
| dist k1 | −0.01116 ± 0.00372 (4) | fixed −0.00972 ± 0.00798 (4) | −0.00763 ± 0.00416 (4) | +0.00353 | ||
| dist k2 | 0.02005 ± 0.00786 (4) | fixed 0.01273 ± 0.02538 (4) | 0.01801 ± 0.00673 (4) | −0.00204 | ||
| dist k3 | −0.01854 ± 0.00973 (4) | fixed −0.00579 ± 0.02407 (4) | −0.01352 ± 0.00592 (4) | +0.00502 | ||
| dist k4 | 0.00625 ± 0.00383 (4) | fixed 0.00047 ± 0.00731 (4) | 0.00358 ± 0.00205 (4) | −0.00267 | ||
| time offset td to base IMU‡ ms | −10.764 ± 4.687 (4) | −11.017 ± 4.624 (4) | −10.975 ± 4.661 (4) | +0.253 | +0.042 | −0.211 |
| distance to base IMU ‖p‖ mm | 25.61 ± 1.67 (4) | 24.41 ± 4.71 (4) | 27.51 ± 1.67 (4) | +1.19 | +3.10 | ◆ +1.91 |
| reproj median px | 0.203 ± 0.022 (4) | 0.483 ± 0.362 (4) | not reported | fit |
cam1 – Snapdragon right · 12 rows · ◆ 2
| Parameter | MVISKalibr IMU model | Kalibr | Basalt | MVIS− Kalibr | Basalt− Kalibr | Basalt− MVIS |
|---|---|---|---|---|---|---|
| fx px | 276.74 ± 1.55 (4) | fixed 275.62 ± 2.01 (4) | 275.07 ± 1.65 (4) | ◆ −1.66 | ||
| fy px | 276.56 ± 1.61 (4) | fixed 275.36 ± 2.10 (4) | 274.91 ± 1.65 (4) | −1.64 | ||
| cx px | 314.45 ± 0.23 (4) | fixed 314.75 ± 0.72 (4) | 314.81 ± 0.21 (4) | ◆ +0.36 | ||
| cy px | 235.65 ± 7.26 (4) | fixed 236.28 ± 7.47 (4) | 235.71 ± 7.09 (4) | +0.06 | ||
| dist k1 | −0.00933 ± 0.01584 (4) | fixed −0.00874 ± 0.01894 (4) | −0.00415 ± 0.01466 (4) | +0.00518 | ||
| dist k2 | 0.01249 ± 0.02393 (4) | fixed 0.01069 ± 0.02189 (4) | 0.00688 ± 0.01525 (4) | −0.00561 | ||
| dist k3 | −0.00760 ± 0.02973 (4) | fixed −0.00495 ± 0.02314 (4) | −0.00200 ± 0.01965 (4) | +0.00559 | ||
| dist k4 | 0.00167 ± 0.01338 (4) | fixed 0.00059 ± 0.00981 (4) | −0.00022 ± 0.00992 (4) | −0.00189 | ||
| baseline to Snapdragon left mm | 79.436 ± 0.486 (4) | fixed 79.501 ± 0.319 (4) | 79.555 ± 0.762 (4) | +0.119 | ||
| time offset td to base IMU‡ ms | −10.780 ± 4.699 (4) | −11.052 ± 4.638 (4) | −10.975 ± 4.661 (4) | +0.272 | +0.077 | −0.195 |
| distance to base IMU ‖p‖ mm | 57.96 ± 1.57 (4) | 58.76 ± 2.97 (4) | 59.47 ± 2.38 (4) | −0.80 | +0.71 | +1.51 |
| reproj median px | 0.201 ± 0.043 (4) | 0.405 ± 0.497 (4) | not reported | fit |
base IMU – Snapdragon IMU · 19 rows · ◆ 7
| Parameter | MVISKalibr IMU model | Kalibr | Basalt | MVIS− Kalibr | Basalt− Kalibr | Basalt− MVIS |
|---|---|---|---|---|---|---|
| gyro Dw[0,0] scale x | 1.00405 ± 0.00194 (4) | 1.00395 ± 0.00431 (4) | 1.00351 ± 0.00102 (4) | +0.00010 | −0.00044 | −0.00054 |
| gyro Dw[1,1] scale y | 0.99791 ± 0.00213 (4) | 0.99951 ± 0.00671 (4) | 0.99392 ± 0.00339 (4) | −0.00161 | −0.00559 | ◆ −0.00399 |
| gyro Dw[2,2] scale z | 0.99792 ± 0.00185 (4) | 0.99811 ± 0.00398 (4) | 0.99402 ± 0.00409 (4) | −0.00019 | ◆ −0.00409 | −0.00390 |
| gyro Dw[1,0] cross | 0.00070 ± 0.00030 (4) | −0.00034 ± 0.00046 (4) | 0.00018 ± 0.00151 (4) | ◆ +0.00104 | +0.00052 | −0.00052 |
| gyro Dw[2,0] cross | 0.00606 ± 0.00085 (4) | 0.00704 ± 0.00538 (4) | 0.00413 ± 0.00131 (4) | −0.00098 | −0.00290 | ◆ −0.00192 |
| gyro Dw[2,1] cross | 0.00014 ± 0.00075 (4) | −0.00028 ± 0.00103 (4) | −0.00002 ± 0.00127 (4) | +0.00042 | +0.00026 | −0.00016 |
| accel Da[0,0] scale x | 0.99841 ± 0.00172 (4) | 1.00034 ± 0.00383 (4) | 0.98999 ± 0.00517 (4) | −0.00193 | ◆ −0.01035 | ◆ −0.00842 |
| accel Da[1,1] scale y | 0.99930 ± 0.00134 (4) | 0.99910 ± 0.00291 (4) | 0.99296 ± 0.00411 (4) | +0.00021 | ◆ −0.00613 | ◆ −0.00634 |
| accel Da[2,2] scale z | 0.98925 ± 0.00221 (4) | 0.99085 ± 0.00575 (4) | 0.97820 ± 0.00363 (4) | −0.00160 | ◆ −0.01265 | ◆ −0.01105 |
| Tg[0,0] g-sensitivity mrad·s/m | 0.008 ± 0.082 (4) | 0.045 ± 0.201 (4) | not in model | ≠ model | ||
| Tg[0,1] g-sensitivity mrad·s/m | −0.089 ± 0.066 (4) | 0.267 ± 0.073 (4) | not in model | ≠ model | ||
| Tg[0,2] g-sensitivity mrad·s/m | 0.046 ± 0.146 (4) | 0.165 ± 0.104 (4) | not in model | ≠ model | ||
| Tg[1,0] g-sensitivity mrad·s/m | 0.163 ± 0.138 (4) | 0.034 ± 0.234 (4) | not in model | ≠ model | ||
| Tg[1,1] g-sensitivity mrad·s/m | 0.044 ± 0.107 (4) | 0.038 ± 0.183 (4) | not in model | ≠ model | ||
| Tg[1,2] g-sensitivity mrad·s/m | −0.074 ± 0.401 (4) | −0.341 ± 0.443 (4) | not in model | ≠ model | ||
| Tg[2,0] g-sensitivity mrad·s/m | 0.029 ± 0.128 (4) | −0.053 ± 0.125 (4) | not in model | ≠ model | ||
| Tg[2,1] g-sensitivity mrad·s/m | 0.022 ± 0.094 (4) | 0.022 ± 0.219 (4) | not in model | ≠ model | ||
| Tg[2,2] g-sensitivity mrad·s/m | 0.057 ± 0.207 (4) | −0.159 ± 0.229 (4) | not in model | ≠ model | ||
| t_ga gyro−accel ms | −0.832 ± 0.124 (4) | not in model | not in model |
MVIS default IMU model (calyx) · 23 of 42 rows, model-independent only
| Parameter | MVISKalibr IMU model | MVIS default | Kalibr | default− Kalibr | default− Kalibr IMU model |
|---|---|---|---|---|---|
| cam0 – Snapdragon left | |||||
| fx px | 277.79 ± 1.13 (4) | 277.77 ± 1.11 (4) | fixed 276.47 ± 1.62 (4) | −0.01 | |
| fy px | 277.74 ± 1.36 (4) | 277.72 ± 1.33 (4) | fixed 276.25 ± 1.74 (4) | −0.02 | |
| cx px | 317.90 ± 2.65 (4) | 317.89 ± 2.64 (4) | fixed 317.86 ± 2.35 (4) | −0.01 | |
| cy px | 241.59 ± 4.55 (4) | 241.59 ± 4.56 (4) | fixed 242.03 ± 4.28 (4) | 0.00 | |
| dist k1 | −0.01116 ± 0.00372 (4) | −0.01117 ± 0.00369 (4) | fixed −0.00972 ± 0.00798 (4) | −0.00001 | |
| dist k2 | 0.02005 ± 0.00786 (4) | 0.02002 ± 0.00785 (4) | fixed 0.01273 ± 0.02538 (4) | −0.00003 | |
| dist k3 | −0.01854 ± 0.00973 (4) | −0.01849 ± 0.00969 (4) | fixed −0.00579 ± 0.02407 (4) | +0.00005 | |
| dist k4 | 0.00625 ± 0.00383 (4) | 0.00625 ± 0.00381 (4) | fixed 0.00047 ± 0.00731 (4) | −0.00001 | |
| time offset td to base IMU‡ ms | −10.764 ± 4.687 (4) | −10.794 ± 4.704 (4) | −11.017 ± 4.624 (4) | +0.223 | −0.030 |
| distance to base IMU ‖p‖ mm | 25.61 ± 1.67 (4) | 25.62 ± 1.70 (4) | 24.41 ± 4.71 (4) | +1.20 | +0.01 |
| reproj median px | 0.203 ± 0.022 (4) | 0.203 ± 0.022 (4) | 0.483 ± 0.362 (4) | fit | fit |
| cam1 – Snapdragon right | |||||
| fx px | 276.74 ± 1.55 (4) | 276.73 ± 1.52 (4) | fixed 275.62 ± 2.01 (4) | −0.01 | |
| fy px | 276.56 ± 1.61 (4) | 276.54 ± 1.59 (4) | fixed 275.36 ± 2.10 (4) | −0.02 | |
| cx px | 314.45 ± 0.23 (4) | 314.44 ± 0.25 (4) | fixed 314.75 ± 0.72 (4) | 0.00 | |
| cy px | 235.65 ± 7.26 (4) | 235.65 ± 7.25 (4) | fixed 236.28 ± 7.47 (4) | 0.00 | |
| dist k1 | −0.00933 ± 0.01584 (4) | −0.00931 ± 0.01585 (4) | fixed −0.00874 ± 0.01894 (4) | +0.00002 | |
| dist k2 | 0.01249 ± 0.02393 (4) | 0.01253 ± 0.02397 (4) | fixed 0.01069 ± 0.02189 (4) | +0.00004 | |
| dist k3 | −0.00760 ± 0.02973 (4) | −0.00761 ± 0.02978 (4) | fixed −0.00495 ± 0.02314 (4) | −0.00002 | |
| dist k4 | 0.00167 ± 0.01338 (4) | 0.00167 ± 0.01340 (4) | fixed 0.00059 ± 0.00981 (4) | 0.00000 | |
| baseline to Snapdragon left mm | 79.436 ± 0.486 (4) | 79.435 ± 0.484 (4) | fixed 79.501 ± 0.319 (4) | −0.002 | |
| time offset td to base IMU‡ ms | −10.780 ± 4.699 (4) | −10.810 ± 4.716 (4) | −11.052 ± 4.638 (4) | +0.242 | −0.030 |
| distance to base IMU ‖p‖ mm | 57.96 ± 1.57 (4) | 58.00 ± 1.55 (4) | 58.76 ± 2.97 (4) | −0.77 | +0.03 |
| reproj median px | 0.201 ± 0.043 (4) | 0.202 ± 0.044 (4) | 0.405 ± 0.497 (4) | fit | fit |